


[ad_1]
|
Hearken to this text  |
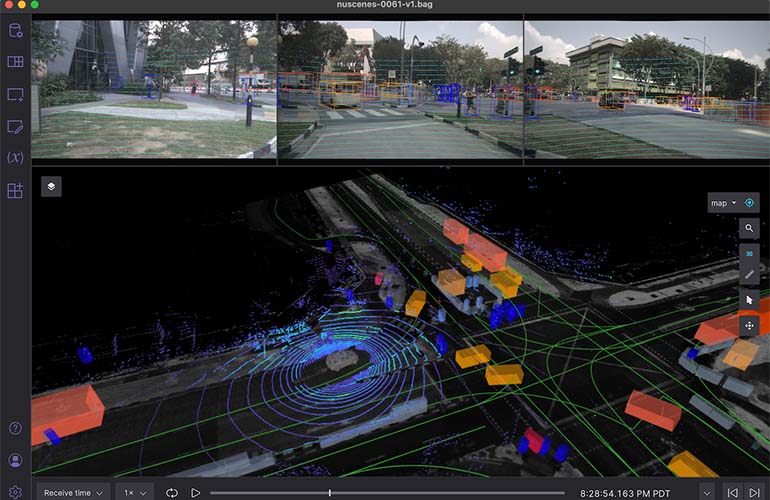
After we take into consideration robotics improvement, we frequently think about a logical and codified course of. Whereas we don’t assume it to be straightforward or simple, we do assume it to be comparatively goal – the tip objective is apparent, the milestones to succeed in it measurable.
However we neglect that when growing new applied sciences, we’d like equally novel methods to check and troubleshoot these applied sciences. It’s not simply in regards to the new robotic – it’s additionally in regards to the solely new instruments and processes that should be invented with a purpose to construct that robotic. And as with every uncharted territory, these instruments and processes are nonetheless works in progress, evolving alongside the product and the individuals constructing it.
Knowledge visualization is an particularly pivotal one among these instruments. It represents complicated and nuanced information in a digestible format, empowering us to make equally complicated and nuanced selections about how our robotic is doing and the way it might enhance. It suppresses the unimportant noise and amplifies the essential alerts. It brings some much-needed sense and order to the impossibly multidimensional nature of robotics information. As actual of a science we would like robotics to be, it’s nonetheless a largely subjective train, with numerous human judgments that get us one step nearer to our final objective – a world the place our each day lives are enhanced and enriched by robotics know-how.
Conventional software program improvement vs. robotics improvement
To actually perceive the significance of information visualization in robotics, we first want to know how robotics improvement differs from conventional software program improvement.
Diagnosing the foundation explanation for points in conventional software program improvement is a comparatively binary course of – the code both does or doesn’t do what it’s imagined to at a given step. There’s a transparent expectation of what ought to occur in each doable situation. By stepping by the bug’s code path and working assessments every step of the way in which – like logging values, checking anticipated vs precise outputs, toggling sure functionalities on and off – engineers can deduce in fairly exact phrases the road of code that the problem originates from.
Debugging points in robotics improvement, however, is never so linear. Determining what went flawed with a robotics system is often a way more difficult, and thus open-ended, course of. When an autonomous cell robotic (AMR) collides with one other object, for instance, there isn’t a one apparent “code path” or perpetrator responsible. There are numerous causes this might’ve occurred, in the identical approach there are a myriad of causes {that a} human might have collided into an impediment. Possibly the AMR didn’t see the impediment as a result of it was obstructed round a nook; possibly it miscalculated its personal trajectory for avoiding the collision. The explanations aren’t even constrained to the software program – the AMR’s brakes might’ve malfunctioned; its digital camera views might have been momentarily obscured by warehouse particles.
There isn’t a one methodical protocol to comply with, and the foundation of a problem may be brought on by an interconnected collection of smaller points that permeate a number of ranges of the robotics stack. Options are sometimes conditional and situational, so the debugging course of has to weigh contextual data as a lot because the literal code on the display.
Knowledge visualization for robotics
To handle this debugging complexity, we’d like a brand new technology of subtle tooling to discover the various dimensions of our robotics information. That is the place robotics information visualization is available in.
Within the early days of the self-driving automotive firm Cruise, we skilled firsthand simply how painful it was to develop robots with out enough tooling. When debugging our self-driving information or simulation outcomes, our engineers must set up a full improvement surroundings on an Ubuntu machine, after which obtain a smattering of assorted open-source instruments like rviz, rqt and extra. Our engineers then needed to manually provoke a log file playback, and rearrange a number of home windows on their display to make use of them directly. Engineers might painstakingly compose a format of home windows on their display for a specific workflow, however swapping it out for a unique workflow or replicating it on a teammate’s pc was a drain on valuable developer time.
Whereas these instruments did their particular person jobs, it was clear that utilizing a mix of them collectively, or utilizing them with a bigger robotics staff, had not been deliberate into their DNA. They have been clunky to make use of on their very own, tough to combine with one another, and unattainable to make use of with our teammates in significant methods. In brief, our potential to iterate on our robots was severely bottlenecked – not by the expertise of our staff, however by our lack of ability to shortly extract actionable insights from our information.
This led to a hackathon challenge the place a bunch of engineers noticed the chance to make this workflow higher. They offered a web-based information visualization device – one which was acquired so nicely that it bought a standing ovation and was finally developed into an inner device with its personal devoted staff. That device was Webviz – it was ultimately open sourced to assist different roboticists reap the advantages of extra effectively built-in tooling. As time went on, my co-founder and I spotted how impactful Webviz had been at Cruise, and determined to start out Foxglove to proceed fixing frequent robotics tooling issues for the business at giant. We launched Foxglove Studio to assist customers visualize and debug their robotics information, and Foxglove Knowledge Platform to assist them retailer and handle it in a central repository.
With information visualization, we will make sense of our information shortly – from totally different angles, utilizing totally different representations, for various workflows – to tell the following step of improvement. It’s how we’re capable of discover non-binary conditions and make the human judgments essential to carry robotics into the longer term.
Wealthy interactive information visualizations are essential in serving to roboticists have interaction within the extra open-ended exploration that robotics improvement requires. It empowers roboticists to make use of their instinct and expertise to start debugging a given situation. It helps them synthesize the equally essential subjective and goal judgments wanted to troubleshoot their work. It helps them perceive at a look how their robots are at present performing and the way they are often improved, to allow them to iterate extra successfully on them.
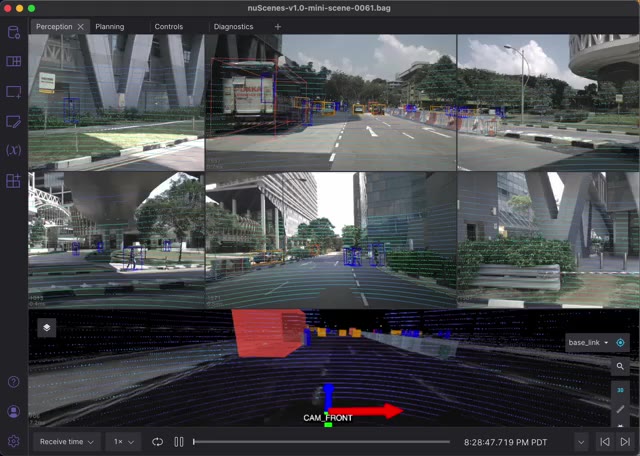
Completely different information visualization instruments may also help you make totally different judgments whereas fixing totally different issues. Every step of a debugging or evaluation workflow can profit from a mix of numerous instruments. In Foxglove Studio, for instance, customers can choose from an intensive assortment of visualization panels to construct customized debugging layouts.
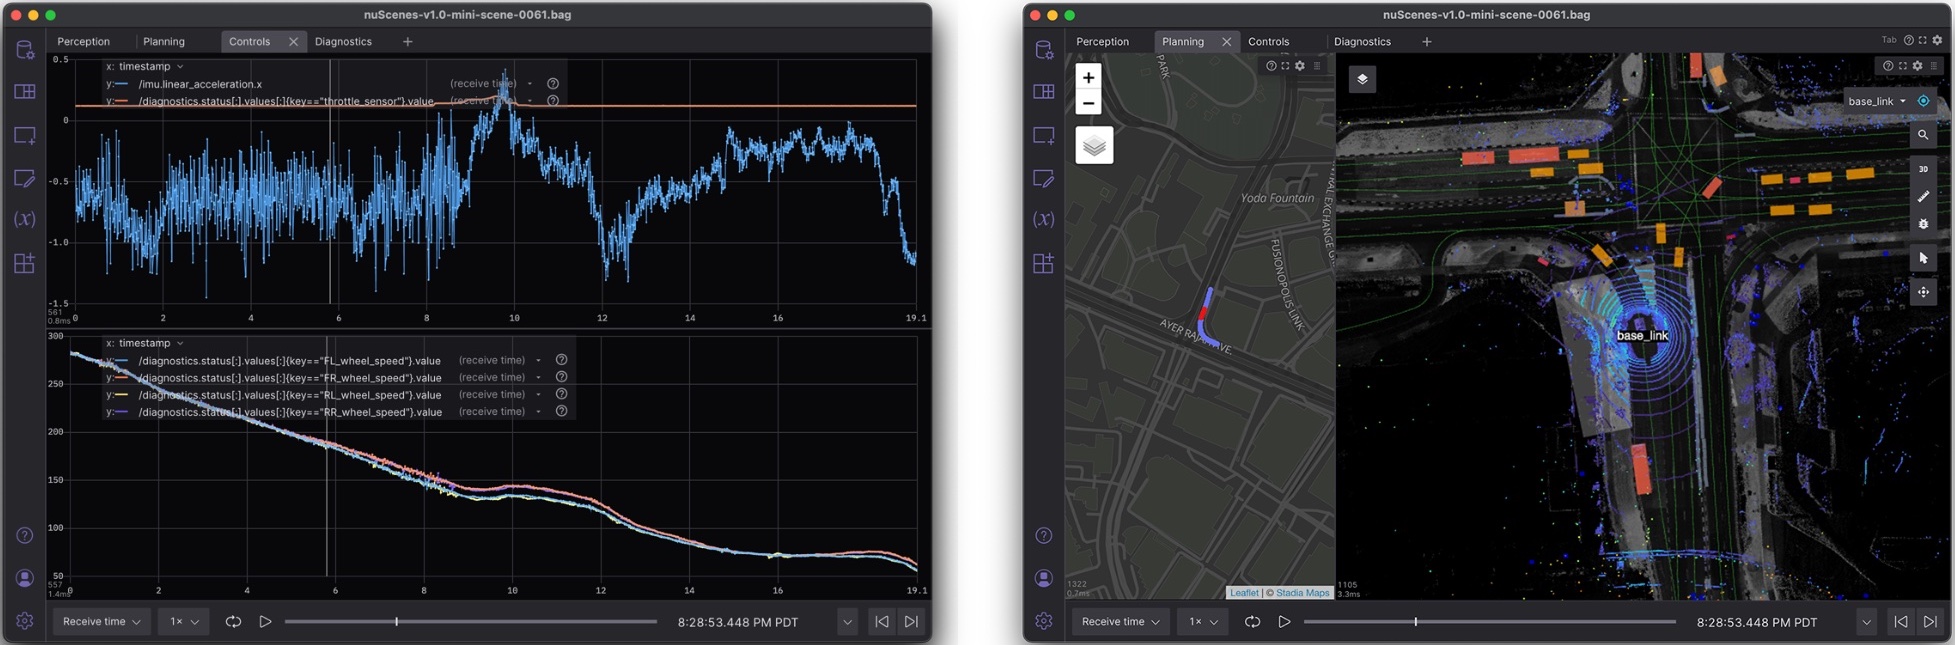
Every panel has a particular perform – one could plot values, one other mark coordinates on a map, nonetheless one other show 3D fashions in an interactive scene. Whether or not you’re troubleshooting your robotic’s planning stack or monitoring its diagnostics, there’s a visualization device for that activity.
With wealthy interactive information visualizations, our means can lastly catch as much as our ambitions. We are able to now extra deeply discover, analyze and make sense of our information – information that was impenetrable to us earlier than – to speed up ourselves in the direction of our objective.
The way forward for robotics and information visualization
For as seemingly goal as it’s, robotics improvement comes with no scarcity of subjective selections and inventive options. Although the tip outcome could also be concrete as “the robotic can now maneuver across the warehouse ground,” the means by which we get there may be an endlessly iterative course of that requires quite a lot of human intervention. To efficiently introduce robots to the general public at scale, we have to acknowledge robotics as a extra open-ended endeavor – one which produces extra interconnected points, has extra situational options, and thus requires extra numerous tooling than conventional software program improvement.
Robotics improvement nonetheless has a big selection of issues that we have to clear up – unwieldy testing infrastructures, unpredictable {hardware} improvement timelines, and scalable information administration. The record goes on. However there are few enhancements that can impression all verticals of robotics so powerfully as nice information visualization tooling.
 Concerning the Writer
Adrian Macneil is the co-founder and CEO of Foxglove, a startup offering highly effective information administration and visualization software program for robotics. Previous to founding Foxglove, Macneil led Infrastructure and developer instruments at autonomous driving firm Cruise.
He has a ardour for enhancing developer productiveness, and believes that optimizing the developer suggestions loop is crucial to unlocking speedy innovation in robotics.
[ad_2]

