


[ad_1]
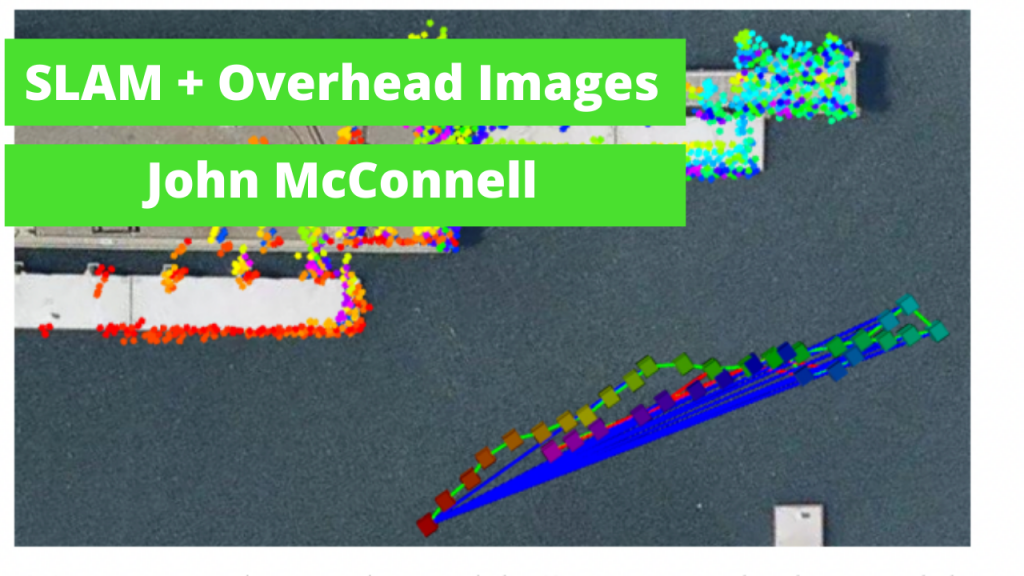
Underwater Autonomous Autos face difficult environments the place GPS Navigation is never potential. John McConnell discusses his analysis, introduced at ICRA 2022, into fusing overhead imagery with conventional SLAM algorithms. This analysis leads to a extra strong localization and mapping, with decreased drift generally seen in SLAM algorithms.
Satellite tv for pc imagery may be obtained without spending a dime or low value by means of Google or Mapbox, creating an simply deployable framework for corporations in trade to implement.
Hyperlinks
transcript
[00:00:00] I’m John McConnell:. That is overhead picture components for underwater sonar-based SLAM. So first let’s discuss SLAM. Slam permits us to estimate the car state and map as we go. Nevertheless, as mission progresses, drift will accumulate. We want loop closures to reduce this drift. Nevertheless, these aren’t trajectory dependent and infrequently ambiguous.
So the analysis query on this work is how can we use overhead photos to reduce the drift in our sonar based mostly SLAM system.
So first overhead photos are free or very low value from distributors like Mapbox and Google could are available in at an analogous decision to our sonar sensor at 5 to 10 centimeters,
some key challenges to be used overhead photos are in RGB. Sonar will not be, uh, overhead photos additionally are available in and so they, uh, top-down view. Or sonar photos are extra of a water degree view. [00:01:00] Uh, and clearly, uh, you understand, the vessels could also be in several places between picture seize, time and mission execution time.
okay. So what do we offer to the car a priori? Now we have a practical slam resolution, albeit with drift and preliminary GPS. After which this overhead picture segmentation proven in inexperienced, this identifies the construction. That’s going to be helpful as an support to navigation on this algorithm.
so conceptually, we’re going to start out at this pink dot. We’re going to maneuver alongside some trajectory to our present state. We’re going to say, “what ought to I see?” When it comes to the inexperienced segmentation. We will examine that to what we really see within the sonar imagery, resolve the variations in look, after which discover the transformation between these two knowledge constructions.
okay. So prime left inexperienced, with black background, now we have the candidate overhead picture, which is simply what we should always [00:02:00] see at our present state. Now we have a sonar picture from the identical time step, we’re going to take these and push them collectively into UNET. The output of UNET proven right here in magenta with black background, we will use the output of UNET, which is the candidate overhead picture reworked into the sonar picture body with the unique candidate, overhead picture in ICP to seek out the transformation between these two.
We will then roll that in to our sine graph..
on the left. Now we have an instance of slam mission with out overhead picture components, inexperienced strains or odometry pink strains are loop closures. You possibly can see in comparison with the grey overhead picture masks. Drift is closely evident. After we add the blue strains on the right-hand aspect, the overhead picture components you may see, we drastically scale back that mission drift in comparison with the grey overhead picture masks.
So to focus on the [00:03:00] novelty of our framework, we’re capable of resolve the variations between the overhead photos and the sonar photos and roll these overhead picture components into our already functioning slam system. Lowering the mission drift. We’re additionally capable of exhibit within the paper that we will prepare in simulation and performance on actual world knowledge.
Abate: Are you able to inform me a bit bit about your presentation simply now?
John McConnell: Certain. So we’re utilizing overhead photos that are satellite tv for pc photos or photos captured from a low flying UAV as an help for an underwater car utilizing a sonar based mostly SLAM resolution, uh, to cut back its drift.
Abate: Yeah. So this, you stated that is, or a unmanned floor autos or underwater autos?
John McConnell: That is for unmanned underwater autos.
Abate: Okay. All proper. Is it restricted to unmanned underwater autos? Why not additionally use it for…?
John McConnell: You should use it for any system you’d need, um, that’s utilizing sonar as the first perceptual enter. Uh, that’s additionally accumulating drift.[00:04:00]
The rationale we concentrate on unmanned underwater autos is as a result of GPS doesn’t work underneath water, proper? So we’re, we’re doing is utilizing these overhead photos as a GPS proxy, principally to take a steady SLAM resolution. That’s drifting with time, it’s getting worse with time and we’re taking take a look at these overhead photos we’re utilizing, uh, CNN convolutional, neural community.
To work out what precisely is in our sonar imagery and our overhead imagery to fuse them and scale back the slam drift.
Abate: Yeah. So principally, as you’re doing all your slam, it’s fairly good on the piece to piece, uh, localization, however then it drifts over time and that is permitting you to remain locked in, in place.
John McConnell: Yeah.
We will simply say, you understand, hold it on the rails, proper? Yeah.
Abate: So, after which the, um, so the imagery that you just’re getting satellite tv for pc imagery. The place are you getting this from?
John McConnell: Yeah. So this can be a free or very low value from [00:05:00] distributors like Mapbox, Google, and I’m positive there’s different ones on the market. And if, uh, you understand, you have been working in a army software, you’d have entry to some even higher, yeah, satellite tv for pc imagery, uh, or you can use, you understand, uh, DGI Phantom to place it up over the survey space earlier than you exit on it. So it’s, it’s fairly versatile with regard to the supply of the overhead imagery, however we do section it. Uh, so we determine the construction that we care about and the construction that we don’t care about.
Abate: Yeah. So possibly for a excessive value software, then you may really get a drone, go on the market and map it your self.
John McConnell: Yeah. Or yeah. Or job a satellite tv for pc. Yeah.
Abate: Or a job to settle. Yeah, so, and, um, effectively, so what’s the frequency charge that say the satellite tv for pc photos are typically updating by after which, is that this one thing that you concentrate on as you’re finding your SLAM algorithm on the satellite tv for pc imagery?
John McConnell: Yeah. So your query is actually, if I’ve my, uh, satellite tv for pc picture or my overhead picture of the surroundings, proper. And I take that image [00:06:00] on a Tuesday. However I’m gonna go do my work on Friday, proper. Have issues modified?
And proper. The reply is totally. Sure. Proper. We’re working in a littoral surroundings. So nearshore environments and we take a look at primarily in arenas.
So whenever you take that overhead picture, you may have a smattering of small boats, proper? These boats aren’t in the identical place. Proper? In order that’s why we use this convolutional neural community to help within the translation, not translation like X, Y, however translation:
“I see this in sonar and I’ve this prior, you understand, sketched out of what must be there, given my overhead picture”, however we intentionally omit vessels from the overhead picture segmentation and a part of what the CNN is coaching to study.
Is to additionally omit objects that aren’t current within the overhead imagery.
Abate: So that you’re really detecting like what kind of object is that this? Such as you, you may perceive this can be a dynamic object. We don’t [00:07:00] count on it to be right here tomorrow. Uh, however this can be a panorama or this can be a constructing or a port…
John McConnell: Or a pier yeah. Yeah. We rely closely on constructions, uh, that we count on to not transfer.
Proper? So breakwaters, piers, issues like that,
Abate: And that is all mechanically calculated.
John McConnell: We don’t explicitly name out every object and say, okay, this can be a vessel. , I don’t care about this. What we do is we offer a context clue, which we name in our work and a “candidate, overhead picture”. And we additionally use the sonar picture.
We take these and push them into unit collectively and unit simply learns to drop out. Uh, what’s not within the context clues.
Abate: Yeah. And have there been any challenges that you just bumped into?
John McConnell: I imply, many, many, many challenges, uh, whenever you take a look at an algorithm like this, uh, one, the most important query that comes up is floor fact.
Proper? How do you grade? And the way do you additionally generate sufficient coaching knowledge for a knowledge hungry CNN like unit? Proper. So now we have to take care of a variety of that, uh, by working in simulation. [00:08:00]
Abate: And do you count on this to return out, say to be open supply or to trade? Sure. With any close to timeframe?
John McConnell: Sure.
Abate: When do you count on?
John McConnell: Absolutely within the subsequent six months?
Now we have our, uh, open-source SLAM framework, uh, which you’ll be able to have a look. Folks can get my private GitHub, https://github.com/jake3991. You’ll discover a Repo known as sonar slam that has the baseline slam system. And we’re anticipating to include the overhead picture stuff within the subsequent six months. Superior. Thanks. Yeah. Thanks.
transcript
tags: c-Analysis-Innovation, cx-Mapping-Surveillance, cx-Analysis-Innovation, podcast, Analysis, software program
Abate De Mey
Robotics and Go-To-Market Professional
[ad_2]

