



[ad_1]
The internal baby in many people feels an amazing sense of pleasure when stumbling throughout a pile of the fluorescent, rubbery combination of water, salt, and flour that put goo on the map: play dough. (Even when this occurs not often in maturity.)
Whereas manipulating play dough is enjoyable and simple for 2-year-olds, the shapeless sludge is tough for robots to deal with. Machines have change into more and more dependable with inflexible objects, however manipulating delicate, deformable objects comes with a laundry listing of technical challenges, and most significantly, as with most versatile buildings, when you transfer one half, you’re possible affecting all the pieces else.
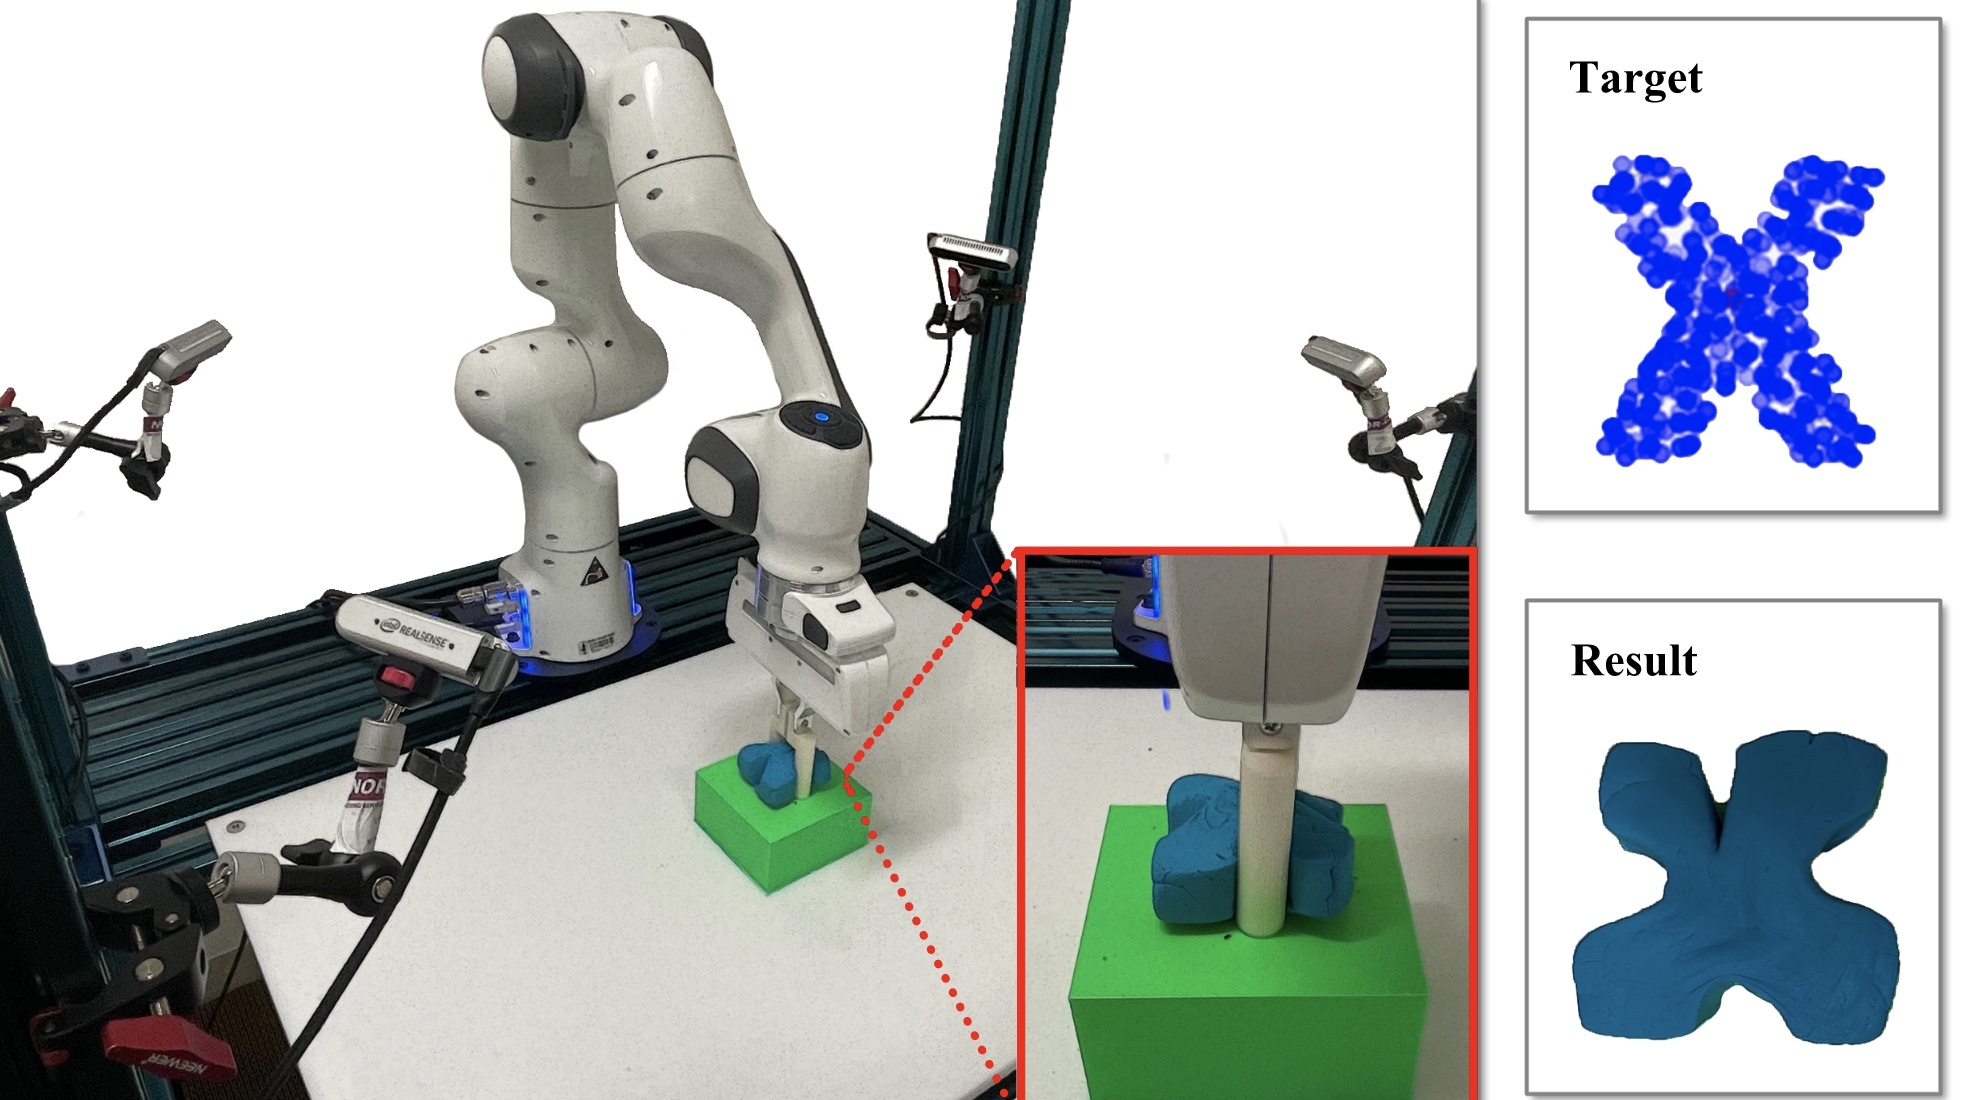
Scientists from MIT’s Laptop Science and Synthetic Intelligence Laboratory (CSAIL) and Stanford College just lately let robots take their hand at enjoying with the modeling compound, however not for nostalgia’s sake. Their new system learns straight from visible inputs to let a robotic with a two-fingered gripper see, simulate, and form doughy objects. “RoboCraft” may reliably plan a robotic’s habits to pinch and launch play dough to make varied letters, together with ones it had by no means seen. With simply 10 minutes of knowledge, the two-finger gripper rivaled human counterparts that teleoperated the machine — performing on-par, and at occasions even higher, on the examined duties.
“Modeling and manipulating objects with excessive levels of freedom are important capabilities for robots to discover ways to allow complicated industrial and family interplay duties, like stuffing dumplings, rolling sushi, and making pottery,” says Yunzhu Li, CSAIL PhD pupil and writer on a brand new paper about RoboCraft. “Whereas there’s been latest advances in manipulating garments and ropes, we discovered that objects with excessive plasticity, like dough or plasticine — regardless of ubiquity in these family and industrial settings — was a largely underexplored territory. With RoboCraft, we be taught the dynamics fashions straight from high-dimensional sensory knowledge, which gives a promising data-driven avenue for us to carry out efficient planning.”
With undefined, easy materials, the entire construction must be accounted for earlier than you are able to do any kind of environment friendly and efficient modeling and planning. By turning the pictures into graphs of little particles, coupled with algorithms, RoboCraft, utilizing a graph neural community because the dynamics mannequin, makes extra correct predictions concerning the materials’s change of shapes.
Sometimes, researchers have used complicated physics simulators to mannequin and perceive drive and dynamics being utilized to things, however RoboCraft merely makes use of visible knowledge. The inner-workings of the system depends on three elements to form delicate materials into, say, an “R.”
The primary half — notion — is all about studying to “see.” It makes use of cameras to gather uncooked, visible sensor knowledge from the atmosphere, that are then changed into little clouds of particles to symbolize the shapes. A graph-based neural community then makes use of stated particle knowledge to be taught to “simulate” the thing’s dynamics, or the way it strikes. Then, algorithms assist plan the robotic’s habits so it learns to “form” a blob of dough, armed with the coaching knowledge from the various pinches. Whereas the letters are a bit unfastened, they’re indubitably consultant.
In addition to cutesy shapes, the crew is (really) engaged on making dumplings from dough and a ready filling. Proper now, with only a two finger gripper, it’s an enormous ask. RoboCraft would want further instruments (a baker wants a number of instruments to cook dinner; so do robots) — a rolling pin, a stamp, and a mould.
A extra far sooner or later area the scientists envision is utilizing RoboCraft for help with family duties and chores, which may very well be of explicit assist to the aged or these with restricted mobility. To perform this, given the various obstructions that would happen, a way more adaptive illustration of the dough or merchandise can be wanted, and in addition to exploration into what class of fashions is perhaps appropriate to seize the underlying structural techniques.
“RoboCraft primarily demonstrates that this predictive mannequin could be realized in very data-efficient methods to plan movement. In the long term, we’re fascinated by utilizing varied instruments to control supplies,” says Li. “If you consider dumpling or dough making, only one gripper wouldn’t be capable to remedy it. Serving to the mannequin perceive and attain longer-horizon planning duties, similar to, how the dough will deform given the present device, actions and actions, is a subsequent step for future work.”
Li wrote the paper alongside Haochen Shi, Stanford grasp’s pupil; Huazhe Xu, Stanford postdoc; Zhiao Huang, PhD pupil on the College of California at San Diego; and Jiajun Wu, assistant professor at Stanford. They may current the analysis on the Robotics: Science and Techniques convention in New York Metropolis. The work is partly supported by the Stanford Institute for Human-Centered AI (HAI), the Samsung International Analysis Outreach (GRO) Program, the Toyota Analysis Institute (TRI), and Amazon, Autodesk, Salesforce, and Bosch.
[ad_2]

