



[ad_1]
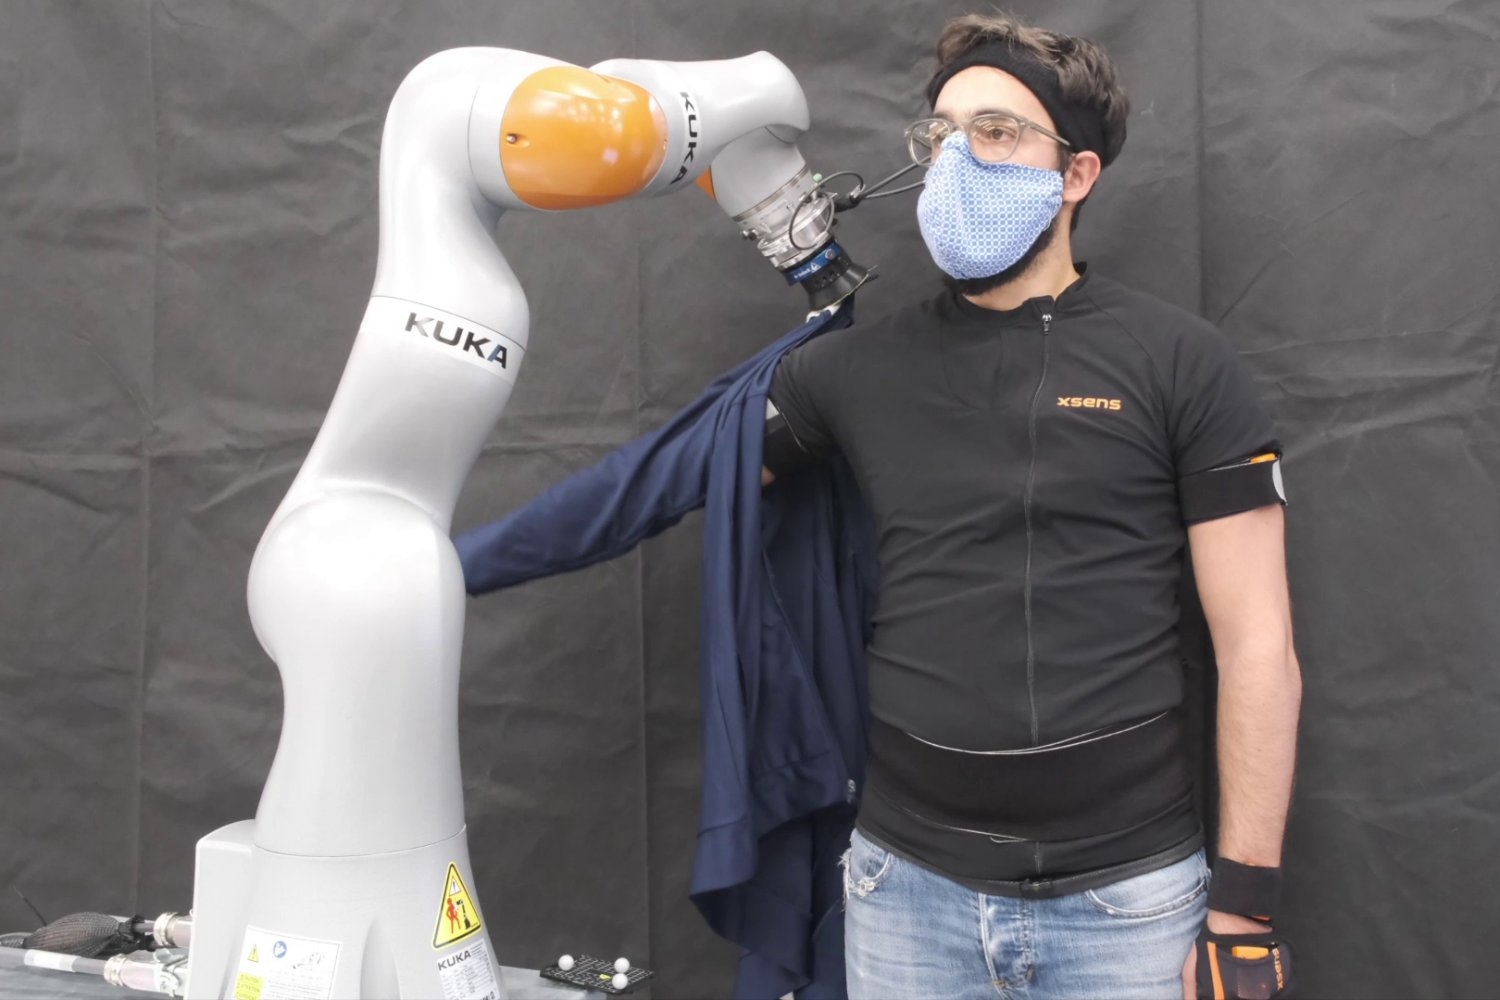
Robots are already adept at sure issues, corresponding to lifting objects which are too heavy or cumbersome for folks to handle. One other software they’re nicely suited to is the precision meeting of things like watches which have giant numbers of tiny components — some so small they’ll barely be seen with the bare eye.
“A lot more durable are duties that require situational consciousness, involving nearly instantaneous diversifications to altering circumstances within the atmosphere,” explains Theodoros Stouraitis, a visiting scientist within the Interactive Robotics Group at MIT’s Pc Science and Synthetic Intelligence Laboratory (CSAIL).
“Issues change into much more difficult when a robotic has to work together with a human and work collectively to securely and efficiently full a process,” provides Shen Li, a PhD candidate within the MIT Division of Aeronautics and Astronautics.
Li and Stouraitis — together with Michael Gienger of the Honda Analysis Institute Europe, Professor Sethu Vijayakumar of the College of Edinburgh, and Professor Julie A. Shah of MIT, who directs the Interactive Robotics Group — have chosen an issue that provides, fairly actually, an armful of challenges: designing a robotic that may assist folks dress. Final yr, Li and Shah and two different MIT researchers accomplished a venture involving robot-assisted dressing with out sleeves. In a brand new work, described in a paper that seems in an April 2022 challenge of IEEE Robotics and Automation, Li, Stouraitis, Gienger, Vijayakumar, and Shah clarify the headway they’ve made on a extra demanding drawback — robot-assisted dressing with sleeved garments.
The massive distinction within the latter case is because of “visible occlusion,” Li says. “The robotic can’t see the human arm throughout the whole dressing course of.” Particularly, it can’t at all times see the elbow or decide its exact place or bearing. That, in flip, impacts the quantity of drive the robotic has to use to tug the article of clothes — corresponding to a long-sleeve shirt — from the hand to the shoulder.
To cope with the difficulty of obstructed imaginative and prescient, the workforce has developed a “state estimation algorithm” that enables them to make fairly exact educated guesses as to the place, at any given second, the elbow is and the way the arm is inclined — whether or not it’s prolonged straight out or bent on the elbow, pointing upwards, downwards, or sideways — even when it’s fully obscured by clothes. At every occasion of time, the algorithm takes the robotic’s measurement of the drive utilized to the fabric as enter after which estimates the elbow’s place — not precisely, however putting it inside a field or quantity that encompasses all doable positions.
That information, in flip, tells the robotic how you can transfer, Stouraitis says. “If the arm is straight, then the robotic will observe a straight line; if the arm is bent, the robotic must curve across the elbow.” Getting a dependable image is essential, he provides. “If the elbow estimation is incorrect, the robotic might resolve on a movement that might create an extreme, and unsafe, drive.”
The algorithm features a dynamic mannequin that predicts how the arm will transfer sooner or later, and every prediction is corrected by a measurement of the drive that’s being exerted on the fabric at a selected time. Whereas different researchers have made state estimation predictions of this kind, what distinguishes this new work is that the MIT investigators and their companions can set a transparent higher restrict on the uncertainty and assure that the elbow will likely be someplace inside a prescribed field.
The mannequin for predicting arm actions and elbow place and the mannequin for measuring the drive utilized by the robotic each incorporate machine studying methods. The info used to coach the machine studying methods have been obtained from folks carrying “Xsens” fits with built-sensors that precisely observe and document physique actions. After the robotic was skilled, it was in a position to infer the elbow pose when placing a jacket on a human topic, a person who moved his arm in varied methods in the course of the process — typically in response to the robotic’s tugging on the jacket and typically partaking in random motions of his personal accord.
This work was strictly targeted on estimation — figuring out the placement of the elbow and the arm pose as precisely as doable — however Shah’s workforce has already moved on to the following section: growing a robotic that may frequently regulate its actions in response to shifts within the arm and elbow orientation.
Sooner or later, they plan to deal with the difficulty of “personalization” — growing a robotic that may account for the idiosyncratic methods wherein totally different folks transfer. In an analogous vein, they envision robots versatile sufficient to work with a various vary of fabric supplies, every of which can reply considerably in another way to pulling.
Though the researchers on this group are undoubtedly concerned with robot-assisted dressing, they acknowledge the expertise’s potential for a lot broader utility. “We didn’t specialize this algorithm in any option to make it work just for robotic dressing,” Li notes. “Our algorithm solves the overall state estimation drawback and will due to this fact lend itself to many doable functions. The important thing to all of it is being able to guess, or anticipate, the unobservable state.” Such an algorithm might, as an illustration, information a robotic to acknowledge the intentions of its human accomplice as it really works collaboratively to maneuver blocks round in an orderly method or set a dinner desk.
Right here’s a conceivable situation for the not-too-distant future: A robotic might set the desk for dinner and perhaps even clear up the blocks your little one left on the eating room ground, stacking them neatly within the nook of the room. It might then assist you get your dinner jacket on to make your self extra presentable earlier than the meal. It would even carry the platters to the desk and serve acceptable parts to the diners. One factor the robotic wouldn’t do could be to eat up all of the meals earlier than you and others make it to the desk. Luckily, that’s one “app” — as in software slightly than urge for food — that’s not on the drafting board.
This analysis was supported by the U.S. Workplace of Naval Analysis, the Alan Turing Institute, and the Honda Analysis Institute Europe.
[ad_2]

