


[ad_1]
|
Hearken to this text  |
Researchers at MIT’s Pc Science and Synthetic Intelligence Laboratory (CSAIL) have created a tender pneumatic actuator and a scalable pipeline, known as PneuAct, to computationally design and digitally fabricate the actuator.
Mushy, pneumatic actuators can present excessive response charges and energy to enter ratios, however creating them could be tedious. The actuators require a handbook design and fabrication pipeline, which implies that researchers should undergo many trial and error cycles to see if their actuators work.
CSAIL’s course of entails a machine knitting course of with a conductive yarn for sensing. Earlier than creating the textile piece of the actuator, a human designer can specify sew and sensor design patterns to program how the actuator will transfer. The workforce can simulate the actuator’s motion earlier than printing.
“Utilizing digital machine knitting, which is a quite common manufacturing methodology in at the moment’s textile business, allows ‘printing’ a design in a single go, which makes it rather more scalable,” Yiyue Luo, MIT CSAIL PhD pupil and lead writer of a brand new paper concerning the analysis, mentioned. “Mushy pneumatic actuators are intrinsically compliant and versatile, and mixed with clever supplies, have grow to be the spine of many robots and assistive applied sciences – and fast fabrication with our design device can hopefully improve ease and ubiquity.”
The knitted textile piece is fastened to an off-the-shelf rubber silicone tube. To date, CSAIL’s workforce has created a number of prototypes with this actuator, together with an assistive glove, a tender hand, an interactive robotic and a pneumatic strolling quadruped.
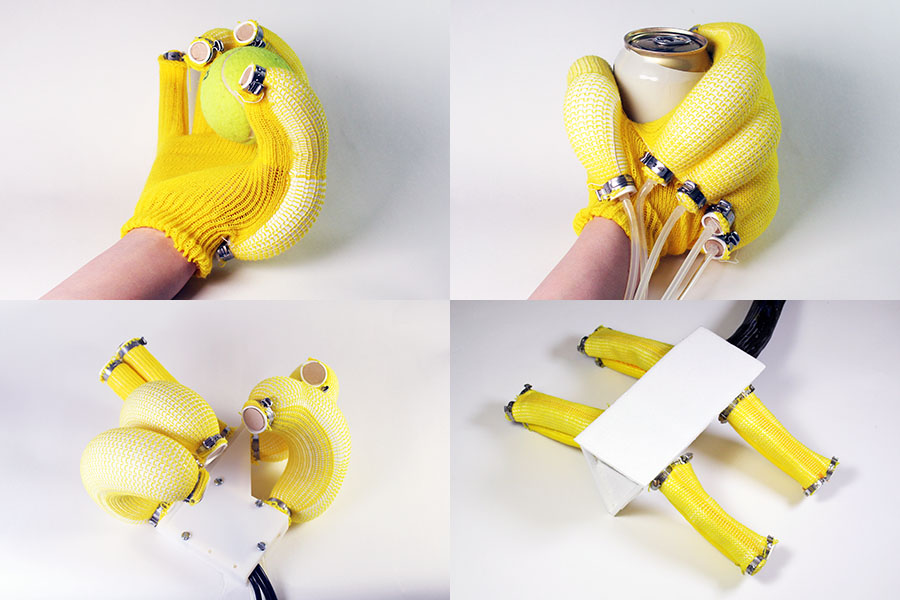
CSAIL’s tender actuator has been made into a lot of prototypes, together with an assistive glove and quadruped. | Supply: MIT CSAIL
CSAIL’s prototypes might really feel when it was touched by human fingers particularly and will react to that contact. This sense of contact give the actuator a lot of potential real-world purposes. The workforce’s glove, for instance, could be worn on a human hand to assist complement muscle motion. This minimizes the quantity of muscle exercise required for doing actions.
The actuators might even be used to create an exoskeleton to assist complement human movement and restore motion. CSAIL’s workforce created a sleeve that makes use of the actuator to assist customers bend their elbow or knee.
The workforce included a lot of completely different sorts of sensing into the actuator, together with resistive stress sensing and capacitive sensing. Resistive stress sensing permits the actuator to sense how a lot drive is being utilized to an object whereas gripping it, and whether or not the grasp is profitable. Capacitive sensing permits the actuator to realize data on the supplies it touches.
Shifting ahead, the analysis workforce plans to discover actuators of various shapes, as an alternative of being constrained by the tube-shaped actuator. In addition they plan to increase PneuAct to include a task-driven, optimization-based design. This manner a person can decide goal poses and sew patterns can then be robotically synthesized.
The workforce’s whole analysis could be learn right here.
[ad_2]

