


[ad_1]
It is a new sequence wanting on the detailed design of varied robots. To start out with we will probably be wanting on the design of two completely different robots that had been used for the DARPA Subterranean Problem. Each of those robots had been designed for working in advanced subterranean environments, together with Caves, Mines & City environments. Each of those robots introduced are from the Carnegie Mellon College Explorer staff. Whereas I’m writing these posts, this was a staff effort that required many individuals to achieve success. (If anybody on Crew Explorer is studying this, thanks for every part, you’re all superior.)
These posts are skipping the system necessities step of the design course of. See right here for extra particulars on defining system necessities.
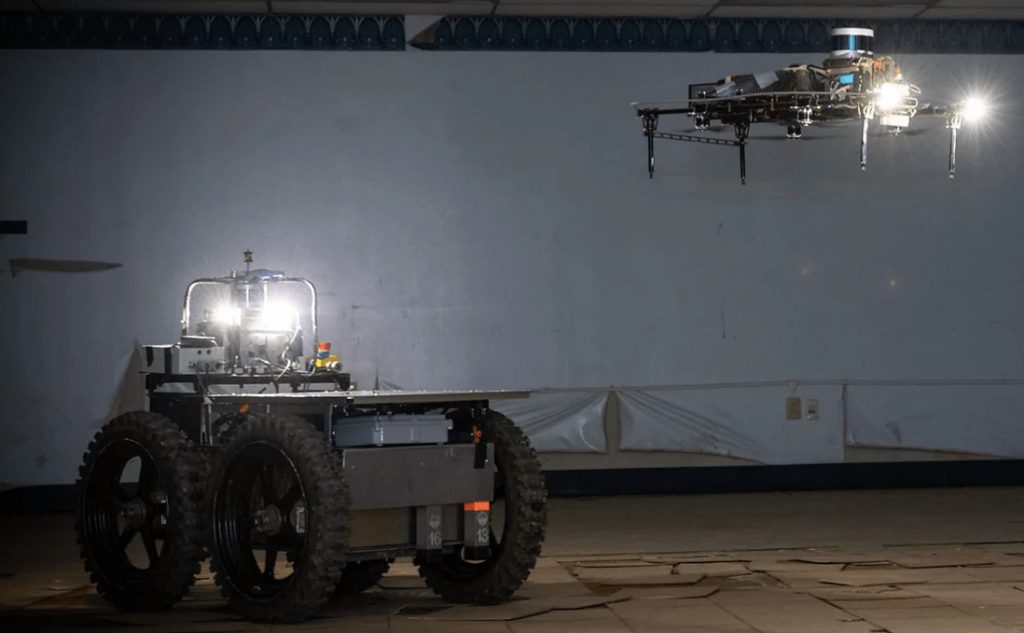
SubT Floor UGV and DS Drone ImageTeam Explorer R1 Floor Robotic and DS Drone [Source]
R3 Floor robotic (UGV)
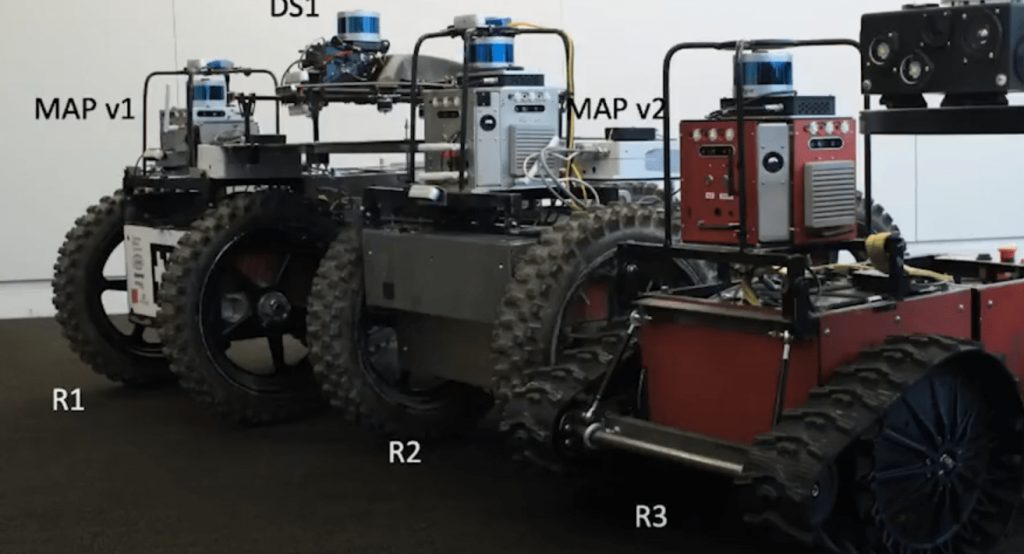
For the SubT problem three floor autos had been developed all of a similiar design. The bottom robots had been identified with the moniker of R#, the place # is the order we constructed them in. The first distinction between the three variations are
R1 – Static Chassis, so the chassis has minimal floor compliance when driving over obstacles and uneven surfaces. R1 was initially speculated to have a differencing mechanism for compliance, nonetheless on account of time constraints it was unnoticed from this primary model. R1 is pictured above.
R2 – Has the differencing mechanism and was designed as initially deliberate.
R3 – Is nearly similar to R2, however smaller. This robotic was constructed for navigating smaller areas and likewise to have the ability to climb up and down steps. It additionally makes use of completely different motors for the driving the wheels.
DS drone
The unique drone design utilized by Crew Explorer known as their drones D1, D2, and many others.. This let a mix of UGV +Drone go by joint designations reminiscent of R2D2. Early on, the staff switched to a smaller drone design that was known as DS1, DS2, and many others.. The place DS is brief for Drone Small.
The drone design publish are cut up into two sections. The primary is in regards to the precise drone platform, and the second is in regards to the payload that sat on high of the drone.
Mechanical & wheels
Robotic dimension determination
After we now have the checklist of system necessities we begin with the design of the mechanical construction of the robotic. On this case we determined {that a} wheeled robotic can be finest. We needed to have the biggest wheels doable to assist climb over obstacles, nonetheless, we additionally wanted to maintain our sensors on the high of the car above the wheels and be capable of slot in openings 1 x 1 meters. These necessities set the utmost dimension of the robotic in addition to the utmost dimension of the wheels.
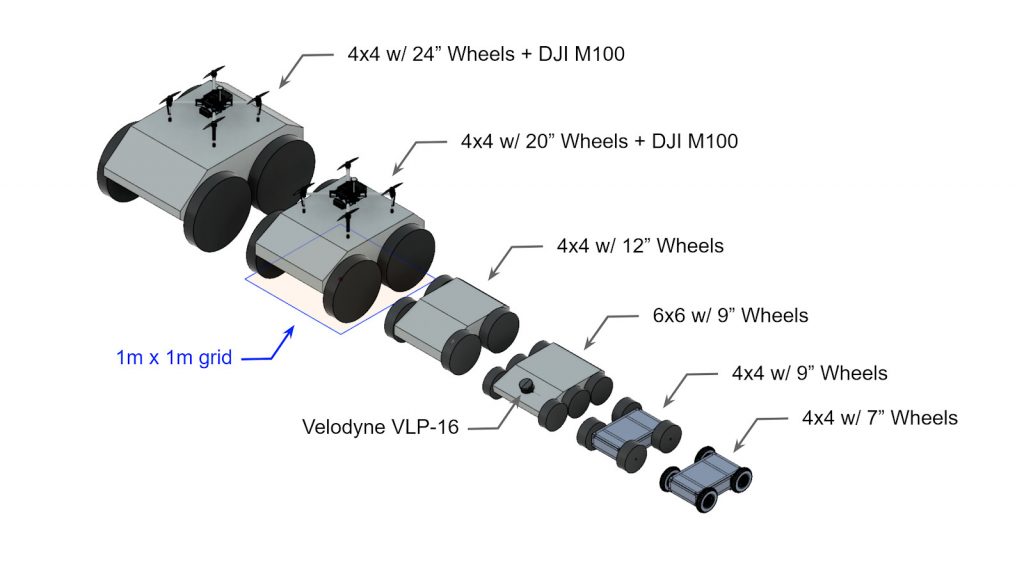
The ultimate dimensions of the primary two autos (R1 and R2) had been round (L x W x H) 1.2 x 0.8 x 0.8 meters (3.9 x 2.6 x 2.6 ft). The third smaller car was round 1 x 0.6 m (3.2 x 1.9 ft) and designed to suit via 0.7×0.7 m openings.
Steering strategy
Early on we additionally wanted to find out the strategy of driving. Do we wish wheels or tracks? Will we wish to steer with ackerman steering, rocker-bogie, skid steer, and many others.?
See right here for extra particulars on steering choice.
We selected to make use of a skid steer 4 wheeled drive strategy for the simplicity of management and the power to show in place (level turns). At first of the competitors we weren’t targeted on stair climbing, which could have modified a few of our design choices.
Suspension
The subsequent step was to find out the suspension sort. A suspension is required so that every one 4 of the wheels make contact with the bottom. If the robotic had a static mounted body solely three of the wheels would possibly make contact with the bottom when on uneven surfaces. This would scale back our stability and traction.
We determined early on that we needed a passive suspension for the simplicity of not having energetic elements. With a passive suspension we had been completely different sort of physique averaging. We roughly had two decisions, front-pivot or side-to-side.
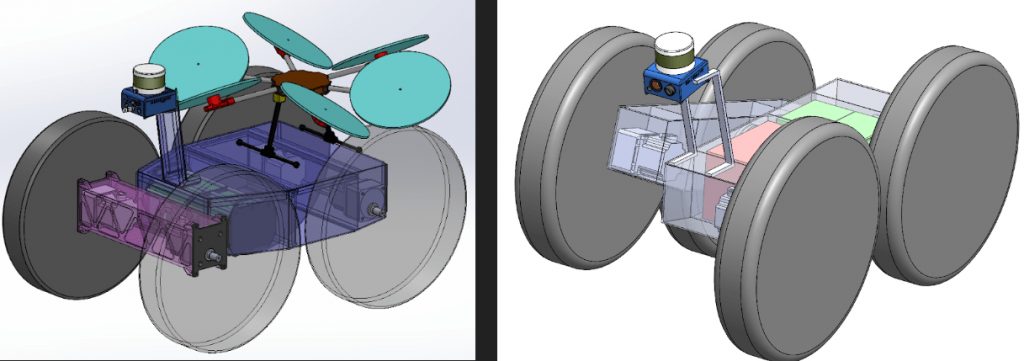
Left picture exhibits a front-pivot strategy. Proper picture exhibits a side-to-side differencing methodology.
We determined to decide on the front-pivot methodology, nonetheless we determined to make the pivot be roughly centered within the car. This allowed us to place all the electronics within the entrance and the batteries within the rear. The front-pivot methodology we felt can be higher for climbing up stairs and for climbing over obstacles on degree’ish terrain. Additionally importantly this strategy made it simpler to hold a drone on the bottom car.
Chassis design
At this level we began designing the chassis. This was an necessary step in order that we might estimate the whole weight with a view to spec the drive-train. Concepts for the chassis had been every part from constructing with 80/20 to constructing an aluminum body and populating it with elements, to a strong welded chassis. We chosen to make use of a welded metal tube chassis for the energy. We would have liked a robotic that might survive something we did to it. This proved to be a smart determination when the robotic crashed or fell over cliffs. The draw back of the metal was elevated mass.
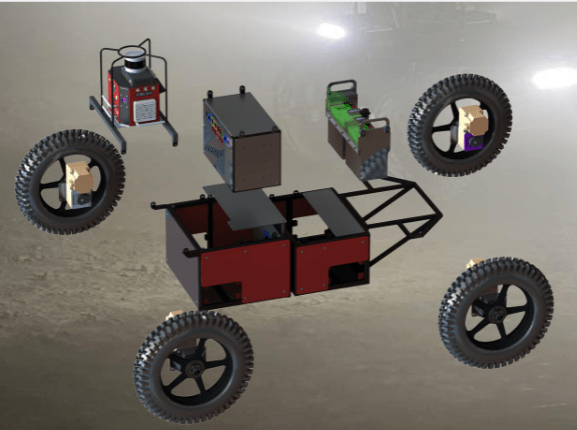
For the pivot we discovered a big crossed curler bearing that we had been ready to make use of to connect the 2 metal packing containers collectively. The massive bore within the center was helpful for passing wires/cables via for batteries, motors, and many others…
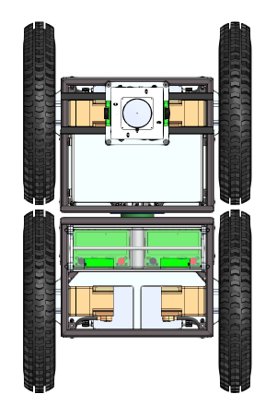
A part of the chassis design was additionally figuring out the place all the elements ought to mount. Having the batteries (inexperienced packing containers in picture above) within the rear helps us climb obstacles. Different targets had been to maintain the bottom clearance as excessive as doable whereas maintaining the middle of gravity (CG) as little as doable. Since these are competing targets, a part of the design course of was to develop a cheerful medium.
So as to preserve modularity for service, every wheel module had the motor controller, motor, gear field, and bearing block as a strong unit that might be swapped between robots if there was any points. This additionally allowed many of the wiring to be a part of that block. The one cables that wanted to be linked to every of the modules from the robotic had been energy, CAN communications, and the emergency cease line; all of which had been connectorized.
For electronics on R1 and R2 we constructed an electronics field that was separate from the robotic and might be faraway from the robotic as wanted. On R3 we constructed the electronics into the robotic itself. This modular strategy was very helpful once we needed to do some welding to the chassis post-build for modifications. The draw back of the modular strategy for electronics was that working within the electronics field was harder then within the open R3. Additionally the time for fabricating and wiring the R1/R2 electronics packing containers was significantly greater than the open R3 electronics. We additionally had a number of failures throughout testing associated to the connectors from the electronics packing containers.
Wheel design
We debated so much about what sort of wheel to make use of, in the end we used bike wheels as a result of simplicity of acquiring them and mounting them. The wheel diameter we desired additionally lined up very effectively with bike wheels. So as to get higher traction and skill to climb over obstacles we appreciated the broader tires.
R1 and R2 had a wheel diameter of 0.55m, R3 had a wheel diameter of 0.38m. This gave R1 and R2 a floor clearance of 0.2m, and R3 a floor clearance of 0.12m.
The wheel hubs ended up being a distinct story. We discovered strong steel rims that we needed to machine giant quantities of steel out of with a view to stability the energy and the load.
The R1 and R2 robots had been round 180kg (400lb)*, the wheels had been for a car considerably heavier. As such we put a small quantity of strain within the wheels to maintain them from falling off, nonetheless we tried to maintain the strain low to extend the bottom compliance of the wheels. This methodology added a really small quantity of compliance, we tried eradicating a few of the rubber from the sidewalls, however was not capable of get a cheerful medium between limiting the wheel deforming throughout level turns and rising floor compliance.
We had been additionally involved how the bike tires would do when level turning and if we’d rip the wheels from the edges. To counter this we put in a beadlock system into every of the wheels. The beadlock was a curved section put in in a number of locations to sandwich the tire to the rim. We by no means had a wheel separate from the rim, so our strategy undoubtedly labored, nonetheless it was a ache to put in.
*R3 was round 90 kg (200 lbs). We tried utilizing completely different wheels and tracks to get R3 to climb stairs effectively. Nevertheless that story is for an additional publish…
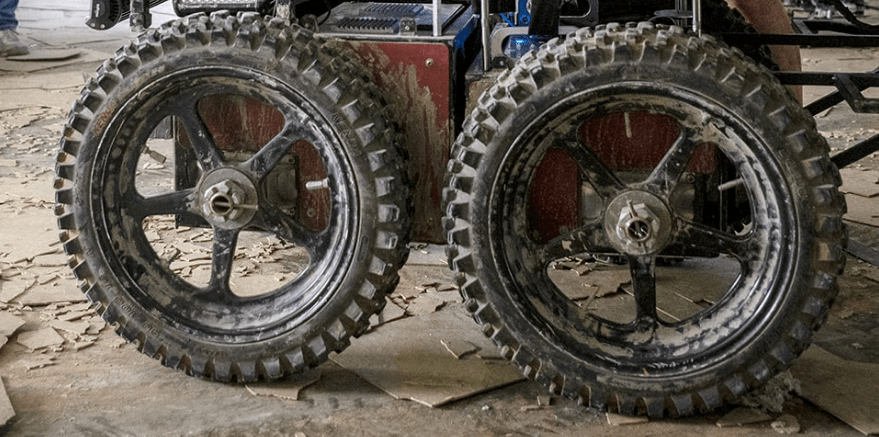
The black rims had been strong steel that we machined the wedges into with a view to light-weight them. The three steel posts in these wedges are the beadlock tensioning bolts. You can too see the fortress nut and pin that holds the wheel to the axle. This picture is from R2, you may see the hole between the entrance and rear sections of the robotic the place the pivot is.
Drive-train choice
Now that we had a mass estimate and system necessities for pace and impediment clearance we are able to begin to spec the drive-train. The opposite piece of knowledge that we wanted and needed to focus on with {the electrical} staff was the voltage of the battery. Totally different bus voltages tremendously impacts the motors accessible for a given pace and torque. We selected a 51.2v nominal bus voltage. This introduced an issue because it was very onerous to seek out the pace/torques we needed at that voltage. We ended up deciding on a 400W 1/2HP motor+gearbox from Oriental Motors with a parallel 100:1 gearbox that enables us to drive at a most pace of two.5m/s.
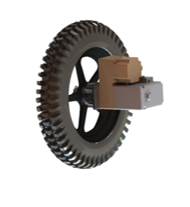
The half numbers of the motors and gearbox on R1 and R2 had been BLVM640N-GFS + GFS6G100FR.
The half numbers of the motors and gearbox on the smaller R3 had been Maxon EC 90 Flat + GP81A.
Subsequent steps
Now that we all know the mechanics of the robotic we are able to begin constructing it. Within the subsequent publish we’ll begin wanting on the electronics and motor controls. Whereas the character of the weblog makes it appear that this design is a serial course of, in actuality a number of issues are occurring in parallel. Whereas the mechanical staff is designing the chassis, {the electrical} staff is discovering {the electrical} elements wanted to ensure that the mechanical particular person to know what wants mounted.
It’s also necessary to work with {the electrical} staff to determine wire routing whereas the chassis is being developed.
Notice of the editor: This publish has been merged from the posts “Fingers On Floor Robotic & Drone Design Collection” and “Mechanical & Wheels – Fingers On Floor Robotic Design“.
Robots for Roboticists
David Kohanbash is a Robotics Engineer in Pittsburgh, PA in america. He loves constructing, taking part in and dealing with Robots.
Robots for Roboticists
David Kohanbash is a Robotics Engineer in Pittsburgh, PA in america. He loves constructing, taking part in and dealing with Robots.
[ad_2]

