



[ad_1]
Folks can flexibly maneuver objects of their bodily environment to perform numerous objectives. One of many grand challenges in robotics is to efficiently prepare robots to do the identical, i.e., to develop a general-purpose robotic able to performing a mess of duties based mostly on arbitrary person instructions. Robots which are confronted with the actual world can even inevitably encounter new person directions and conditions that weren’t seen throughout coaching. Subsequently, it’s crucial for robots to be educated to carry out a number of duties in quite a lot of conditions and, extra importantly, to be able to fixing new duties as requested by human customers, even when the robotic was not explicitly educated on these duties.
Present robotics analysis has made strides in direction of permitting robots to generalize to new objects, process descriptions, and objectives. Nonetheless, enabling robots to finish directions that describe solely new duties has largely remained out-of-reach. This drawback is remarkably tough because it requires robots to each decipher the novel directions and determine methods to full the duty with none coaching knowledge for that process. This objective turns into much more tough when a robotic must concurrently deal with different axes of generalization, corresponding to variability within the scene and positions of objects. So, we ask the query: How can we confer noteworthy generalization capabilities onto actual robots able to performing complicated manipulation duties from uncooked pixels? Moreover, can the generalization capabilities of language fashions assist assist higher generalization in different domains, corresponding to visuomotor management of an actual robotic?
In “BC-Z: Zero-Shot Activity Generalization with Robotic Imitation Studying”, printed at CoRL 2021, we current new analysis that research how robots can generalize to new duties that they weren’t educated to do. The system, referred to as BC-Z, contains two key elements: (i) the gathering of a large-scale demonstration dataset protecting 100 completely different duties and (ii) a neural community coverage conditioned on a language or video instruction of the duty. The ensuing system can carry out a minimum of 24 novel duties, together with ones that require interplay with pairs of objects that weren’t beforehand seen collectively. We’re additionally excited to launch the robotic demonstration dataset used to coach our insurance policies, together with pre-computed process embeddings.
 |
| The BC-Z system permits a robotic to finish directions for brand new duties that the robotic was not explicitly educated to do. It does so by coaching the coverage to take as enter an outline of the duty together with the robotic’s digital camera picture and to foretell the proper motion. |
Gathering Information for 100 Duties
Generalizing to a brand new process altogether is considerably more durable than generalizing to held-out variations in coaching duties. Merely put, we would like robots to have extra generalization throughout, which requires that we prepare them on giant quantities of various knowledge.
We accumulate knowledge by teleoperating the robotic with a digital actuality headset. This knowledge assortment follows a scheme just like how one may educate an autonomous automotive to drive. First, the human operator data full demonstrations of every process. Then, as soon as the robotic has discovered an preliminary coverage, this coverage is deployed beneath shut supervision the place, if the robotic begins to make a mistake or will get caught, the operator intervenes and demonstrates a correction earlier than permitting the robotic to renew.
This combination of demonstrations and interventions has been proven to considerably enhance efficiency by mitigating compounding errors. In our experiments, we see a 2x enchancment in efficiency when utilizing this knowledge assortment technique in comparison with solely utilizing human demonstrations.
| Instance demonstrations collected for 12 out of the 100 coaching duties, visualized from the attitude of the robotic and proven at 2x velocity. |
Coaching a Basic-Function Coverage
For all 100 duties, we use this knowledge to coach a neural community coverage to map from digital camera photos to the place and orientation of the robotic’s gripper and arm. Crucially, to permit this coverage the potential to resolve new duties past the 100 coaching duties, we additionally enter an outline of the duty, both within the type of a language command (e.g., “place grapes in pink bowl”) or a video of an individual doing the duty.
 |
| To perform quite a lot of duties, the BC-Z system takes as enter both a language command describing the duty or a video of an individual doing the duty, as proven right here. |
By coaching the coverage on 100 duties and conditioning the coverage on such an outline, we unlock the likelihood that the neural community will have the ability to interpret and full directions for brand new duties. It is a problem, nonetheless, as a result of the neural community must accurately interpret the instruction, visually determine related objects for that instruction whereas ignoring different muddle within the scene, and translate the interpreted instruction and notion into the robotic’s motion area.
Experimental Outcomes
In language fashions, it’s well-known that sentence embeddings generalize on compositions of ideas encountered in coaching knowledge. As an example, when you prepare a translation mannequin on sentences like “decide up a cup” and “push a bowl”, the mannequin also needs to translate “push a cup” accurately.
We research the query of whether or not the compositional generalization capabilities present in language encoders may be transferred to actual robots, i.e., having the ability to compose unseen object-object and task-object pairs.
We check this technique by pre-selecting a set of 28 duties, none of which have been among the many 100 coaching duties. For instance, one in all these new check duties is to select up the grapes and place them right into a ceramic bowl, however the coaching duties contain doing different issues with the grapes and putting different gadgets into the ceramic bowl. The grapes and the ceramic bowl by no means appeared in the identical scene throughout coaching.
In our experiments, we see that the robotic can full many duties that weren’t included within the coaching set. Under are just a few examples of the robotic’s discovered coverage.
| The robotic completes three directions of duties that weren’t in its coaching knowledge, proven at 2x velocity. |
Quantitatively, we see that the robotic can succeed to some extent on a complete of 24 out of the 28 held-out duties, indicating a promising capability for generalization. Additional, we see a notably small hole between the efficiency on the coaching duties and efficiency on the check duties. These outcomes point out that merely enhancing multi-task visuomotor management might significantly enhance efficiency.
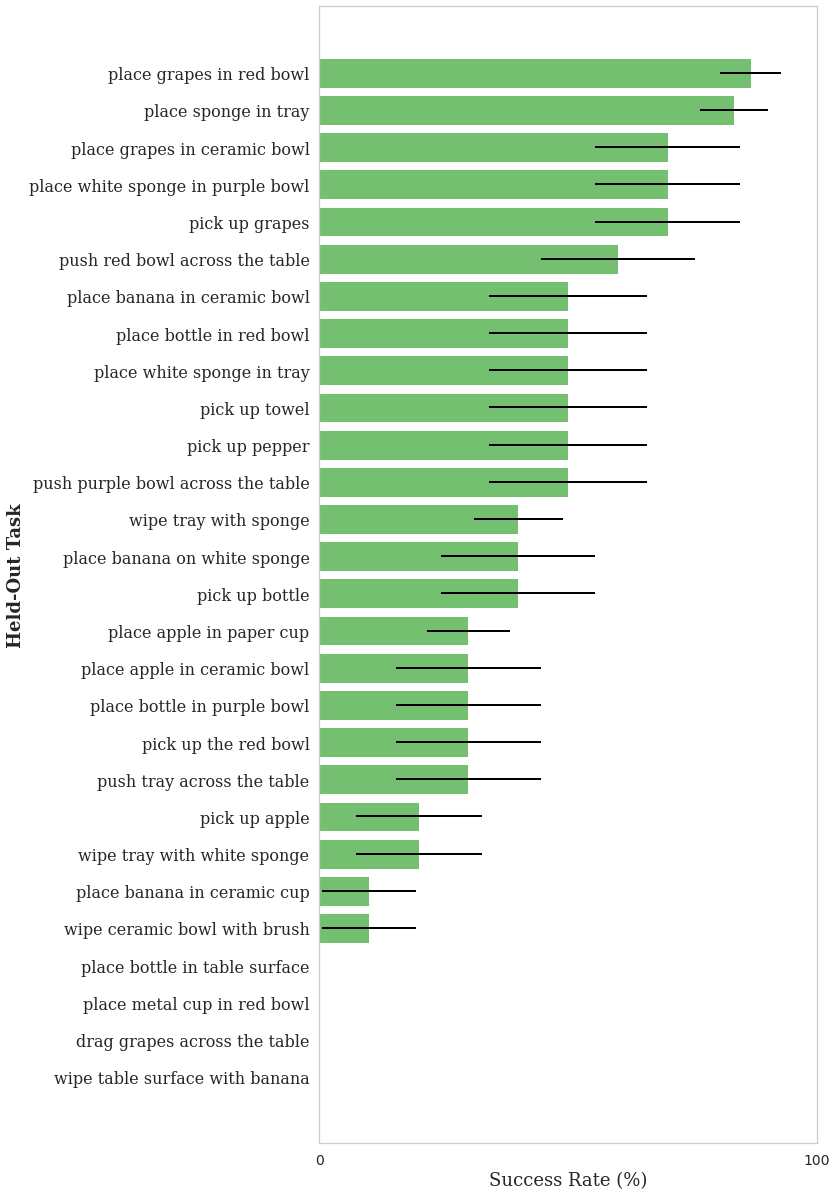 |
| The BC-Z efficiency on held-out duties, i.e., duties that the robotic was not educated to carry out. The system accurately interprets the language command and interprets that into motion to finish lots of the duties in our analysis. |
Takeaways
The outcomes of this analysis present that straightforward imitation studying approaches may be scaled in a manner that permits zero-shot generalization to new duties. That’s, it exhibits one of many first indications of robots having the ability to efficiently perform behaviors that weren’t within the coaching knowledge. Curiously, language embeddings pre-trained on ungrounded language corpora make for glorious process conditioners. We demonstrated that pure language fashions can’t solely present a versatile enter interface to robots, however that pretrained language representations really confer new generalization capabilities to the downstream coverage, corresponding to composing unseen object pairs collectively.
In the middle of constructing this technique, we confirmed that periodic human interventions are a easy however necessary approach for attaining good efficiency. Whereas there’s a substantial quantity of labor to be executed sooner or later, we consider that the zero-shot generalization capabilities of BC-Z are an necessary development in direction of growing the generality of robotic studying programs and permitting individuals to command robots. Now we have launched the teleoperated demonstrations used to coach the coverage on this paper, which we hope will present researchers with a worthwhile useful resource for future multi-task robotic studying analysis.
Acknowledgements
We want to thank the co-authors of this analysis: Alex Irpan, Mohi Khansari, Daniel Kappler, Frederik Ebert, Corey Lynch, and Sergey Levine. This undertaking was a collaboration between Google Analysis and the On a regular basis Robotic Venture. We want to give particular because of Noah Brown, Omar Cortes, Armando Fuentes, Kyle Jeffrey, Linda Luu, Sphurti Kirit Extra, Jornell Quiambao, Jarek Rettinghouse, Diego Reyes, Rosario Jau-regui Ruano, and Clayton Tan for overseeing robotic operations and amassing human movies of the duties, in addition to Jeffrey Bingham, Jonathan Weisz, and Kanishka Rao for worthwhile discussions. We might additionally wish to thank Tom Small for creating animations on this publish and Paul Mooney for serving to with dataset open-sourcing.
[ad_2]

