


[ad_1]
By Alexander Badri-Sprowitz, Alborz Aghamaleki Sarvestani, Metin Sitti and Linda Behringer
If a Tyrannosaurus Rex residing 66 million years in the past featured an analogous leg construction as an ostrich working within the savanna in the present day, then we are able to assume hen legs stood the take a look at of time – a great instance of evolutionary choice.
Swish, elegant, highly effective – flightless birds just like the ostrich are a mechanical marvel. Ostriches, a few of which weigh over 100kg, run via the savanna at as much as 55km/h. The ostrich’s excellent locomotor efficiency is considered enabled by the animal’s leg construction. Not like people, birds fold their toes again when pulling their legs up in direction of their our bodies. Why do the animals do that? Why is that this foot motion sample energy-efficient for strolling and working? And may the hen’s leg construction with all its bones, muscle tissues, and tendons be transferred to strolling robots?
Alexander Badri-Spröwitz has spent greater than 5 years on these questions. On the Max Planck Institute for Clever Methods (MPI-IS), he leads the Dynamic Locomotion Group. His group works on the interface between biology and robotics within the discipline of biomechanics and neurocontrol. The dynamic locomotion of animals and robots is the group’s fundamental focus.
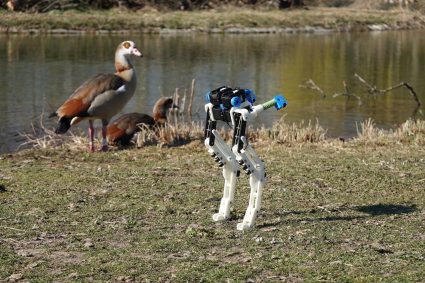
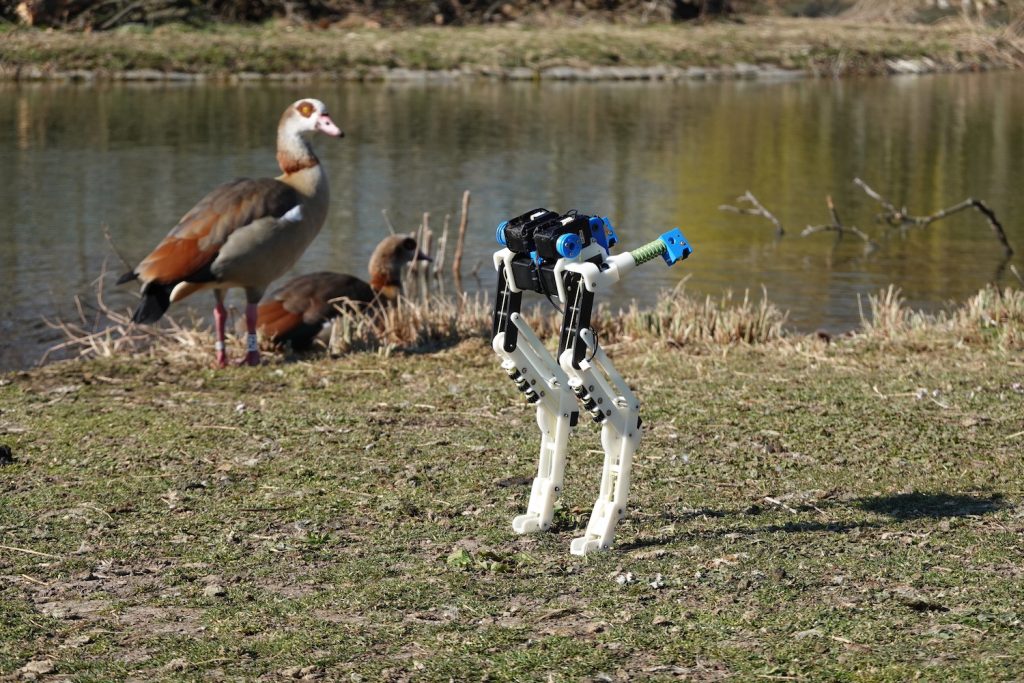
Collectively together with his doctoral pupil Alborz Aghamaleki Sarvestani, Badri-Spröwitz has constructed a robotic leg that, like its pure mannequin, is energy-efficient: BirdBot wants fewer motors than different machines and will, theoretically, scale to massive dimension. On March sixteenth, Badri-Spröwitz, Aghamaleki Sarvestani, the roboticist Metin Sitti, a director at MPI-IS, and biology professor Monica A. Daley of the College of California, Irvine, printed their analysis within the famend journal Science Robotics.
Compliant spring-tendon community made from muscle tissues and tendons
When strolling, people pull their toes up and bend their knees, however toes and toes level ahead virtually unchanged. It’s recognized that Birds are completely different — within the swing part, they fold their toes backward. However what’s the operate of this movement? Badri-Spröwitz and his group attribute this motion to a mechanical coupling. “It’s not the nervous system, it’s not electrical impulses, it’s not muscle exercise,” Badri-Spröwitz explains. “We hypothesized a brand new operate of the foot-leg coupling via a community of muscle tissues and tendons that extends throughout a number of joints”. These multi-joint muscle-tendon coordinate foot folding within the swing part. In our robotic, we now have carried out the coupled mechanics within the leg and foot, which allows energy-efficient and strong robotic strolling. Our outcomes demonstrating this mechanism in a robotic lead us to imagine that related effectivity advantages additionally maintain true for birds,” he explains.
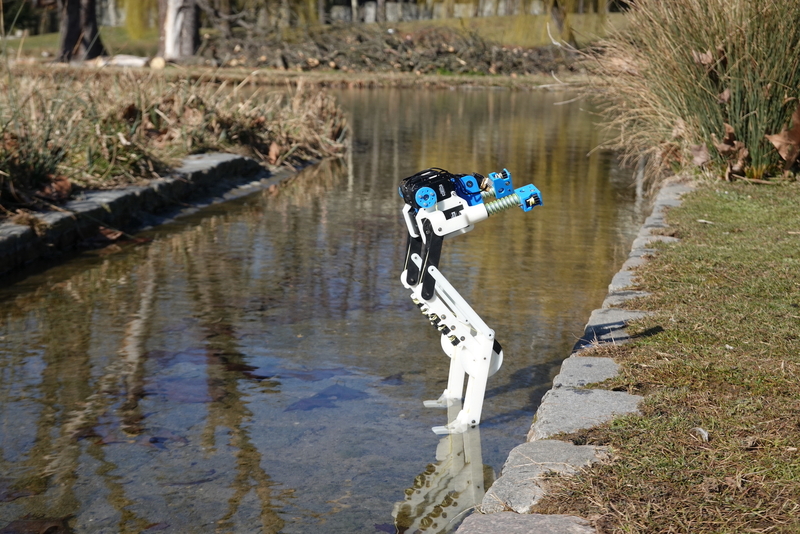
The coupling of the leg and foot joints and the forces and actions concerned may very well be the explanation why a big animal like an ostrich cannot solely run quick but in addition stand with out tiring, the researchers speculate. An individual weighing over 100kg also can stand nicely and for a very long time, however solely with the knees ‘locked’ in an prolonged place. If the individual had been to squat barely, it turns into strenuous after a couple of minutes. The hen, nevertheless, doesn’t appear to thoughts its bent leg construction; many birds even stand upright whereas sleeping. A robotic hen’s leg ought to have the ability to do the identical: no motor energy must be wanted to maintain the construction standing upright.
Robotic walks on treadmill
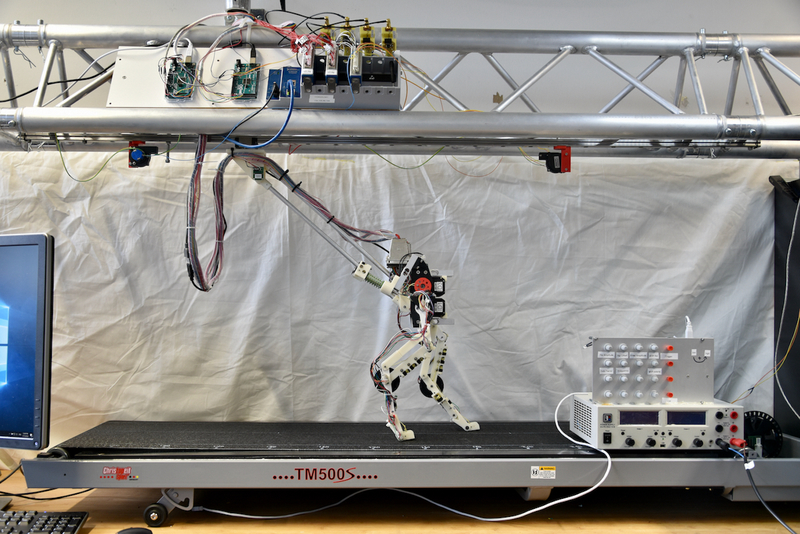
To check their speculation, the researchers constructed a robotic leg modeled after the leg of a flightless hen. They constructed their synthetic hen leg in order that its foot options no motor, however as an alternative a joint outfitted with a spring and cable mechanism. The foot is mechanically coupled to the remainder of the leg’s joints via cables and pulleys. Every leg incorporates solely two motors— the hip joints motor, which swings the leg backwards and forwards, and a small motor that flexes the knee joint to tug the leg up. After meeting, the researchers walked BirdBot on a treadmill to watch the robotic’s foot folding and unfolding. “The foot and leg joints don’t want actuation within the stance part,” says Aghamaleki Sarvestani. “Springs energy these joints, and the multi-joint spring-tendon mechanism coordinates joint actions. When the leg is pulled into swing part, the foot disengages the leg’s spring – or the muscle-tendon spring, as we imagine it occurs in animals,” Badri-Spröwitz provides. A video exhibits BirdBot strolling within the analysis group’s laboratory.
Zero effort when standing, and when flexing the leg and knee
When standing, the leg expends zero power. “Beforehand, our robots needed to work in opposition to the spring or with a motor both when standing or when pulling the leg up, to stop the leg from colliding with the bottom throughout leg swing. This power enter will not be mandatory in BirdBot’s legs,” says Badri-Spröwitz and Aghamaleki Sarvestani provides: “Total, the brand new robotic requires a mere quarter of the power of its predecessor.”
The treadmill is now switched again on, the robotic begins working, and with every leg swing, the foot disengages the leg’s spring. To disengage, the massive foot motion slacks the cable and the remaining leg joints swing loosely. This transition of states, between standing and leg swing, is supplied in most robots by a motor on the joint. And a sensor sends a sign to a controller, which turns the robotic’s motors on and off. “Beforehand, motors had been switched relying on whether or not the leg was within the swing or stance part. Now the foot takes over this operate within the strolling machine, mechanically switching between stance and swing. We solely want one motor on the hip joint and one motor to bend the knee within the swing part. We depart leg spring engagement and disengagement to the bird-inspired mechanics. That is strong, quick, and energy-efficient,” says Badri-Spröwitz.
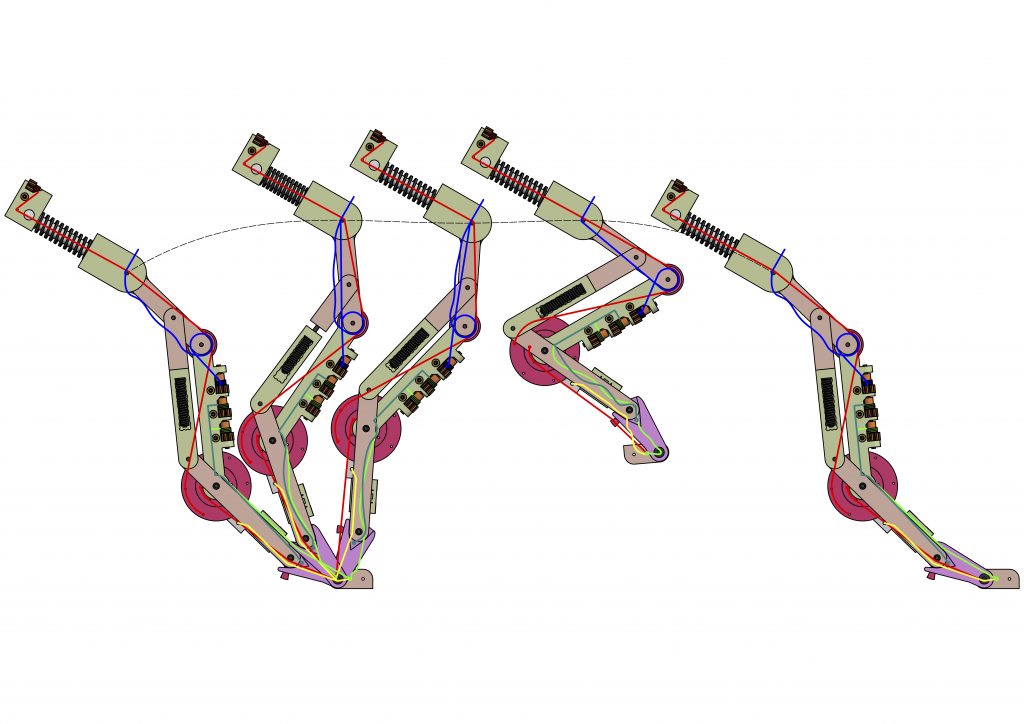
Movement sequence of BirdBot’s leg; left is touch-down, then stance (the three first snapshots on the left), then mid-swing with the leg’s attribute leg flexing posture, and again to touch-down on the correct. Springs and spring-tendons are proven on prime.
Monica Daley noticed in a number of of her earlier biology research that the hen’s leg construction not solely saves power throughout strolling and standing however can also be tailored by nature in order that the animal hardly stumbles and injures itself. In experiments with guineafowls working over hidden potholes, she quantified the birds’ exceptional locomotion robustness. A morphological intelligence is constructed into the system that enables the animal to behave shortly – with out having to consider it. Daley had proven that the animals management their legs throughout locomotion not solely with the assistance of the nervous system. If an impediment unexpectedly lies in the best way, it’s not all the time the animal’s sense of contact or sight that comes into play.
“The construction with its multi-jointed muscle-tendons and its distinctive foot motion can clarify why even heavy, massive birds run so shortly, robustly, and energy-efficient. If I assume that all the things within the hen relies on sensing and motion, and the animal steps onto an surprising impediment, the animal won’t have the ability to react shortly sufficient. Notion and sensing, even the transmission of the stimuli, and the response price time,” Daley says.
But Daley’s work on working birds over 20 years demonstrates that birds reply extra quickly than the nervous system permits, indicating mechanical contributions to regulate. Now that the group developed BirdBot, which is a bodily mannequin that instantly demonstrates how these mechanisms work, all of it makes extra sense: the leg switches mechanically if there’s a bump within the floor. The change occurs instantly and with out time delay. Like birds, the robotic options excessive locomotion robustness.
Whether or not it’s on the size of a Tyrannosaurus Rex or a small quail, or a small or massive robotic leg. Theoretically, meter-high legs can now be carried out to hold robots with the burden of a number of tons, that stroll round with little energy enter.
The data gained via BirdBot developed on the Dynamic Locomotion Group and the College of California, Irvine, results in new insights about animals, that are tailored by evolution. Robots enable testing and typically confirming hypotheses from Biology, and advancing each fields.
tags: bio-inspired, c-Analysis-Innovation
Max Planck Institute for Clever Methods
‘s aim is to research and perceive the organizing rules of clever methods and the underlying perception-action-learning loop.
[ad_2]

