


[ad_1]
People could also be one of many largest roadblocks conserving absolutely autonomous automobiles off metropolis streets.
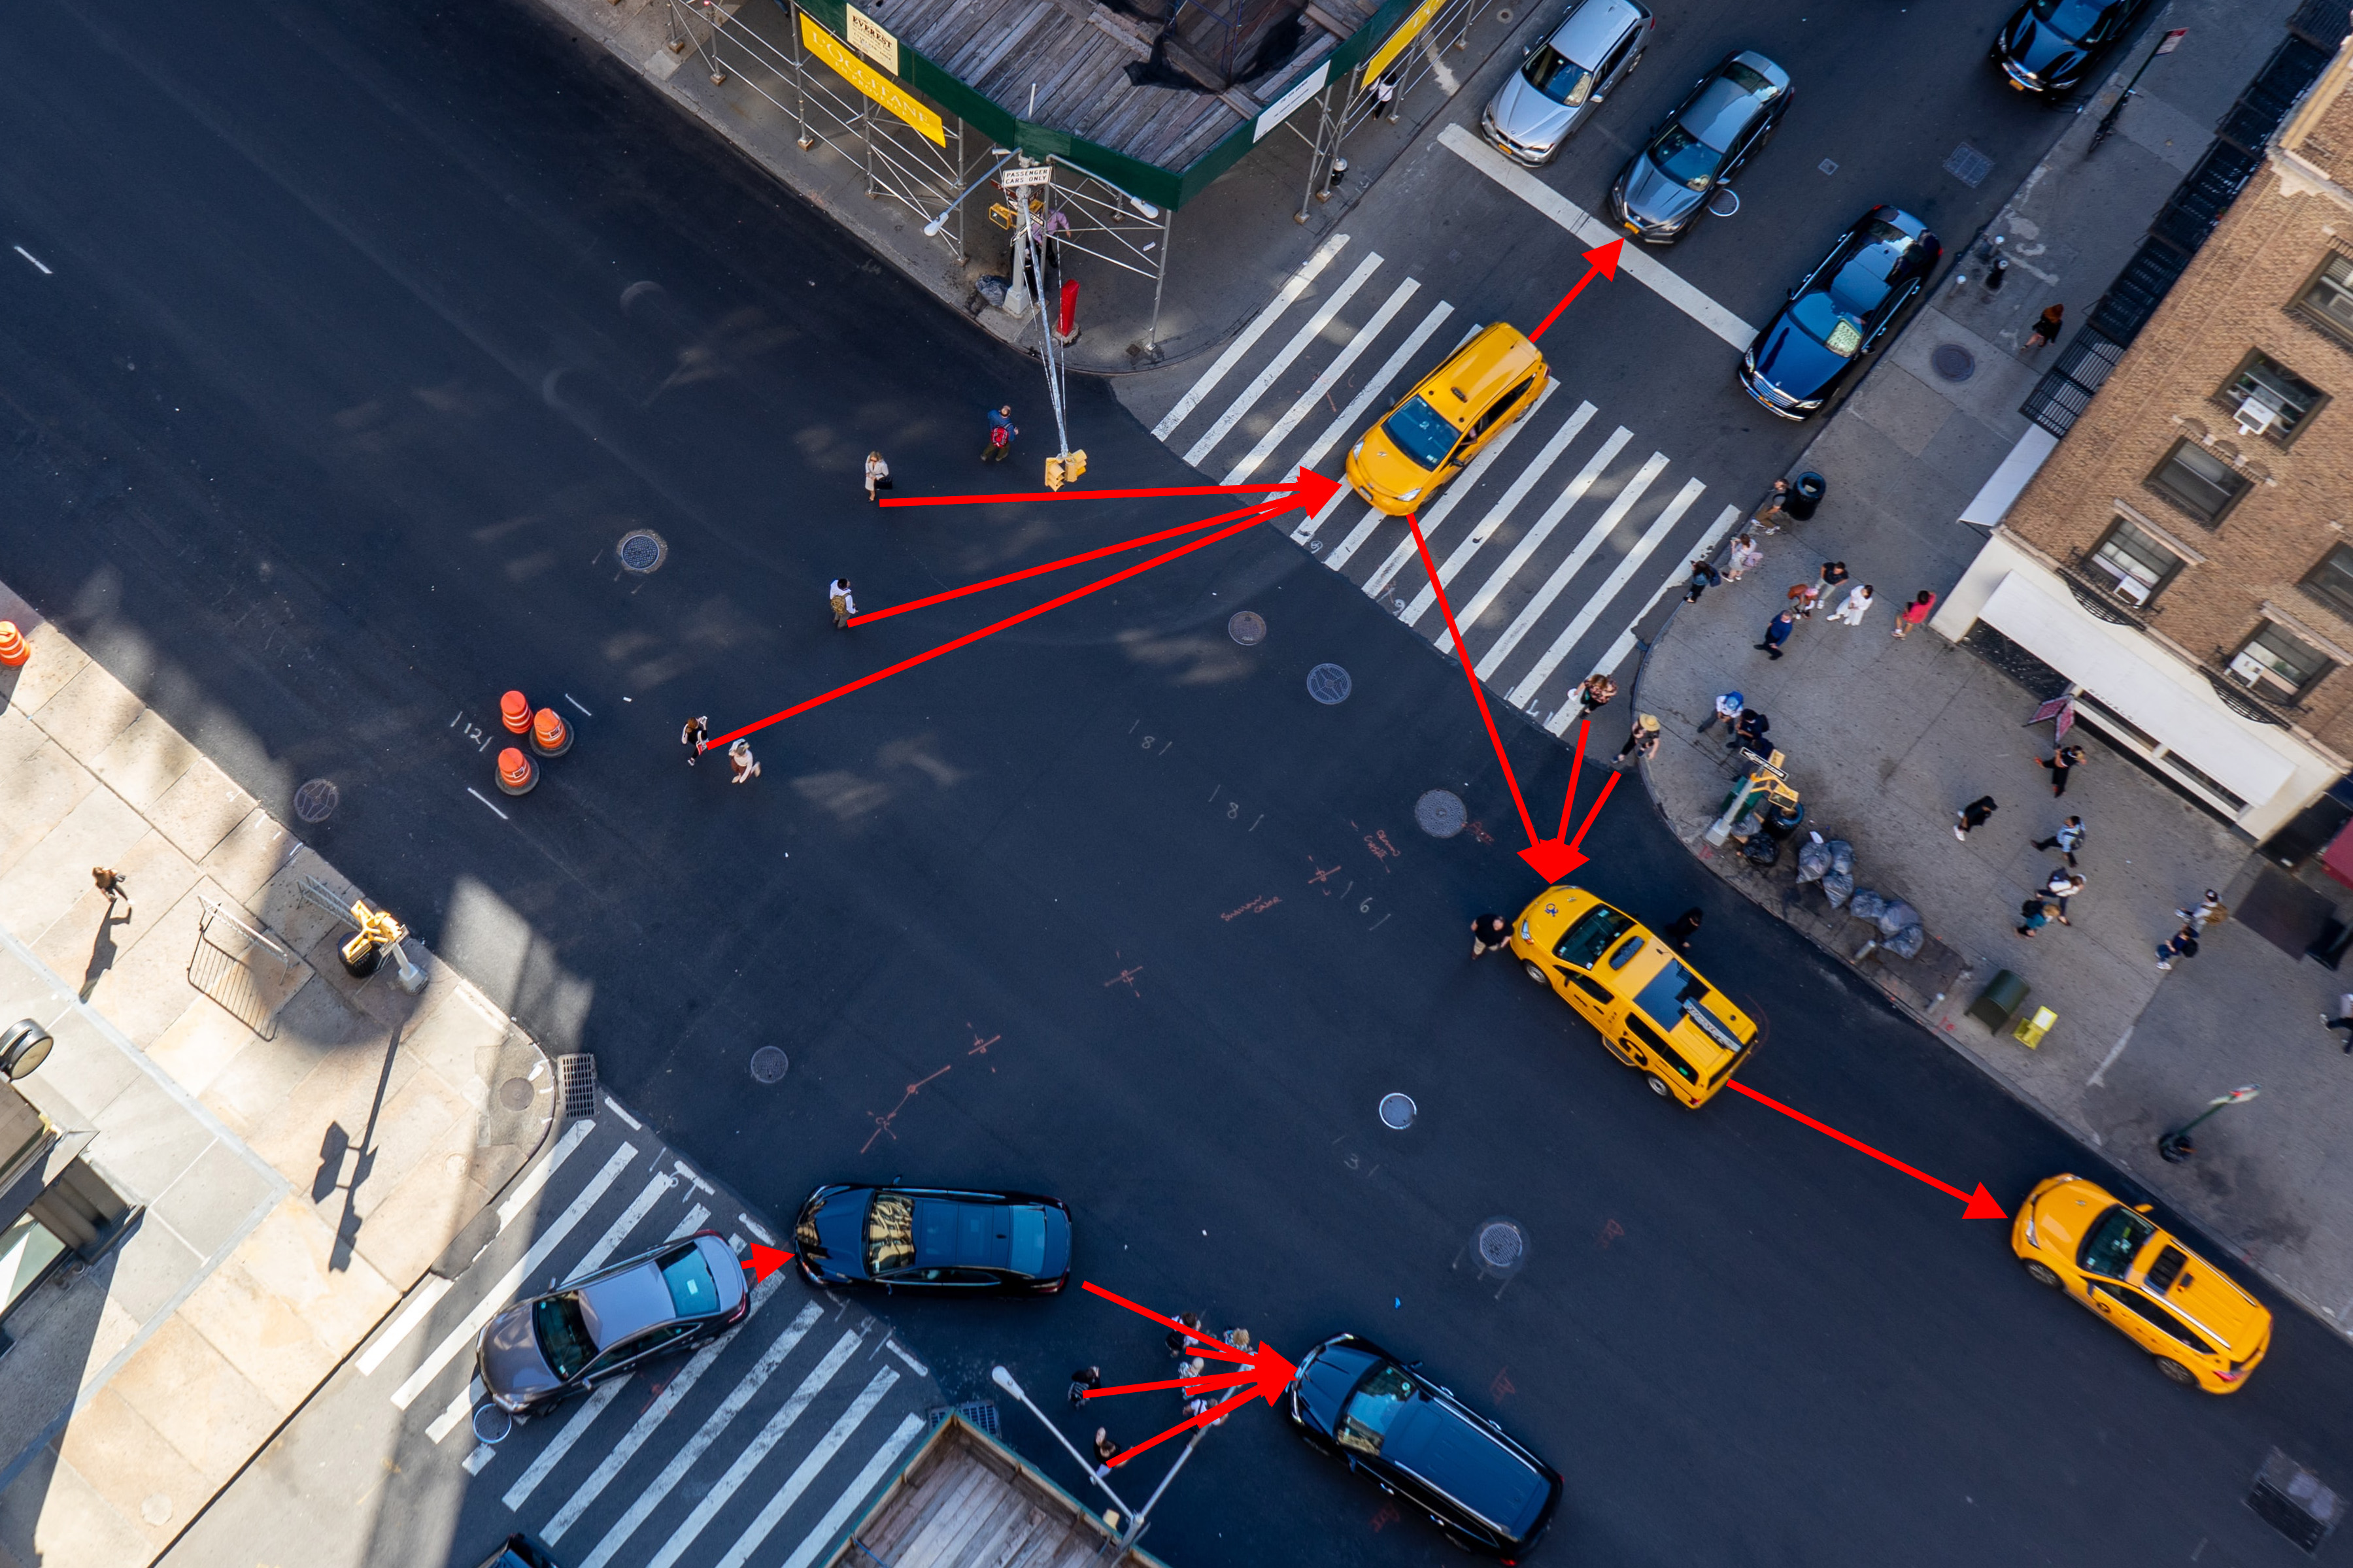
If a robotic goes to navigate a car safely via downtown Boston, it should be capable to predict what close by drivers, cyclists, and pedestrians are going to do subsequent.
Conduct prediction is a tricky downside, nonetheless, and present synthetic intelligence options are both too simplistic (they could assume pedestrians all the time stroll in a straight line), too conservative (to keep away from pedestrians, the robotic simply leaves the automobile in park), or can solely forecast the subsequent strikes of 1 agent (roads sometimes carry many customers without delay.)
MIT researchers have devised a deceptively easy answer to this difficult problem. They break a multiagent habits prediction downside into smaller items and sort out every one individually, so a pc can clear up this complicated process in real-time.
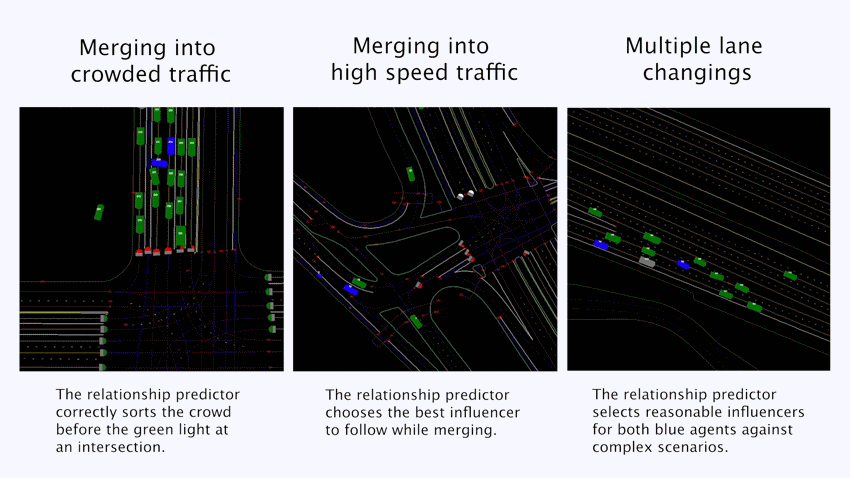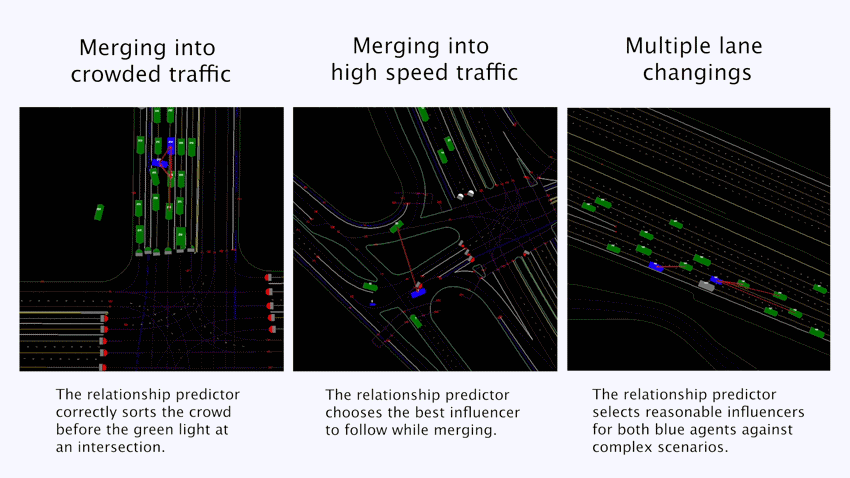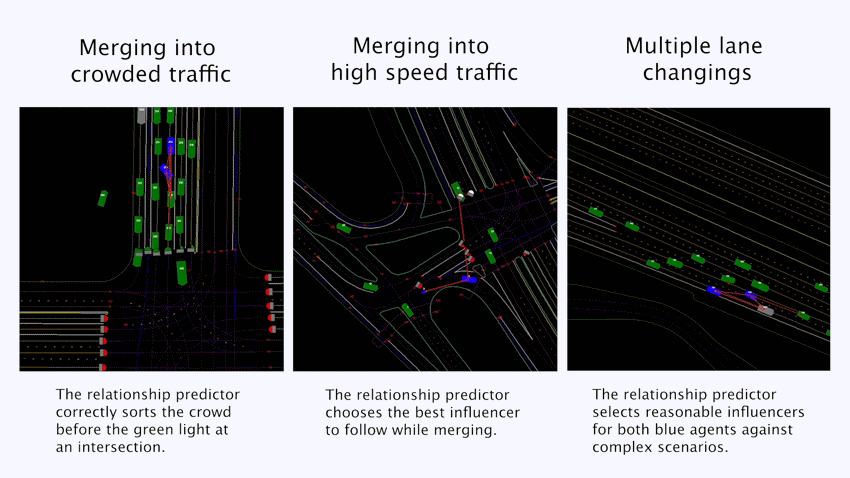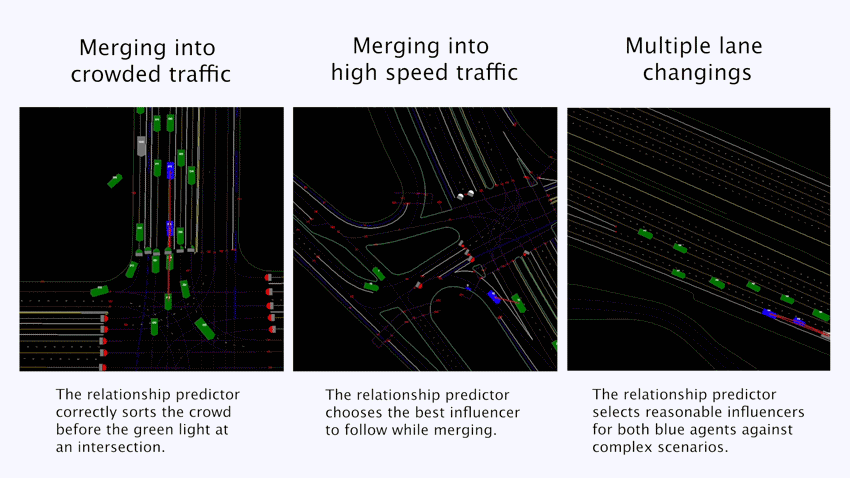
Their behavior-prediction framework first guesses the relationships between two street customers — which automobile, bike owner, or pedestrian has the precise of method, and which agent will yield — and makes use of these relationships to foretell future trajectories for a number of brokers.
These estimated trajectories have been extra correct than these from different machine-learning fashions, in comparison with actual visitors stream in an infinite dataset compiled by autonomous driving firm Waymo. The MIT approach even outperformed Waymo’s not too long ago printed mannequin. And since the researchers broke the issue into less complicated items, their approach used much less reminiscence.
“This can be a very intuitive concept, however nobody has absolutely explored it earlier than, and it really works fairly effectively. The simplicity is unquestionably a plus. We’re evaluating our mannequin with different state-of-the-art fashions within the subject, together with the one from Waymo, the main firm on this space, and our mannequin achieves prime efficiency on this difficult benchmark. This has loads of potential for the long run,” says co-lead creator Xin “Cyrus” Huang, a graduate scholar within the Division of Aeronautics and Astronautics and a analysis assistant within the lab of Brian Williams, professor of aeronautics and astronautics and a member of the Laptop Science and Synthetic Intelligence Laboratory (CSAIL).
Becoming a member of Huang and Williams on the paper are three researchers from Tsinghua College in China: co-lead creator Qiao Solar, a analysis assistant; Junru Gu, a graduate scholar; and senior creator Dangle Zhao PhD ’19, an assistant professor. The analysis might be introduced on the Convention on Laptop Imaginative and prescient and Sample Recognition.
A number of small fashions
The researchers’ machine-learning technique, referred to as M2I, takes two inputs: previous trajectories of the vehicles, cyclists, and pedestrians interacting in a visitors setting equivalent to a four-way intersection, and a map with road areas, lane configurations, and many others.
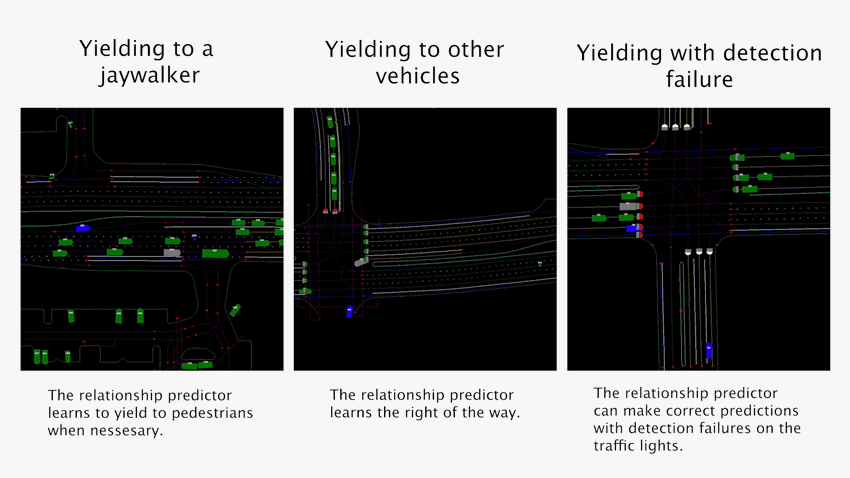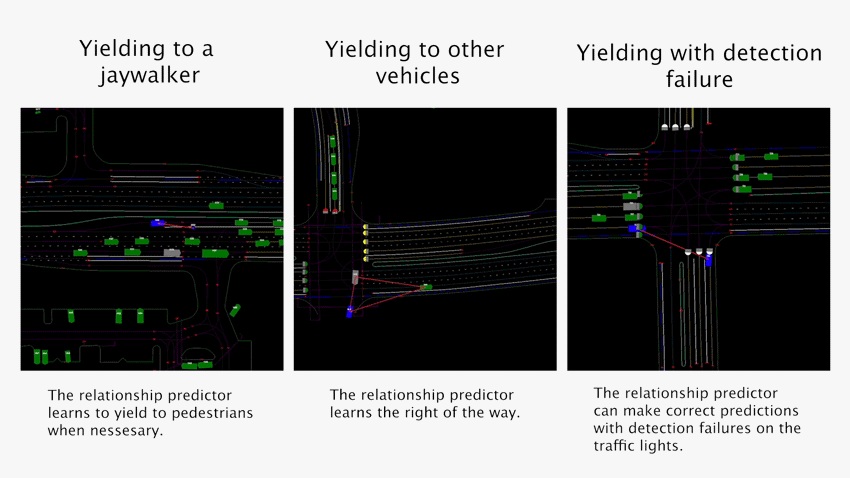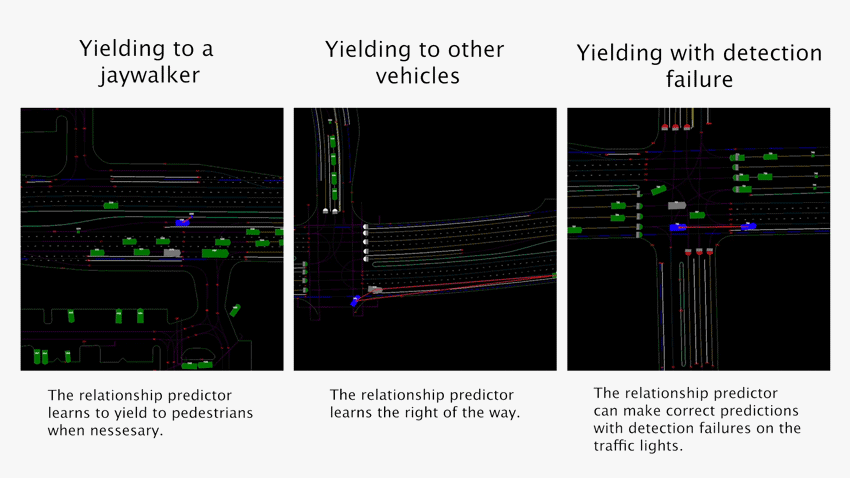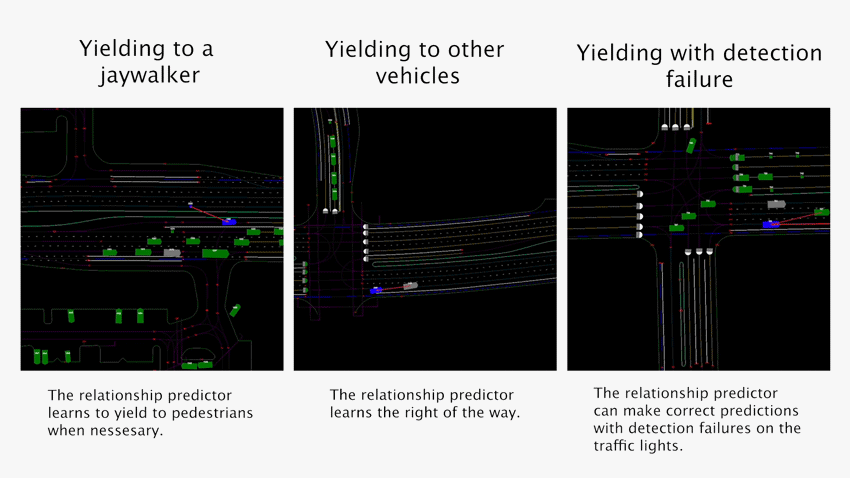
Utilizing this data, a relation predictor infers which of two brokers has the precise of method first, classifying one as a passer and one as a yielder. Then a prediction mannequin, generally known as a marginal predictor, guesses the trajectory for the passing agent, since this agent behaves independently.
A second prediction mannequin, generally known as a conditional predictor, then guesses what the yielding agent will do based mostly on the actions of the passing agent. The system predicts plenty of completely different trajectories for the yielder and passer, computes the chance of every one individually, after which selects the six joint outcomes with the very best probability of occurring.
M2I outputs a prediction of how these brokers will transfer via visitors for the subsequent eight seconds. In a single instance, their technique brought on a car to decelerate so a pedestrian may cross the road, then velocity up once they cleared the intersection. In one other instance, the car waited till a number of vehicles had handed earlier than turning from a aspect road onto a busy, fundamental street.
Whereas this preliminary analysis focuses on interactions between two brokers, M2I may infer relationships amongst many brokers after which guess their trajectories by linking a number of marginal and conditional predictors.
Actual-world driving exams
The researchers skilled the fashions utilizing the Waymo Open Movement Dataset, which comprises hundreds of thousands of actual visitors scenes involving automobiles, pedestrians, and cyclists recorded by lidar (mild detection and ranging) sensors and cameras mounted on the corporate’s autonomous automobiles. They centered particularly on instances with a number of brokers.
To find out accuracy, they in contrast every technique’s six prediction samples, weighted by their confidence ranges, to the precise trajectories adopted by the vehicles, cyclists, and pedestrians in a scene. Their technique was essentially the most correct. It additionally outperformed the baseline fashions on a metric generally known as overlap charge; if two trajectories overlap, that signifies a collision. M2I had the bottom overlap charge.
“Fairly than simply constructing a extra complicated mannequin to unravel this downside, we took an strategy that’s extra like how a human thinks once they cause about interactions with others. A human doesn’t cause about all tons of of mixtures of future behaviors. We make choices fairly quick,” Huang says.
One other benefit of M2I is that, as a result of it breaks the issue down into smaller items, it’s simpler for a person to grasp the mannequin’s choice making. In the long term, that might assist customers put extra belief in autonomous automobiles, says Huang.
However the framework can’t account for instances the place two brokers are mutually influencing one another, like when two automobiles every nudge ahead at a four-way cease as a result of the drivers aren’t certain who needs to be yielding.
They plan to deal with this limitation in future work. In addition they need to use their technique to simulate sensible interactions between street customers, which might be used to confirm planning algorithms for self-driving vehicles or create big quantities of artificial driving knowledge to enhance mannequin efficiency.
“Predicting future trajectories of a number of, interacting brokers is under-explored and intensely difficult for enabling full autonomy in complicated scenes. M2I offers a extremely promising prediction technique with the relation predictor to discriminate brokers predicted marginally or conditionally which considerably simplifies the issue,” wrote Masayoshi Tomizuka, the Cheryl and John Neerhout, Jr. Distinguished Professor of Mechanical Engineering at College of California at Berkeley and Wei Zhan, an assistant skilled researcher, in an e mail. “The prediction mannequin can seize the inherent relation and interactions of the brokers to realize the state-of-the-art efficiency.” The 2 colleagues weren’t concerned within the analysis.
This analysis is supported, partly, by the Qualcomm Innovation Fellowship. Toyota Analysis Institute additionally offered funds to assist this work.
[ad_2]

