



[ad_1]
Visitor Article by Robo-dyne
Because of the latest improvements in electronics and mechatronics, using cell robots and manipulators is changing into standard largely in sensible factories the place robotic platforms are used to maneuver heavy hundreds and for the storage of products.
One of many questions that come up when creating a brand new cell robotic is: steady tracks or wheels? When implementing a brand new industrial robotics utility, it may be very troublesome to appropriately select between wheels and tracks while you construct a robotic as a result of every locomotion system gives totally different performances and outputs. Crucial options to think about when you must design a locomotion system are the traction, the driving system, for instance, Ackermann or skid-steering, the utmost floor strain and the suspension system.
Whether it is vital to attenuate the bottom strain, then it’s vital to decide on an answer based mostly on tracks since they’re nicely appropriate for smooth surfaces. On the opposite facet, wheels have a big benefit in steering in comparison with tracks and this may be translated into manoeuvrability for the wheels. Robo-dyne is a robotics firm that gives tracked and wheeled robots that may be personalized relying on the ultimate necessities; that is significantly helpful for all that corporations that must develop high-level purposes based mostly on a cell robotic platform and don’t will to take a position time and money to construct the cell base as a result of they intention to concentrate on the ultimate utility.
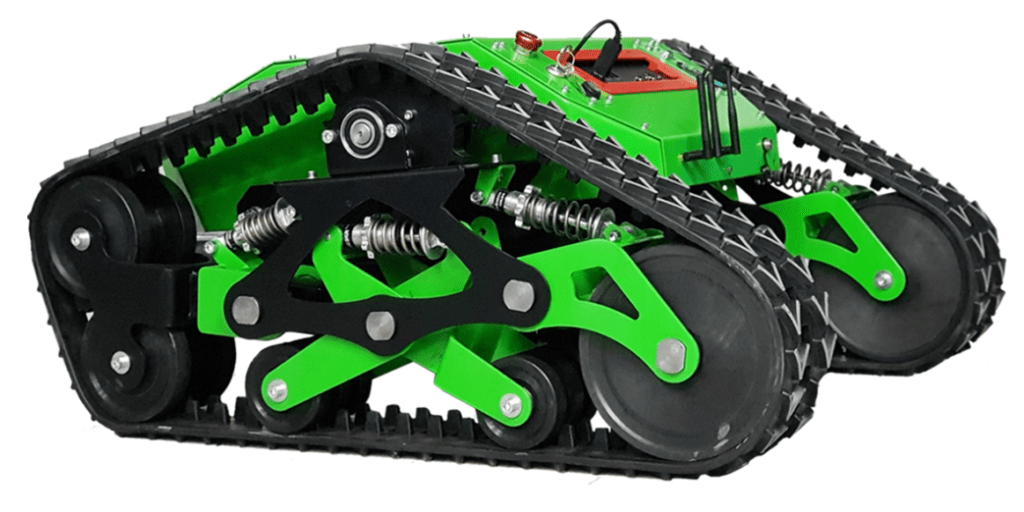
Robo-dyne designed MaXXII-S which is the primary electrical cell robotic with skid-steering and rubber tracks powered by AGM Batteries and in a position to make use of an progressive undercarriage configuration which incorporates a big rear wheel and a few two smaller entrance idle wheels pointing ahead. This configuration permits the robotic to have the ability to maintain its stability when extra instruments, i.e., garden mowers unit, weed cutter, rotary hoes, are mounted on its rear facet and it could possibly additionally overcome obstacles better than the ⅔ of the diameter of the rear wheel for the reason that higher entrance wheel leans on it offering space for additional grip. MaXXII-S is open supply and runs with ROS and C++ libraries in an effort to help researchers all around the world to develop their industrial purposes.
The middle idle wheels present a greater strain distribution on the bottom. A passive suspension system is used to attenuate the vibrations over the principle body brought on by the tracks-terrain interactions. Particularly, MaXXII-S adopts a set of three shock absorbers with preload adjustment along with the chance to alter the elastic coefficient in an effort to higher adapt the system configuration relying on the terrain options. This electrical skid-steering tracked cell robotic and its undercarriage is already out there on the market discovering use in an unlimited vary of agricultural purposes, resembling plant monitoring or weed reducing, and likewise for industrial use to maneuver items in warehouses with uneven floor as additionally reported on the producer’s official web site robo-dyne.com.
Ähnliche Beiträge
[ad_2]

