



[ad_1]
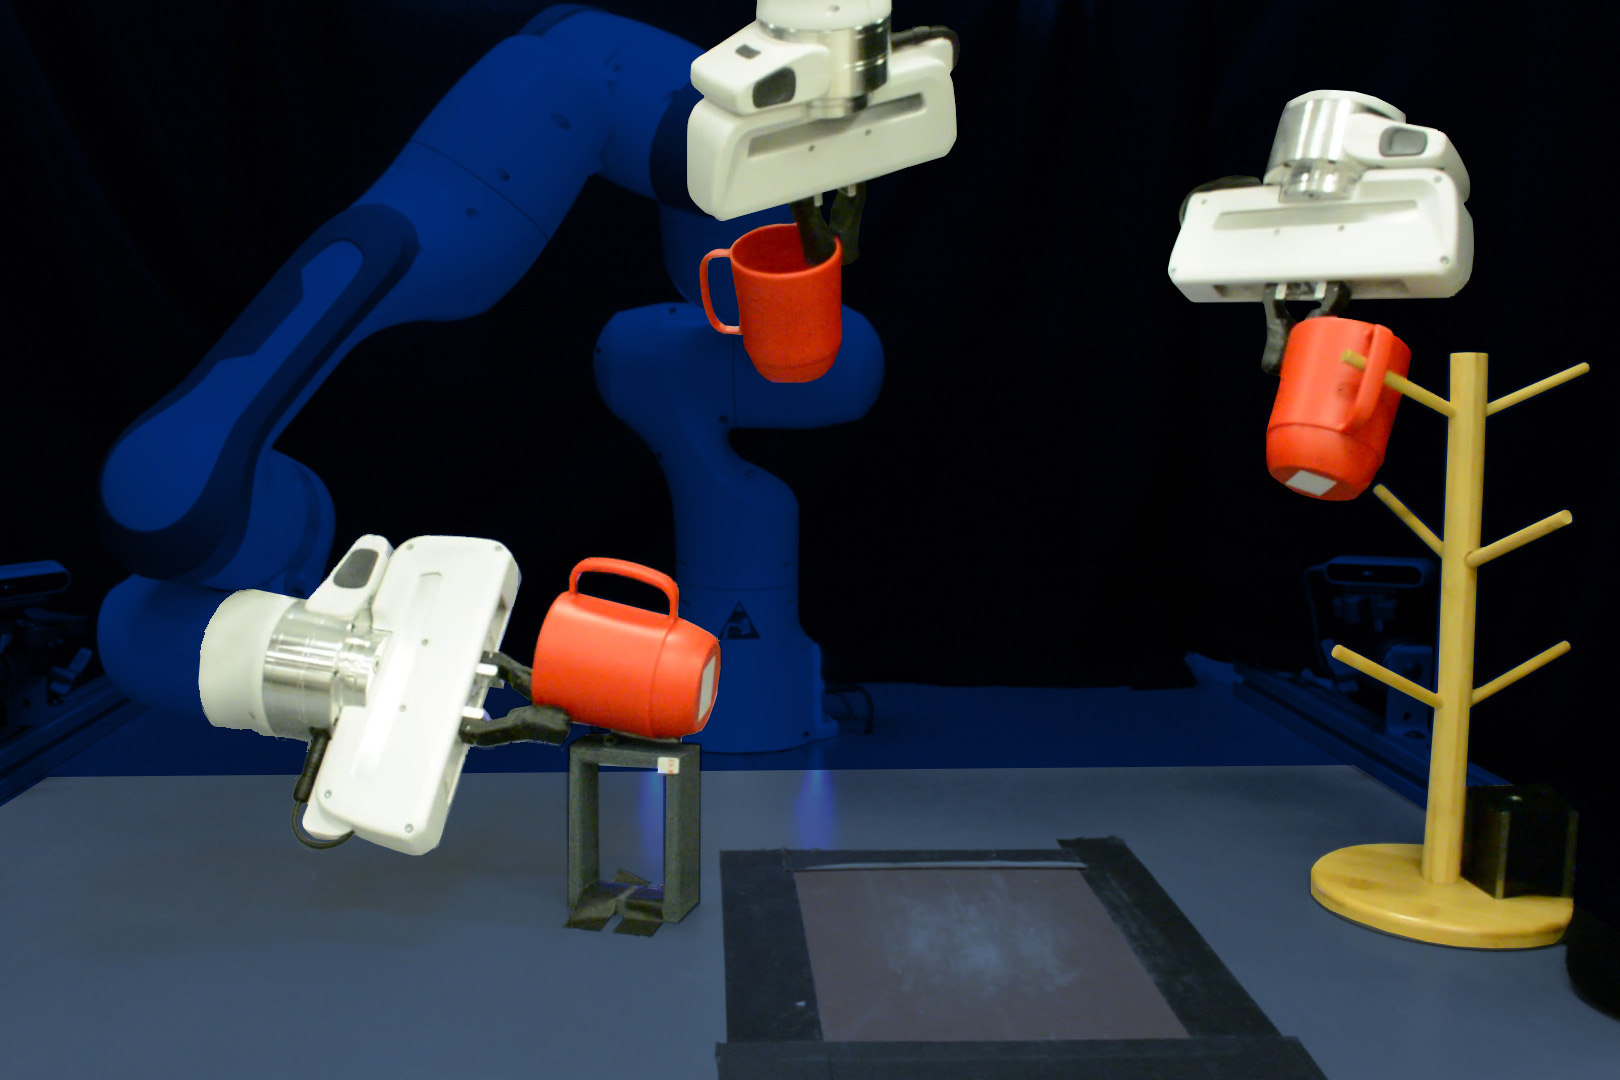
With e-commerce orders pouring in, a warehouse robotic picks mugs off a shelf and locations them into containers for transport. Every thing is buzzing alongside, till the warehouse processes a change and the robotic should now grasp taller, narrower mugs which might be saved the other way up.
Reprogramming that robotic entails hand-labeling 1000’s of photographs that present it how one can grasp these new mugs, then coaching the system another time.
However a brand new method developed by MIT researchers would require solely a handful of human demonstrations to reprogram the robotic. This machine-learning methodology allows a robotic to choose up and place never-before-seen objects which might be in random poses it has by no means encountered. Inside 10 to fifteen minutes, the robotic can be able to carry out a brand new pick-and-place activity.
The method makes use of a neural community particularly designed to reconstruct the shapes of 3D objects. With just some demonstrations, the system makes use of what the neural community has discovered about 3D geometry to understand new objects which might be just like these within the demos.
In simulations and utilizing an actual robotic arm, the researchers present that their system can successfully manipulate never-before-seen mugs, bowls, and bottles, organized in random poses, utilizing solely 10 demonstrations to show the robotic.
“Our main contribution is the overall skill to far more effectively present new abilities to robots that must function in additional unstructured environments the place there could possibly be numerous variability. The idea of generalization by development is an enchanting functionality as a result of this downside is usually a lot more durable,” says Anthony Simeonov, a graduate pupil in electrical engineering and pc science (EECS) and co-lead creator of the paper.
Simeonov wrote the paper with co-lead creator Yilun Du, an EECS graduate pupil; Andrea Tagliasacchi, a employees analysis scientist at Google Mind; Joshua B. Tenenbaum, the Paul E. Newton Profession Growth Professor of Cognitive Science and Computation within the Division of Mind and Cognitive Sciences and a member of the Pc Science and Synthetic Intelligence Laboratory (CSAIL); Alberto Rodriguez, the Class of 1957 Affiliate Professor within the Division of Mechanical Engineering; and senior authors Pulkit Agrawal, a professor in CSAIL, and Vincent Sitzmann, an incoming assistant professor in EECS. The analysis might be introduced on the Worldwide Convention on Robotics and Automation.
Greedy geometry
A robotic could also be educated to choose up a selected merchandise, but when that object is mendacity on its aspect (maybe it fell over), the robotic sees this as a totally new state of affairs. That is one motive it’s so arduous for machine-learning methods to generalize to new object orientations.
To beat this problem, the researchers created a brand new sort of neural community mannequin, a Neural Descriptor Discipline (NDF), that learns the 3D geometry of a category of things. The mannequin computes the geometric illustration for a selected merchandise utilizing a 3D level cloud, which is a set of information factors or coordinates in three dimensions. The information factors may be obtained from a depth digital camera that gives data on the space between the thing and a viewpoint. Whereas the community was educated in simulation on a big dataset of artificial 3D shapes, it may be straight utilized to things in the true world.
The staff designed the NDF with a property referred to as equivariance. With this property, if the mannequin is proven a picture of an upright mug, after which proven a picture of the identical mug on its aspect, it understands that the second mug is similar object, simply rotated.
“This equivariance is what permits us to far more successfully deal with instances the place the thing you observe is in some arbitrary orientation,” Simeonov says.
Because the NDF learns to reconstruct shapes of comparable objects, it additionally learns to affiliate associated elements of these objects. As an example, it learns that the handles of mugs are comparable, even when some mugs are taller or wider than others, or have smaller or longer handles.
“In case you wished to do that with one other strategy, you’d must hand-label all of the elements. As a substitute, our strategy routinely discovers these elements from the form reconstruction,” Du says.
The researchers use this educated NDF mannequin to show a robotic a brand new ability with only some bodily examples. They transfer the hand of the robotic onto the a part of an object they need it to grip, just like the rim of a bowl or the deal with of a mug, and document the places of the fingertips.
As a result of the NDF has discovered a lot about 3D geometry and how one can reconstruct shapes, it could possibly infer the construction of a brand new form, which allows the system to switch the demonstrations to new objects in arbitrary poses, Du explains.
Selecting a winner
They examined their mannequin in simulations and on an actual robotic arm utilizing mugs, bowls, and bottles as objects. Their methodology had a hit charge of 85 p.c on pick-and-place duties with new objects in new orientations, whereas one of the best baseline was solely capable of obtain a hit charge of 45 p.c. Success means greedy a brand new object and putting it on a goal location, like hanging mugs on a rack.
Many baselines use 2D picture data relatively than 3D geometry, which makes it harder for these strategies to combine equivariance. That is one motive the NDF method carried out so a lot better.
Whereas the researchers had been proud of its efficiency, their methodology solely works for the actual object class on which it’s educated. A robotic taught to choose up mugs gained’t be capable of decide up containers or headphones, since these objects have geometric options which might be too completely different than what the community was educated on.
“Sooner or later, scaling it as much as many classes or fully letting go of the notion of class altogether can be superb,” Simeonov says.
In addition they plan to adapt the system for nonrigid objects and, in the long term, allow the system to carry out pick-and-place duties when the goal space modifications.
This work is supported, partly, by the Protection Superior Analysis Initiatives Company, the Singapore Protection Science and Know-how Company, and the Nationwide Science Basis.
[ad_2]

