


[ad_1]
|
Hearken to this text  |
Researchers at MIT’s Pc Science and Synthetic Intelligence Laboratory have launched an open-source simulation engine that may assemble photorealistic environments to coach and check autonomous automobiles.
Instructing neural networks to drive automobiles autonomously requires a considerable amount of information. A lot of this information might be troublesome to safe in the actual world utilizing actual automobiles. Researchers can’t merely crash a automobile to show a neural community to not crash a automobile, in order that they depend on simulated environments for this type of information. That’s the place simulated coaching environments, like CSAIL’s VISTA 2.0 is available in.
VISTA 2.0, an up to date model of the staff’s earlier mannequin VISTA, is a data-driven simulation surroundings that was photorealistically rendered from real-world information. It’s capable of simulate advanced sensor sorts and interactive eventualities and intersections at scale.
“At this time, solely corporations have software program like the kind of simulation environments and capabilities of VISTA 2.0, and this software program is proprietary. With this launch, the analysis neighborhood can have entry to a robust new device for accelerating the analysis and growth of adaptive strong management for autonomous driving,” MIT Professor and CSAIL Director Daniela Rus, senior creator on a paper in regards to the analysis, stated.
VISTA 2.0’s photorealistic surroundings displays a current pattern within the autonomous automobile trade. Builders are shifting away from utilizing human-designed simulation environments and in the direction of utilizing ones constructed from real-world information.
These environments are interesting as a result of they permit for direct transfers to actuality. Nonetheless it may be troublesome to synthesize the richness and complexity of all of the sensors autonomous automobiles want. For instance, to copy LiDAR in these environments, researchers primarily have to generate new 3D level clouds with thousands and thousands of factors utilizing solely a sparse view of the world.
To get round this, the MIT staff projected information collected from the automobile right into a 3D house coming from the LiDAR information. They then let a brand new digital automobile drive round domestically from the place that authentic automobile was, and, with the assistance of neural networks, projected sensory data again into the body of view of the brand new digital automobile.
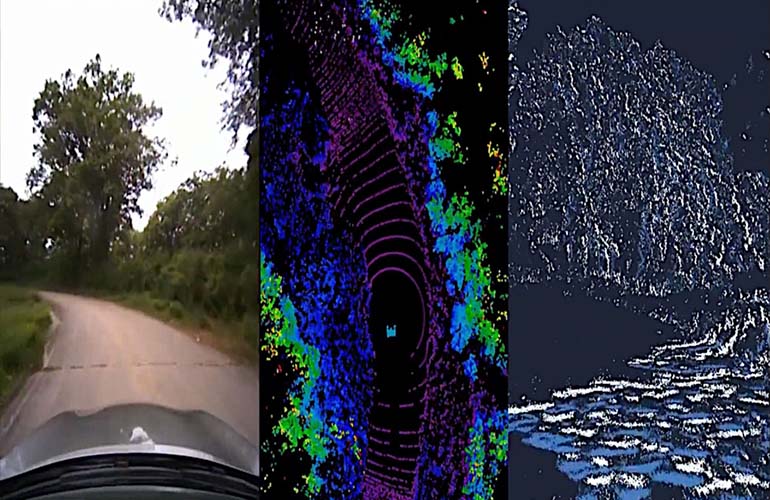
VISTA 2.0, can open-source simulation engine from MIT CSAIL, that may simulate environments for coaching self driving vehicles. | Supply: MIT CSAIL
The staff additionally simulated, in real-time, event-based cameras, which function at higher speeds than hundreds of occasions per second. With all of those sensors simulated, you’re capable of transfer automobiles round within the simulation, simulate various kinds of occasions, and drop in model new automobiles not a part of the unique information.
“This can be a huge leap in capabilities of data-driven simulation for autonomous automobiles, in addition to the rise of scale and skill to deal with higher driving complexity,” Alexander Amini, CSAIL PhD pupil and co-lead creator on two new papers, along with fellow PhD pupil Tsun-Hsuan Wang, stated. “VISTA 2.0 demonstrates the flexibility to simulate sensor information far past 2D RGB cameras, but additionally extraordinarily excessive dimensional 3D lidars with thousands and thousands of factors, irregularly timed event-based cameras, and even interactive and dynamic eventualities with different automobiles as nicely.”
MIT’s staff took a full-scale automobile out to check VISTA 2.0 in Devens, Massachusetts. The staff noticed a direct transferability of outcomes, with each failures and successes. Transferring ahead, CSAIL hopes to permit the neural community to grasp and reply to gestures from different drivers, like a wave, nod or blinker swap of acknowledgement.
Amini and Wang wrote the paper alongside Zhijian Liu, MIT CSAIL PhD pupil; Igor Gilitschenski, assistant professor in laptop science on the College of Toronto; Wilko Schwarting, AI analysis scientist and MIT CSAIL PhD ’20; Music Han, affiliate professor at MIT’s Division of Electrical Engineering and Pc Science; Sertac Karaman, affiliate professor of aeronautics and astronautics at MIT; and Daniela Rus, MIT professor and CSAIL director.
[ad_2]

