



[ad_1]
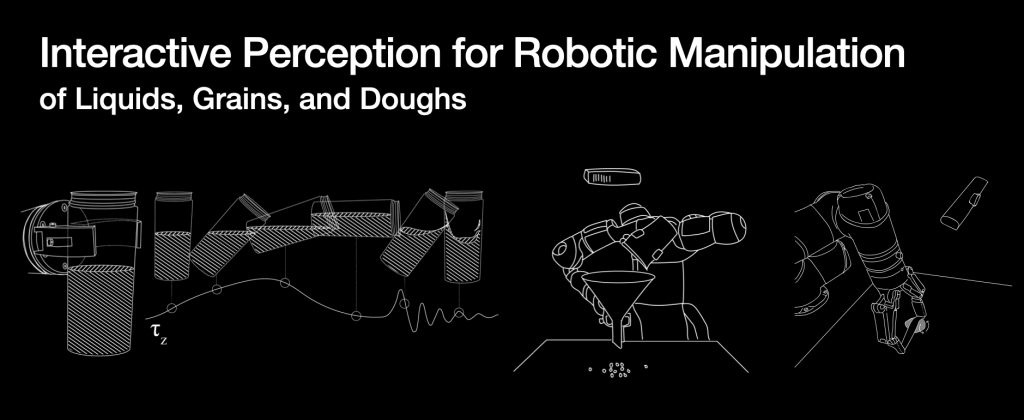
Dr. Carolyn Matl, Analysis Scientist at Toyota Analysis Institute, explains why Interactive Notion and delicate tactile sensors are essential for manipulating difficult objects comparable to liquids, grains, and dough. She additionally dives into “StRETcH” a Comfortable to Resistive Elastic Tactile Hand, a variable stiffness delicate tactile end-effector, offered by her analysis group.
Carolyn Matl
Carolyn Matl is a analysis scientist on the Toyota Analysis Institute, the place she works on robotic notion and manipulation with the Cellular Manipulation Group. She acquired her B.S.E in Electrical Engineering from Princeton College in 2016, and her Ph.D. in Electrical Engineering and Pc Sciences on the College of California, Berkeley in 2021. At Berkeley, she was awarded the NSF Graduate Analysis Fellowship and was suggested by Ruzena Bajcsy. Her dissertation work centered on creating and leveraging non-traditional sensors for robotic manipulation of difficult objects and substances like liquids and doughs.
Carolyn Matl’s Associated Analysis Movies
Hyperlinks
——————–transcript——————-
Episode 350 Toyota Analysis Institute on Interactive Notion
===
Shihan Lu: Hello, Dr. Matl, welcome to Robohub. Would you thoughts introducing your self?
Carolyn Matl: All proper. Uh, so hi there. Thanks a lot for having me on the podcast. I’m Carolyn Matl and I’m a analysis scientist on the Toyota analysis Institute the place I work with a extremely nice group of individuals on the cell manipulation workforce on enjoyable and difficult robotic notion and manipulation issues.
I just lately graduated from proper up the street. From UC Berkeley, the place I used to be suggested by the great regional by G and the place for my dissertation, I labored on interactive notion for robotic manipulation of various supplies, like liquid, grains, and doughs.
Shihan Lu: So what’s interactive notion?
Carolyn Matl: So in a nutshell, interactive notion is strictly what it feels like.
It’s notion that requires bodily interplay with the encircling surroundings and whether or not that is purposeful or not. This interplay is what in the end modifications the state of the surroundings, which then permits the actor. So this might be the robotic or a human to deduce one thing in regards to the surroundings that in any other case wouldn’t have been noticed as people.
You already know, we use interactive notion. On a regular basis to study in regards to the world round us. So actually, you is perhaps accustomed to the work of EJ and JJ Gibson who studied in depth, how people use bodily interplay to acquire extra correct representations of objects. So take for instance, once you’re on the grocery retailer, uh, and also you’re selecting out some issues.
You may frivolously press an orange for instance, to see if it’s overripe or, and I don’t know if that is scientifically confirmed, however you may even knock on a watermelon to then take heed to the ensuing vibrations, which some individuals inform me permits you to decide, whether or not it’s a juicy one round it or not. So, yeah, individuals use interactive notion on a regular basis to study in regards to the world.
And in robotics, we wish to equip robots with related perceptual intelligence.
Shihan Lu: Okay. So utilizing interactive notion is to use like, uh, energetic motion to the item and take a look at and take a look at that there’s a correspondent suggestions, after which utilizing this course of to raised perceive the item states. So, How is this useful for the manipulation duties?
Carolyn Matl: So once we consider conventional notion for robots, typically, what involves thoughts is pure laptop imaginative and prescient, the place the robotic is actually this floating head shifting round on the planet and gathering visible data. And to be clear, the wonderful developments in laptop imaginative and prescient have enabled robotics as a subject, uh, to make great developments.
And also you see this with the success in areas starting from automated automotive navigation, all the way in which to bin selecting robots and these robotic techniques are capable of seize a wealthy illustration of the state of the world by pictures alone, typically with none interplay, however as everyone knows, robots, not solely sense, however in addition they act on the world and thru this interplay, they will observe vital bodily properties of objects or the surroundings that might in any other case not be perceived.
So for instance, circling again to the fruits, observing an orange or statically weighing a watermelon won’t essentially let you know how ripe it’s, however as a substitute robots can benefit from this. That they’re not simply floating heads in area and use their actuators to prod and press the fruit. And so quoting a assessment article on interactive notion by Jeanette Bohg who was on this podcast.
And, together with many others on this subject, they wrote a assessment article on interactive notion, that claims that this interplay creates a novel sensory sign that might in any other case not be current.
So for instance, these alerts might be the way in which the fruit deforms beneath the utilized stress or the sounds that the watermelon makes when the robotic knocks on its rind and the identical assessment article additionally supplies an extra benefit of interactive notion, which is that the interpretation of the novel sign consequently turns into easier and extra strong.
So, for instance, it’s a lot easier and extra strong to discover a correspondence with the measured stiffness of a fruit and its ripeness than merely predicting rightness from the colour of the fruit. The motion of urgent the fruit and the ensuing alerts from that motion straight relate to the fabric property the robotic is considering observing.
Whereas when no motion is taken, the connection between the remark and inference is perhaps much less causal. So I do imagine that interactive notion is prime for robots to sort out difficult manipulation duties, particularly for the manipulation of deformable objects or advanced supplies.
whether or not the robotic is making an attempt to straight infer a bodily parameter, just like the coefficient of friction, or to study a dynamics perform, to symbolize a deformable object, interacting with the item is what in the end permits the robotic to look at parameters which can be related to the dynamics of that object.
Subsequently serving to the robotic attain a extra correct illustration or mannequin of the item. This subsequently helps the robotic predict the causal results of various interactions with an object, which then permits the robotic to plan a posh manipulation habits.
I’d additionally like so as to add, that by an interactive notion framework, this provides us a chance to benefit from multimodal energetic sensing.
So apart from imaginative and prescient, different sensory modalities are inherently tied to interplay. or I ought to say many of those nontraditional sensors depend on alerts that end result from forceful interplay with the surroundings. So for example, I feel sound is sort of beneath explored inside robotics as a helpful sort of sign sound can cue a robotic into what kind of granular floor it’s strolling on, or it may assist a robotic affirm a profitable meeting activity by listening for a click on, as one half is connected to the opposite.
Um, Jivko Sinapov who you interviewed on robohub, uh, used completely different exploratory procedures and the ensuing sound to categorise various kinds of objects in containers. I also needs to point out that I observed one among your individual papers with Heather Culbertson, proper?
Uh, involving modeling the sounds from device to floor interactions, that are indicative of floor texture properties. Proper?
Shihan Lu: And in the wrong way, we’re making an attempt to mannequin the sound. And right here is once you make the most of the sounds within the, within the activity. It’s like the 2 instructions of the analysis.
Carolyn Matl: Yeah, however what’s so attention-grabbing is what they share is that, in the end the sound is created by interplay, proper? sound is straight associated to occasion pushed exercise and it alerts modifications within the state of the surroundings particularly when issues, make and break contact, or in different phrases, when issues work together with every.
Different modalities that I discovered to be fairly helpful in my very own analysis are drive in tactile sensing. Like the quantity of drive or tactical data you obtained from dynamically, interacting with an object is a lot richer than for those who have been to simply statically maintain it in place. And we are able to get into this just a little bit later, however principally designing a brand new tactile sensor that might be used actively allowed us to focus on the issue of dough manipulation, which I’d think about a reasonably difficult manipulation activity.
So sure, I do imagine that interactive notion basically is a profit to robots for tackling difficult manipulation duties.
Shihan Lu: Nice. And, lastly, you talked about that, you’re making an attempt to make use of, this interactive notion to assist with a dough rolling activity. And your very current work StRETcH – “delicate to resistive elastic tactile hand” which is a delicate tactile sensor you designed particularly for one of these activity.
Do you continue to keep in mind, the place did you get the primary inspiration of designing a delicate tactile sensor for the aim of dough rolling?
Carolyn Matl: So I feel I’d say that usually, for my part as a roboticist. I wish to first discover a actual world problem for an utility I wish to tactile, outline an issue assertion tosolidify what I’d like to perform, after which brainstorm methods to strategy that downside.
And so that is the standard strategy that I wish to take. A number of my inspiration does come straight from the appliance area. So for example, I like to prepare dinner, so I typically discover myself fascinated by liquids and doughs, and at the same time as an individual manipulating most of these supplies takes fairly a little bit of dexterity.
And we’d not give it some thought on, on the every day, however even getting ready a bowl of cereal requires a good bit of interactive notion. So a whole lot of the observations from every day life served as inspiration for my PhD work on high of that, I believed so much about the identical issues, however from the robotic’s perspective.
Why is that this activity straightforward for me to do and troublesome for the robotic? The place do the present limitations lie in robotics that stop us from having a robotic that may deal with all of those completely different unstructured supplies. And each single time I ask that query, I discover myself revisiting the restrictions inside robotic notion and what makes it so difficult.
So, yeah, I’d say that usually, I take them extra purposes ahead strategy. However generally, , you may design a cool sensor or algorithm for one utility after which understand that it might be actually helpful for one more utility. So for instance, the primary tactile sensor I designed was joint work with Ben McInroe on a mission, headed by Ron Fearing at Berkeley.
And our purpose was to design a delicate tactile sensors/actuator that would differ in stiffness and the appliance area or motivation behind this purpose was that delicate robots are protected to make use of in environments, which have, for example, people or delicate objects since they’re compliant and might conform to their surrounding surroundings.
Nevertheless, they’re troublesome to equip with notion, capabilities, and could be fairly restricted of their drive output, until they will differ their stiffness. So with that utility in thoughts, we designed a variable stiffness delicate, tactile sensor that was pneumatically actuated, which we referred to as SOFTCell. And what was so enjoyable about SOFTCell was with the ability to examine the sensing and actuation duality, which was a functionality I hadn’t seen in lots of different sensors earlier than SOFTcell may reactively change its personal properties in response to what it was sensing in an effort to exert drive on the world.
Seeing these capabilities come to life, this made me understand that related know-how might be actually helpful for dough manipulation, which includes a whole lot of reactive changes primarily based on contact. And that’s type of what impressed the thought of the “delicate to resistive elastic tactal hand” or StRETcH.
So in a manner right here the place the creation of 1 sensor impressed me to pursue one other utility area.
Shihan Lu: Gotcha would you introduce like a fundamental class of your stretch sensor, the delicate tactile sensor, designed for the dough rolling, uh, which class it belongs to?
Carolyn Matl: Yeah.
So in a common sense, the “Comfortable to Resistive Elastic Tactile Hand” is a delicate tactal sensor. there’s all kinds of soppy sensing know-how on the market. They usually all have their benefits particularly areas. And as roboticists, a part of our job is understanding the trade-offs and determining which design is sensible for our explicit utility.
so I can briefly go over perhaps a few of these varieties of sensors and the way we reached the conclusion of the design first stretch.
So for example, so there’s a whole lot of delicate sensing know-how on the market, together with, one sensible answer I’ve seen is to embed a grid of conductive wires or elastomers into the deformable materials, however this then limits the utmost quantity of pressure the delicate materials can now bear, proper?
As a result of now that’s outlined by the extra inflexible conductive materials. so to handle this scientists have been creating actually neat options like conductive hydrogels, however then for those who go down that tough materials science route, it would grow to be fairly difficult to really manufacture the sensor.
After which it wouldn’t be so sensible to check in a robotics setting. then there are few delicate, tactile sensors you’ll be able to really buy, like for example, the BioTac sensor, which is principally the dimensions of a human finger and consists of a conductive fluidic layer within a rubbery pores and skin. In order that saves you the difficulty of creating your individual sensor, but it surely’s additionally fairly costly and the uncooked alerts are troublesome to interpret.
Except you’re taking a deep studying strategy, like Yashraj Narang, et al from Nvidia’s Seattle robotics lab. However delicate tactile sensors don’t have to be so advanced. They are often so simple as a stress sensor in a pneumatic actuated finger or a artistic manner I’ve seen stress sensors utilized in delicate robots is from Hannah Stewart’s lab at UC Berkeley, the place they measured suction stream as a type of underwater, tactical sensing.
And at last, you’ll have seen these grow to be extra standard lately, however there are additionally optical primarily based delicate tactile sensors. And what I imply by optically primarily based is that these sensors have a delicate interface that interacts with objects for the surroundings and a photodiode or digital camera is contained in the sensor and is used to picture the deformations skilled by the delicate pores and skin.
And from these picture deformations, you’ll be able to infer issues like forces, shear, object geometry, and even generally you probably have a excessive decision sensor, you’ll be able to picture the feel of the item.
So some examples of one of these sensor embody the OptoForce sensor, the GelSight from MIT, the delicate bubble from Toyota analysis, the TacTip from Bristol Robotics Lab, and eventually StRETcH: a Comfortable to Resistive Elastic Tactile Hand. and what’s good about this type of design is that it permits us to decouple the delicate pores and skin and the sensing mechanism. So the sensing mechanism doesn’t impose any constraints on the pores and skin’s most pressure.
And on the similar time, if the deformations are imaged by a digital camera, this provides the robotic spatially wealthy tactical data. So, yeah, in the end we selected this design for our personal delicate, tactile sensor, since hardware-wise, uh, this type of design offered a pleasant stability between complexity and performance.
Shihan Lu: Your StRETcH sensor, can also be beneath the optical tactile sensor class, optical primarily based tactile sensor. Throughout this information assortment course of, what particular method are you utilizing to do the info processing for particularly one of these very new, very completely different information sort?
Carolyn Matl: So usually, I are likely to lean on the aspect of utilizing as a lot information or construction you’ll be able to derive from physics or identified fashions earlier than diving utterly into let’s say finish to finish latent characteristic area strategy.
Um, I’ve to say deep studying has taken off inside the imaginative and prescient group partly as a result of laptop imaginative and prescient scientists spent a substantial amount of time learning foundational matters like projective 3d reconstruction, optical stream. How filters work just like the Sobo filter for edge detection and SIFT options for object recognition.
And all of that science and engineering effort laid out an important basis for all of the wonderful current developments that use deep studying and laptop imaginative and prescient. so learning classical laptop imaginative and prescient, strategies of characteristic design and filters offers nice instinct for deciphering internal layers. We’re designing networks for end-to-end studying and in addition nice instinct for evaluating the standard of that information.
Now for these new varieties of information that we’re buying with these new sensors. I feel related vital work must be finished and is being finished earlier than we are able to leap into utterly finish to finish approaches or options.
So particularly if this information is collected inside an interactive notion framework, there’s normally a transparent causal relationship between the motion the robotic takes the sign or information that’s noticed, and the factor that’s being inferred.
So why not use present bodily fashions or bodily related options to interpret a sign? Particularly if what triggered that sign within the first place. Proper? And that’s a part of why I imagine interactive notion is such a ravishing framework because the robotic can actively change the state of an object or the surroundings to deliberately induce alerts that may be bodily interpreted.
Now. I don’t suppose there’s something fallacious with utilizing deep studying approaches to interpret these new information sorts. For those who’re utilizing it as a device to study a posh dynamics mannequin, that’s nonetheless grounded in physics. So I can provide an instance. I discussed earlier that Yashraj S. Narang et. al. From Nvidia labored with the BioTac sensor to interpret it’s uncooked, low dimensional alerts.
And to do that, they collected an information set of uncooked BioTac alerts noticed because the robotic used the sensor to bodily work together with a drive sensor. So along with this dataset, they’d a corresponding physics-based 3d finite aspect mannequin of the BioTac, which primarily served as their floor fact and utilizing a neural web, they have been capable of map the uncooked, troublesome to interpret alerts, to excessive density deformation fields.
And so I feel that’s an important instance the place deep studying is used to assist the interpretation of a brand new information sort whereas nonetheless grounding their interpretation in physics.
Shihan Lu: Attention-grabbing. Yeah. So since there’s a causal relationship between the motion and the sensory output within the interactive notion, So the function of physics is sort of, it’s fairly vital right here.
It’s more durable to cut back the dependence on the large quantity of datasets, proper? As a result of we all know the magic of deep studying, normally it will get significantly better when it has extra information. Do you suppose utilizing these interactive notion manner is the gathering of knowledge extra time consuming, and tougher evaluating to the normal, like passive notion strategies?
Carolyn Matl: I feel this turns into an actual bottleneck solely once you really want a whole lot of information to coach a mannequin, such as you alluded to. For those who’re capable of interpret the sensor alerts with a low dimensional physics-based mannequin, then the quantity of knowledge you’ve got, shouldn’t be a bottleneck.
In truth, actual information is at all times type of the gold customary for studying a mannequin. Since in the end you’ll be making use of the mannequin to actual information, and also you don’t wish to over-fit to any type of artifacts or bizarre distributional shifts that is perhaps launched for those who, for example, increase your information by stuff that, for instance, synthetically generated in simulation.
That being stated, generally you gained’t have entry to a physics-based mannequin that’s mature sufficient or advanced sufficient to interpret the info that you simply’re observing. As an example, in collaboration with Nvidia Seattle robotics lab, I used to be learning robotic manipulation of grains and making an attempt to give you a solution to infer their materials properties from a single picture of a pile of grains.
Now the motivation behind this was that by inferring the fabric properties of grains, which in the end impacts their dynamics, the robotic can then predict their habits to carry out extra exact, manipulation duties. So for example, like pouring grains right into a bowl, you’ll be able to think about how painful and messy it could be to gather this information in actual life. Proper?
As a result of initially, you don’t have a identified mannequin for the way these grains will behave. Um, and so sure. Fairly painful to gather in actual life, however utilizing NVIDIA’s physics simulator and a Bayesian inference framework, they referred to as BayesSim. We may generate a whole lot of information in simulation to then study a mapping from granular piles to granular materials properties.
However after all, the basic problem with counting on information synthesis or augmentation in simulation. Particularly with this new information sort, proper? with this new information that we’re gathering from new sensors is, the problem is that this simulation to actuality hole, which individuals name the SIM to actual hole, the place distributions in simulation don’t fairly match these in actual life.
Partly resulting from decrease complexity representations in simulation, inaccurate physics and lack of stochastic modelling. So we confronted these challenges when, in collaboration, once more, with Nvidia, I studied the issue of making an attempt to shut the SIM to actual hole by including discovered stochastic dynamics to a physics simulator.
And one other problem is what if you wish to increase information that isn’t simply represented in simulation. So for instance, we have been utilizing sound to measure the stochastic dynamics of a bouncing ball. However as a result of the sounds of a bouncing ball are event-driven, we have been capable of circumvent the issue of simulating sound.
So our SIM to actual hole was now not depending on this drastic distinction in information illustration. I even have one other instance, um, at Toyota analysis in our cell manipulation group, there’s been some implausible work on studying depth from stereo pictures. They usually name their simulation framework, SimNet, and oftentimes once you study from stimulated pictures, fashions can over-fit to bizarre texture or non photorealistic rendering artifacts.
so to get actually real looking simulation information, to match actual information, you typically need to pay a excessive value when it comes to time, computation and assets to generate or render that simulated information. Nevertheless, because the SIMNET workforce was specializing in the issue of perceiving 3d geometry, somewhat than texture, they might get actually excessive efficiency studying on non-photo real looking textured, simulated pictures, which might be procedurally generated at a a lot sooner charge.
So that is one other instance I like of the place the simulation and actual information codecs will not be the identical, however intelligent engineering could make artificial information simply as invaluable to study these fashions of recent information.
Shihan Lu: However you additionally talked about synthesize the info or augmented information generally the place we’ve got to pay the price for like overfitting points and low constancy points.
And it’s not at all times the perfect transfer to simply out being. And the, generally we nonetheless type of must depend on the actual information .
Carolyn Matl: Precisely, yeah.
Shihan Lu: Can we speak just a little bit, like the explanations half? The place did you get the thought and what sort of bodily behaviors you’re making an attempt to imitate or making an attempt to study within the studying half?
Carolyn Matl: Certain. So perhaps for this level, I’ll consult with you my most up-to-date work with the StRETcH sensor.
So the Comfortable to Resistive Elastic Tactile Hand, the place we determined to take a mannequin primarily based reinforcement studying strategy to roll a ball of dough into a selected size. And absolutely when you concentrate on this downside. It includes extremely advanced dynamic interactions with a delicate elastic sensor and an elastoplastic object, our information sort can also be advanced as nicely, because it’s a excessive dimensional depth picture of the sensory pores and skin.
So how can we design an algorithm that may deal with such complexity? Nicely, the mannequin primarily based reinforcement studying framework was very helpful since we needed the robotic to have the ability to use its information of stiffeness to effectively roll doughs of various hydration ranges. So therefore this provides us our mannequin primarily based half, however we additionally needed it to have the ability to enhance or regulate its mannequin as the fabric properties of the dough modified.
Therefore the reinforcement studying a part of the algorithm. And that is needed since for those who’ve ever labored with dough, it will probably change fairly drastically relying on its hydration ranges or how a lot time it has needed to relaxation. And so whereas we knew we needed to make use of mannequin primarily based reinforcement studying, we have been caught with the issue that this algorithm scales poorly with elevated information complexity.
So we in the end determined to simplify each the state area of the dough and motion area of the robotic, which allowed the robotic to tractably resolve this downside. And because the stretch sensor was able to measuring a proxy for stiffness utilizing its new information from the digital camera imaging, the deformations of the pores and skin.
this estimate of stiffness was primarily used to seed the mannequin of the dough and make the algorithm converge sooner to a coverage that would effectively roll out the dough into a selected size.
Shihan Lu: Okay. Very attention-grabbing. So throughout this model-based reinforcement studying. So is there any particular manner you’re making an attempt to design your reward perform and, uh, otherwise you’re making an attempt to make your reward perform to comply with a selected actual life purpose?
Carolyn Matl: Yeah. So, as a result of the general purpose was fairly easy, it was to get the dough into a selected size it was principally the form of the dough which we have been capable of compress the state area of the dough into simply three dimensions, the bounding field of the dough.
However you’ll be able to think about {that a} extra difficult form would require a better dimensional extra expressive state area. However since we have been capable of compress the state area into such a low dimension, this allowed us to resolve the issue much more simply.
Shihan Lu: And the lastly, I noticed in your private webpage, you say you’re employed on unconventional sensors. And if we needed to make these unconventional sensors grow to be typical and let extra researchers and the labs use them in their very own analysis. Which elements ought to we allocate extra assets and perhaps want extra consideration?
Carolyn Matl: Yeah. In order that’s an important query. I feel virtually talking, on the finish of the day, we must always allocate extra assets for creating, simpler interfaces and packaging for these new unconventional sensors. Like a part of the explanation why laptop imaginative and prescient is so standard in robotics is that it’s straightforward to interface with the digital camera.
There are such a lot of varieties of digital camera sensors obtainable that may be bought for an inexpensive value. Digital camera drivers are packaged properly. And, there are a ton of picture libraries that assist take the load off of picture processing. And at last, we reside in a world that’s inundated with visible information. So for roboticists, who’re desirous to get proper to work on enjoyable manipulation issues, the training curve to plug in a digital camera and use it for notion is pretty low.
In truth, I feel it’s fairly enticing for all these causes. Nevertheless, I do imagine that if there have been extra software program packages or libraries that have been devoted to interfacing with these new or unconventional sensors on a decrease degree, this might assist significantly in making these sensors appear extra interesting to strive utilizing inside the robotics group.
So for instance, for one among my tasks, I wanted to interface with three microphones. And simply the leap from two to a few microphones required that I purchase an audio interface gadget to have the ability to stream this information in parallel. And it took fairly a little bit of engineering effort to search out the correct {hardware} and software program interface to simply to allow my robotic to listen to.
Yeah. Nevertheless, if these unconventional sensors have been packaged in a manner that was supposed for robotics, It might take away the step perform needed, for determining interface with the sensor. Um, permitting researchers to instantly discover use them in their very own robotics purposes. And that’s how I think about we are able to make these unconventional sensors grow to be extra typical sooner or later.
Shihan Lu: A fast follow-up query. It’s if we simply give attention to a selected class beneath the delicate tactile sensor. Do you suppose we can have a standardized sensor for this kind sooner or later? If there’s a such a standardized sensor we use similar to cameras, what’s the specification the way in which, think about we might envision.
Carolyn Matl: Nicely, I think about, I assume with cameras, , there’s nonetheless an enormous variety in varieties of cameras. We’ve got depth cameras, we’ve got LIDAR, we’ve got conventional RGB cameras, we’ve got warmth cameras, uh, thermal cameras somewhat. And so I, I may see tactile sensing for example, progressing in an analogous manner the place we can have courses of tactile sensors that can type of be extra standard.
Due to a selected utility. for example, you’ll be able to think about vibration sensors is perhaps extra helpful for one utility. Comfortable, optical, tactile sensors. Um, we’ve been seeing a whole lot of their use in robotic purposes. For a manipulation. So I feel sooner or later, we’ll see courses of those, tactile sensors changing into extra distinguished.
Um, as we see within the courses of cameras which can be obtainable now that I answered your query. Yeah.
Shihan Lu: Yeah. That’s nice. For digital camera today, we nonetheless have a wide range of completely different cameras they usually have their very own strengths for particular duties. So that you envision tactile sensors are additionally like centered on their very own particular activity or a selected areas. It’s very onerous to have like generalized and the usual or common tactile sensors, which may deal with plenty of duties. So we nonetheless must specify them into the small areas.
Carolyn Matl: Sure. I feel there nonetheless must be some work when it comes to integration of all this new, know-how.
However on the finish of the day as engineers, we care about trade-offs and, um, that’ll in the end lead us to decide on what sensor makes probably the most sense for our utility area.
Shihan Lu: Thanks a lot on your attention-grabbing speak and many tales behind your self, the tactile sensor design, and in addition tell us a plenty of new information and the views about interactive notion.
Carolyn Matl: Thanks a lot for having me immediately.
Shihan Lu: Thanks. It was a pleasure.
——————–transcript——————-
tags: c-Analysis-Innovation, cx-Analysis-Innovation, schooling, Manipulation, podcast, Analysis, Robotics know-how, Sensing
Shihan Lu
[ad_2]

