


[ad_1]
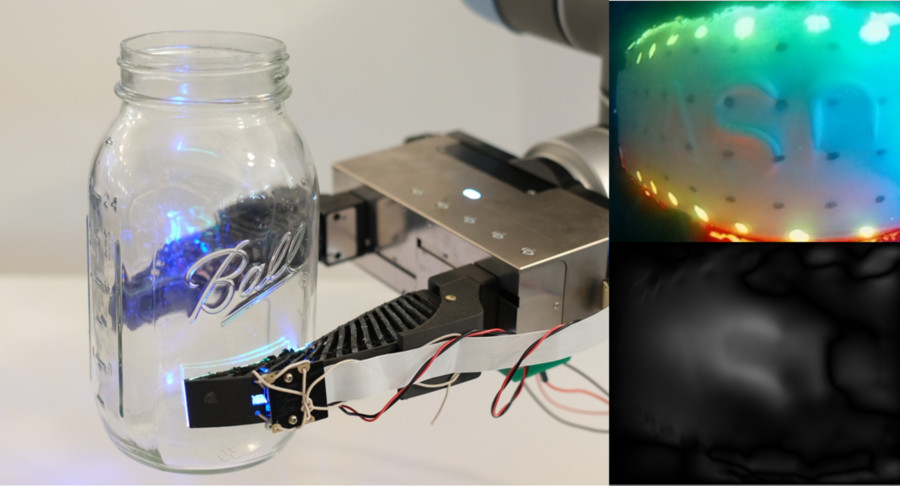
The GelSight Fin Ray gripper holds a glass Mason jar with its tactile sensing. Picture courtesy of MIT CSAIL.
By Rachel Gordon | MIT CSAIL
The notion of a giant metallic robotic that speaks in monotone and strikes in lumbering, deliberate steps is considerably exhausting to shake. However practitioners within the discipline of sentimental robotics have a wholly totally different picture in thoughts — autonomous gadgets composed of compliant components which can be light to the contact, extra intently resembling human fingers than R2-D2 or Robby the Robotic.
That mannequin is now being pursued by Professor Edward Adelson and his Perceptual Science Group at MIT’s Pc Science and Synthetic Intelligence Laboratory (CSAIL). In a current challenge, Adelson and Sandra Liu — a mechanical engineering PhD pupil at CSAIL — have developed a robotic gripper utilizing novel “GelSight Fin Ray” fingers that, just like the human hand, is supple sufficient to control objects. What units this work other than different efforts within the discipline is that Liu and Adelson have endowed their gripper with contact sensors that may meet or exceed the sensitivity of human pores and skin.
Their work was introduced final week on the 2022 IEEE fifth Worldwide Convention on Tender Robotics.
The fin ray has grow to be a well-liked merchandise in delicate robotics owing to a discovery made in 1997 by the German biologist Leif Kniese. He seen that when he pushed in opposition to a fish’s tail along with his finger, the ray would bend towards the utilized drive, virtually embracing his finger, somewhat than tilting away. The design has grow to be fashionable, nevertheless it lacks tactile sensitivity. “It’s versatile as a result of it may passively adapt to totally different shapes and due to this fact grasp a wide range of objects,” Liu explains. “However to be able to transcend what others within the discipline had already completed, we got down to incorporate a wealthy tactile sensor into our gripper.”
The gripper consists of two versatile fin ray fingers that conform to the form of the thing they arrive in touch with. The fingers themselves are assembled from versatile plastic supplies made on a 3D printer, which is fairly commonplace within the discipline. Nonetheless, the fingers sometimes utilized in delicate robotic grippers have supportive cross-struts operating by means of the size of their interiors, whereas Liu and Adelson hollowed out the inside area so they may create room for his or her digital camera and different sensory parts.
The digital camera is mounted to a semirigid backing on one finish of the hollowed-out cavity, which is, itself, illuminated by LEDs. The digital camera faces a layer of “sensory” pads composed of silicone gel (generally known as “GelSight”) that’s glued to a skinny layer of acrylic materials. The acrylic sheet, in flip, is connected to the plastic finger piece on the reverse finish of the internal cavity. Upon touching an object, the finger will seamlessly fold round it, melding to the thing’s contours. By figuring out precisely how the silicone and acrylic sheets are deformed throughout this interplay, the digital camera — together with accompanying computational algorithms — can assess the final form of the thing, its floor roughness, its orientation in area, and the drive being utilized by (and imparted to) every finger.
Liu and Adelson examined out their gripper in an experiment throughout which simply one of many two fingers was “sensorized.” Their gadget efficiently dealt with such objects as a mini-screwdriver, a plastic strawberry, an acrylic paint tube, a Ball Mason jar, and a wine glass. Whereas the gripper was holding the pretend strawberry, as an illustration, the interior sensor was in a position to detect the “seeds” on its floor. The fingers grabbed the paint tube with out squeezing so exhausting as to breach the container and spill its contents.
The GelSight sensor may even make out the lettering on the Mason jar, and did so in a somewhat intelligent method. The general form of the jar was ascertained first by seeing how the acrylic sheet was bent when wrapped round it. That sample was then subtracted, by a pc algorithm, from the deformation of the silicone pad, and what was left was the extra delicate deformation due simply to the letters.
Glass objects are difficult for vision-based robots due to the refraction of the sunshine. Tactile sensors are resistant to such optical ambiguity. When the gripper picked up the wine glass, it may really feel the orientation of the stem and will be certain the glass was pointing straight up earlier than it was slowly lowered. When the bottom touched the tabletop, the gel pad sensed the contact. Correct placement occurred in seven out of 10 trials and, fortunately, no glass was harmed through the filming of this experiment.
Wenzhen Yuan, an assistant professor within the Robotics Institute at Carnegie Mellon College who was not invovled with the analysis, says, “Sensing with delicate robots has been a giant problem, as a result of it’s troublesome to arrange sensors — that are historically inflexible — on delicate our bodies,” Yuan says. “This paper supplies a neat resolution to that downside. The authors used a really sensible design to make their vision-based sensor work for the compliant gripper, on this method producing superb outcomes when robots grasp objects or work together with the exterior setting. The know-how has a lot of potential to be broadly used for robotic grippers in real-world environments.”
Liu and Adelson can foresee many doable purposes for the GelSight Fin Ray, however they’re first considering some enhancements. By hollowing out the finger to clear area for his or her sensory system, they launched a structural instability, an inclination to twist, that they imagine will be counteracted by means of higher design. They need to make GelSight sensors which can be appropriate with delicate robots devised by different analysis groups. And so they additionally plan to develop a three-fingered gripper that could possibly be helpful in such duties as choosing up items of fruit and evaluating their ripeness.
Tactile sensing, of their method, is predicated on cheap parts: a digital camera, some gel, and a few LEDs. Liu hopes that with a know-how like GelSight, “it might be doable to provide you with sensors which can be each sensible and inexpensive.” That, not less than, is one purpose that she and others within the lab are striving towards.
The Toyota Analysis Institute and the U.S. Workplace of Naval Analysis supplied funds to assist this work.
tags: c-Analysis-Innovation
MIT Information
[ad_2]

