| Mar 08, 2022 |
|
|
|
(Nanowerk Information) Robotics engineers at South Korea’s Daegu Gyeongbuk Institute of Science and Know-how (DGIST) have developed and examined a brand new human-like mechanical hand that mixes the advantages of current ones whereas eliminating their weaknesses.
|
|
The design is described within the journal Mushy Robotics (“Shock Resistive Flexure-Primarily based Anthropomorphic Hand with Enhanced Payload”).
|
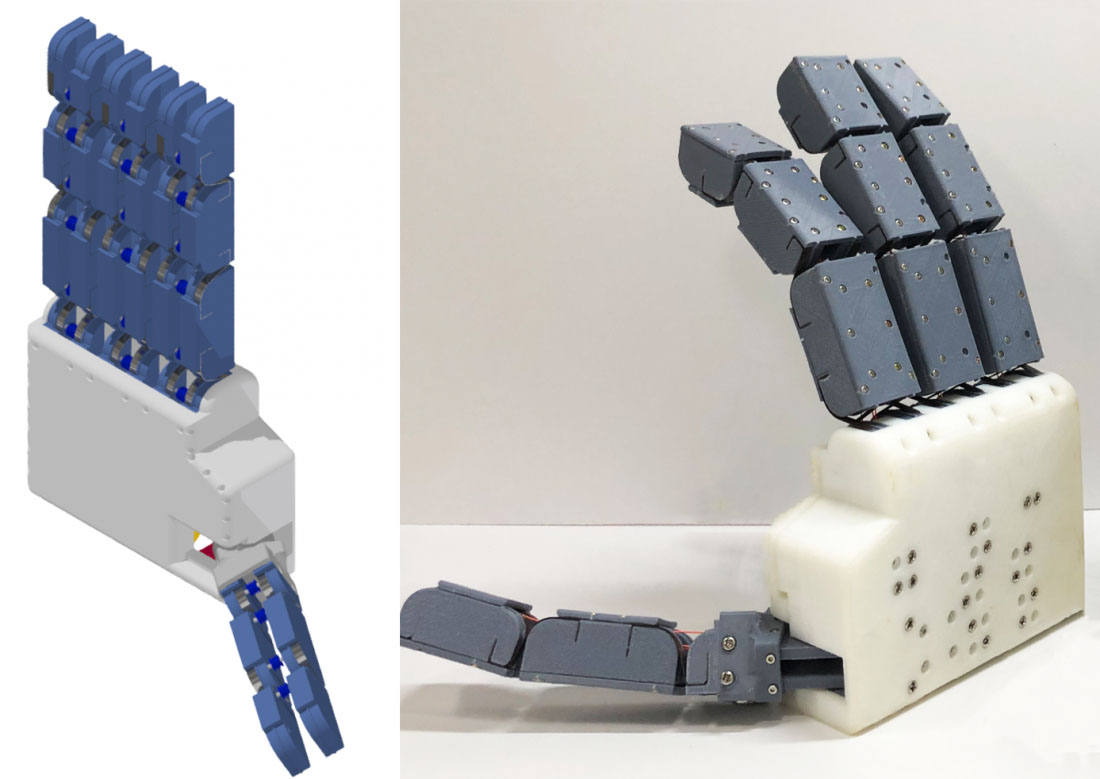 |
| The crossed flexure hinge (CFH) system on this robotic hand permits extra shock absorbency than a pin-jointed robotic hand. (Picture: DGIST)
|
|
Till now, competing robotic hand designs provided a trade-off between flexibility, power and sturdiness. One generally used design using inflexible pin-like finger joints can raise heavy payloads, however is definitely broken in collisions, significantly if hit from the aspect.
|
|
In the meantime, versatile silicon-based fingers are harder to interrupt and grasp differently-shaped objects higher, however fall quick on lifting energy.
|
|
“Sensible industrial and cooperative robots that work together with people want resilience and power,” says Dongwon Yun, who heads the DGIST BioRobotics and Mechatronics Lab.
|
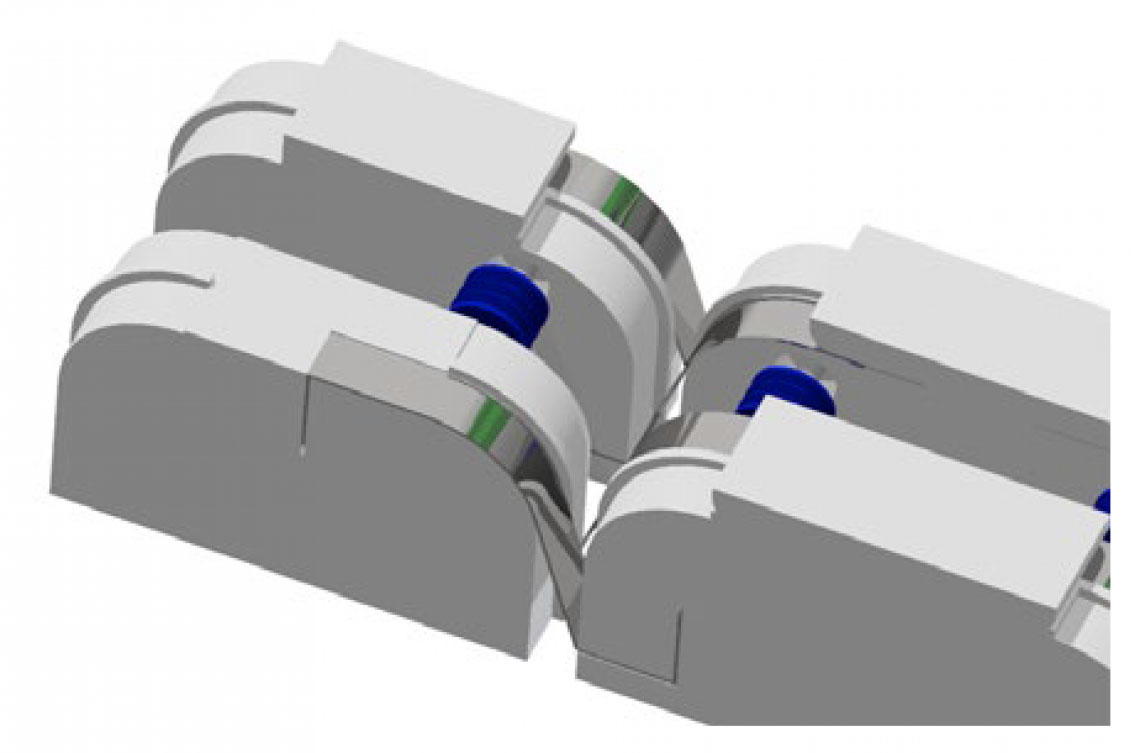 |
| The crossed flexure hinge is fabricated from two metallic strips organized in an X-shape that may flex or bend in a single place whereas remaining inflexible in others. (Picture: DGIST)
|
|
The DGIST analysis group investigated whether or not {a partially} versatile robotic hand, with joints fabricated from inflexible hyperlinks related to a construction often called a crossed flexural hinge (CFH), may enhance lifting energy whereas minimizing injury within the occasion of a collision. Usually, a CFH is fabricated from two strips of metallic organized in an X-shape that may flex or bend in a single place whereas remaining inflexible in others.
|
|
The group made the metallic strips that function the CFH connecting joints that enable the robotic fingers to curve and straighten like in a human hand. They then demonstrated the robotic hand’s potential to understand totally different objects, together with a field of tissues, a small fan and a pockets.
|
|
The CFH-jointed robotic hand was 46.7% extra shock absorbent than a pin-jointed robotic hand. It was additionally stronger than absolutely versatile robotic fingers, and was in a position to maintain objects weighing as much as 4 kilograms.
|
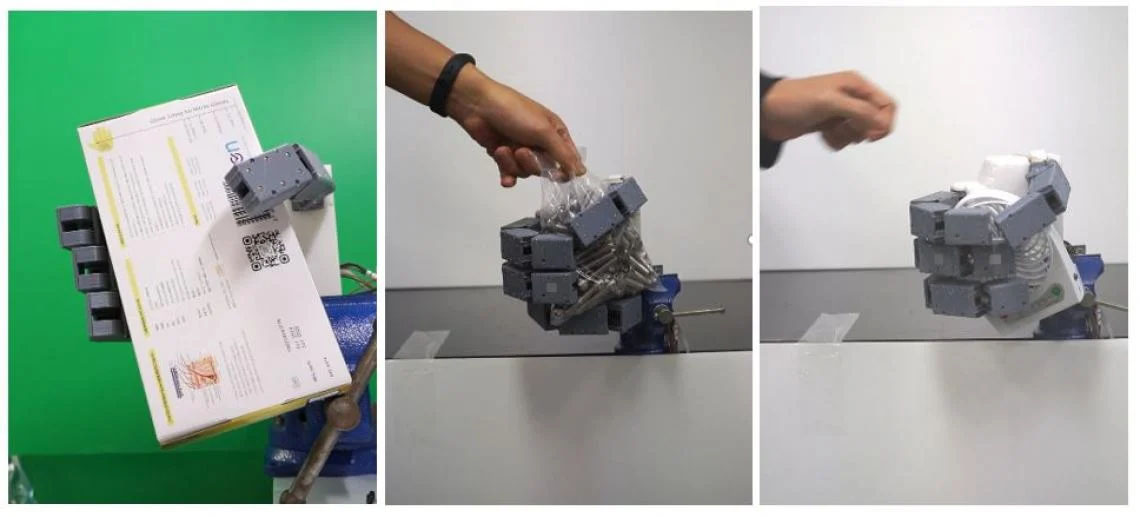 |
| The versatile robotic hand can grasp objects of varied shapes weighing as much as 4 kilograms. (Picture: DGIST)
|
|
Additional enhancements are wanted earlier than robots with these partially-flexible fingers are in a position to go to work alongside or immediately with people. The researchers notice that extra analyses are wanted to find out essentially the most environment friendly supplies for hand design, whereas additional subject experiments will assist pinpoint one of the best sensible purposes.
|
|
“The economic and healthcare settings, the place robots are broadly used, are dynamic and demanding locations, so it’s necessary to maintain bettering robotic efficiency,” says DGIST engineering PhD scholar Junmo Yang, the research’s first writer.
|



