


[ad_1]
|
Hearken to this text  |
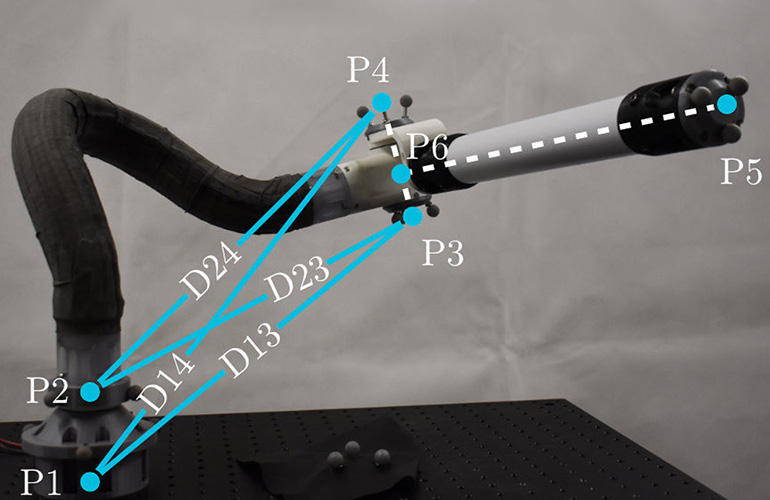
The arm is inflexible from P6-P5, and has a joint at P6, the decrease a part of the arm is malleable. | Supply: Imperial Faculty London
Researchers on the Imperial Faculty London have created a malleable robotic arm. The arm may be guided into form manually, utilizing combined actuality good glasses and thru movement monitoring cameras to make sure exact positioning.
Many robotic arms are made with agency joints and limbs to make sure power, however the researchers wished to create an arm that’s versatile sufficient for use in a number of functions.
The arm is made malleable with layers of slippery mylar sheets, which slide over one another and may be locked into place when the arm is within the right place. The consumer is ready to see templates utilizing the augmented actuality (AR) goggles, which superimposes the proper positioning onto the customers surroundings. When the arm is within the right place, the template turns inexperienced.

The inexperienced define of the arm exhibits the place it ought to be positioned. | Supply: Imperial Faculty London
The arm has a number of benefits over extra conventional robotic arms. First, it’s light-weight, which makes it excellent for house journey, the place each additional pound counts. It’s additionally mild, so it could possibly be used as an additional hand in harm rehabilitation. The researchers additionally hope the arm may be helpful in manufacturing and automobile and constructing upkeep.
Researchers determined to make use of AR to information manipulations of the arm in order that it could possibly be finished by individuals not conversant in robotics. They examined the system on 5 males aged 20-26 who had expertise in robotics however not in manipulating malleable robots. Every of them have been in a position to transfer the arm into the proper positioning.
The researchers, Dr. Nicolas Rojas and PhD researcher Angus Clark, of the Dyson Faculty of Design Engineering, and PhD researcher Alex Ranne, of the division of computing, revealed their leads to the IEEE Robotics and Automation Journal.
The following steps will contain the researchers including contact and audio parts to the AR, to extend accuracy in positioning the robotic. They’re additionally keen on strengthening the robotic to make them extra inflexible when locked into place.
[ad_2]

