



[ad_1]
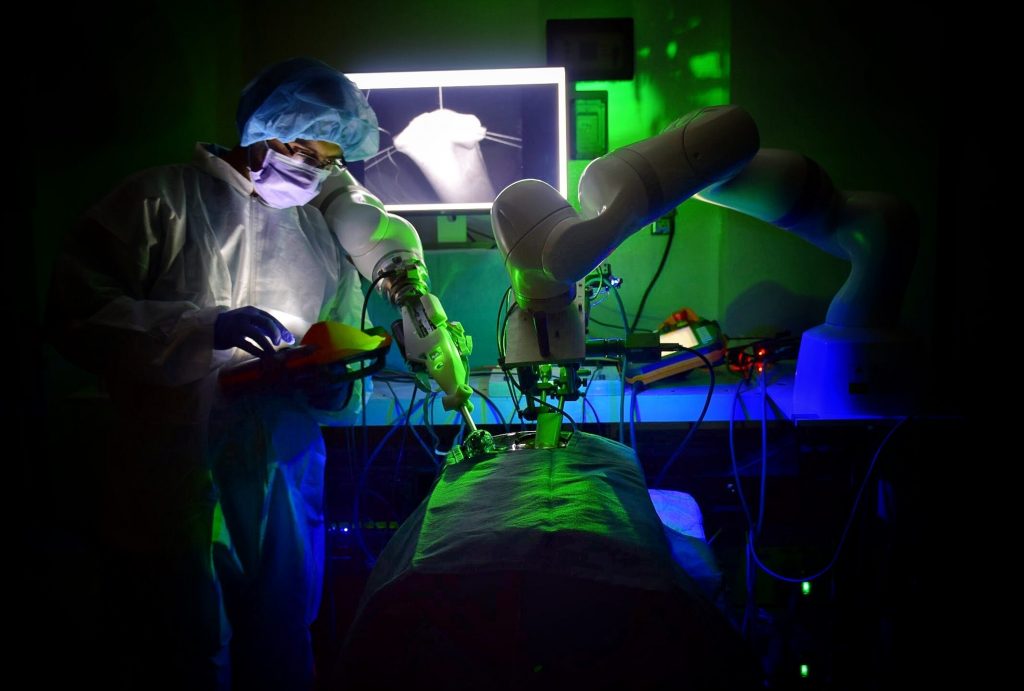
Axel Krieger is the Head of the Clever Medical Robotic Programs and Tools (IMERSE) Lab at Johns Hopkins College, the place Justin Opfermann is pursuing his PhD diploma. Along with H. Saeidi, M. Kam, S. Wei, S. Leonard , M. H. Hsieh and J. U. Kang, they not too long ago printed the paper ‘Autonomous robotic laparoscopic surgical procedure for intestinal anastomosis‘ in Science Robotics. Under, Axel and Justin inform us extra about their work, the methodology, and what they’re planning subsequent.
What’s the subject of the analysis in your paper?
Our analysis is concentrated on the design and analysis of medical robots for autonomous mushy tissue surgical procedures. Specifically, this paper describes a surgical robotic and workflow to carry out autonomous anastomosis of the small bowel. Efficiency of the robotic is carried out in artificial tissues towards professional surgeons, adopted by experiments in pig research to reveal preclinical feasibility of the system and method.
May you inform us in regards to the implications of your analysis and why it’s an fascinating space for examine?
Anastomosis is an important step to the reconstructive part of surgical procedure and is carried out over 1,000,000 instances annually in the US alone. Surgical outcomes for sufferers are extremely depending on the surgeon’s ability, as even a single missed sew can result in anastomotic leak and an infection within the affected person. In laparoscopic surgical procedures these challenges are much more troublesome resulting from area constraints, tissue movement, and deformations. Robotic anastomosis is a method to make sure that surgical duties that require excessive precision and repeatability might be carried out with extra accuracy and precision in each affected person impartial of surgeon ability. Already there are autonomous surgical robots for exhausting tissue surgical procedures akin to bone drilling for hip and knee implants. The Good Tissue Autonomous Robotic (STAR) takes the autonomous robotic ability one step additional by performing surgical duties on mushy tissues. This permits a robotic to work with a human to finish extra difficult surgical duties the place preoperative planning shouldn’t be potential. We hypothesize that this can end in a democratized surgical method to affected person care with extra predictable and constant affected person outcomes.
May you clarify your methodology?
Till this paper, autonomous laparoscopic surgical procedure was not potential in mushy tissue as a result of unpredictable motions of the tissue and limitations on the scale of surgical instruments. Performing autonomous surgical procedure required the event of novel suturing instruments, imaging techniques, and robotic controls to visualise a surgical scene, generate an optimized surgical plan, after which execute that surgical plan with the very best precision. Combining all of those options right into a single system is difficult. To perform these objectives we built-in a robotic suturing instrument that simplifies wristed suturing motions to the press of a button, developed a 3 dimensional endoscopic imaging system primarily based on structured mild that was sufficiently small for laparoscopic surgical procedure, and carried out a conditional autonomy management scheme that permits autonomous laparoscopic anastomosis. We evaluated the system towards professional surgeons performing finish to finish anastomosis utilizing both laparoscopic or da Vinci tele-operative methods on artificial small bowel throughout metrics akin to consistency of suture spacing and suture chew, sew hesitancy, and general surgical time. These experiments had been adopted by preclinical feasibility exams in porcine small bowel. Restricted necropsy was carried out after one week to guage the standard of the anastomosis and immune response.
What had been your primary findings?
Comparability research in artificial tissues indicated that sutures positioned by the STAR system had extra constant spacing and chew depth than these utilized by surgeons utilizing both a handbook laparoscopic approach or robotic help with the da Vinci surgical system. The improved precision afforded by the autonomous method led to a better high quality anastomosis for the STAR system which was qualitatively verified by laminar 4 dimension MRI move fields throughout the anastomosis. The STAR system accomplished the anastomosis with a primary sew success charge of 83% which was higher than surgeons in both group. Following the ex-vivo exams, STAR carried out laparoscopic small bowel anastomosis in 4 pigs. All animals survived the process and had a median weight acquire over the 1 week survival interval. STAR’s anastomoses had comparable burst energy, lumen space discount, and therapeutic as manually sewn samples, indicating the feasibility of autonomous mushy tissue surgical procedures.
What additional work are you planning on this space?
Our group is researching marker-less methods to trace tissue place, movement, and plan surgical duties with out the necessity for fiducial markers on tissues. The flexibility to 3 dimensionally reconstruct the surgical subject on a pc and plan surgical duties with out the necessity for synthetic landmarks would simplify autonomous surgical planning and allow collaborative surgical procedure between an autonomous robotic and human. Utilizing machine studying and neural networks, now we have demonstrated the robotic’s potential to establish tissue edges and observe pure landmarks. We’re planning to implement fail-safe methods and hope to carry out first in human research within the subsequent few years.
Concerning the interviewees
|
Justin Opfermann (MS) is a PhD robotics scholar within the Division of Mechanical Engineering at Johns Hopkins College. Justin has ten years of expertise within the design of autonomous robots and instruments for laparoscopic surgical procedure, and can be affiliated with the Laboratory for Computational Sensing and Robotics. Earlier than becoming a member of JHU, Justin was a Challenge Supervisor and Senior Analysis and Design Engineer on the Sheikh Zayed Institute for Pediatric Surgical Innovation at Kids’s Nationwide Hospital. |
tags: c-Well being-Drugs
Daniel Carrillo-Zapata
was awared his PhD in swarm robotics on the Bristol Robotics Lab in 2020. He now fosters the tradition of “scientific agitation” to interact in two-way conversations between researchers and society.
Daniel Carrillo-Zapata
was awared his PhD in swarm robotics on the Bristol Robotics Lab in 2020. He now fosters the tradition of “scientific agitation” to interact in two-way conversations between researchers and society.
[ad_2]

