


[ad_1]
The thirty fifth convention on Neural Info Processing Methods (NeurIPS2021) featured eight invited talks. On this put up, we give a flavour of the ultimate presentation.
The collective intelligence of military ants, and the robots they encourage
Radhika’s analysis focusses on collective intelligence, with the overarching purpose being to know how giant teams of people, with native interplay guidelines, can cooperate to attain globally advanced behaviour. These are fascinating techniques. Every particular person is miniscule in comparison with the huge phenomena that they create, and, with a restricted view of the actions of the remainder of the swarm, they obtain putting coordination.
Taking a look at collective intelligence from an algorithmic point-of-view, the phenomenon emerges from many people interacting utilizing easy guidelines. When run by these giant, decentralised teams, these easy guidelines lead to extremely smart behaviour.
The topic of Radhika’s discuss was military ants, a species which spectacularly display collective intelligence. With none chief, thousands and thousands of ants work collectively to self-assemble nests and construct bridge buildings utilizing their very own our bodies.
One explicit facet of research involved self-assembly of such bridges. Radhika’s analysis crew, which comprised three roboticists and two biologists, discovered that the ants created bridges adapt to visitors move and terrain. The ants additionally disassembled the bridge when the move of ants had stopped and it wasn’t wanted any extra.
The crew proposed the next easy speculation to elucidate this behaviour utilizing native guidelines: if an ant is strolling alongside, and experiences congestion (i.e. one other ant steps on it), then it turns into stationary and turns right into a bridge, permitting different ants to stroll over it. Then, if no ants are strolling on it any extra, it might probably stand up and depart.
These observations, and this speculation, led the crew to think about two analysis questions:
- Might they construct a robotic swarm with tender robots that may self-assemble amorphous buildings, identical to the ant bridges?
- Might they formulate guidelines which allowed these robots to self-assemble short-term and adaptive bridge buildings?
There have been two motivations for these questions. Firstly, the purpose of shifting nearer to realising robotic swarms that may clear up issues in a specific surroundings. Secondly, using an artificial system to higher perceive the collective intelligence of military ants.
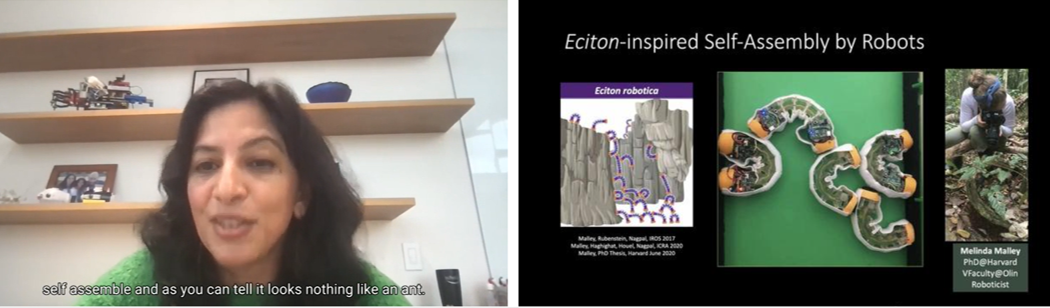 Screenshot from Radhika’s discuss
Radhika confirmed an illustration of the tender robotic designed by her group. It has two ft and a tender physique, and strikes by flipping – one foot stays hooked up, whereas the opposite detaches from the floor and flips to connect in a unique place. This permits motion in any orientation. Upon detaching, a foot searches by house to seek out someplace to connect. Through the use of grippers on the ft that may hook onto textured surfaces, and having a stretchable Velcro pores and skin, the robots can climb over one another, just like the ants. The robotic pulses, and makes use of a vibration sensor, to detect whether or not it’s in touch with one other robotic. A video demonstration of two robots interacting confirmed that they’ve efficiently created a system that may recreate the straightforward speculation outlined above.
As a way to examine the high-level properties of military ant bridges, which might require an unlimited variety of robots, the crew created a simulation. Modelling the ants to have the identical traits as their bodily robots, they had been capable of replicate the excessive degree properties of military ant bridges with their hypothesized guidelines.
You’ll be able to learn the round-ups of the opposite NeurIPS invited talks at these hyperlinks:
#NeurIPS2021 invited talks round-up: half one – Duolingo, the banality of scale and estimating the imply
#NeurIPS2021 invited talks round-up: half two – benign overfitting, optimum transport, and human and machine intelligence
tags: bio-inspired, c-Analysis-Innovation, Swarming
Lucy Smith
is Managing Editor for AIhub.
[ad_2]

