


[ad_1]
Typical cameras in stereo mode can certainly detect objects, gauge their distance, and estimate their speeds, however they don’t have the accuracy required for absolutely autonomous driving. As well as, cameras don’t work nicely at night time, in fog, or in direct daylight, and programs that use them are vulnerable to
being fooled by optical illusions. Laser scanning programs, or lidars, do provide their very own illumination and thus are sometimes superior to cameras in dangerous climate. Nonetheless, they will see solely straight forward, alongside a transparent line of sight, and can due to this fact not be capable of detect a automobile approaching an intersection whereas hidden from view by buildings or different obstacles.
Radar is worse than lidar in vary accuracy and angular decision—the smallest angle of arrival vital between two distinct targets to resolve one from one other. However we’ve got devised a novel radar structure that overcomes these deficiencies, making it far more efficient in augmenting lidars and cameras.
Our proposed structure employs what’s known as a sparse, wide-aperture multiband radar. The essential thought is to make use of quite a lot of frequencies, exploiting the actual properties of every one, to free the system from the vicissitudes of the climate and to see by means of and round corners. That system, in flip, employs superior sign processing and
sensor-fusion algorithms to supply an built-in illustration of the atmosphere.
We have now experimentally verified the theoretical efficiency limits of our radar system—its vary, angular decision, and accuracy. Proper now, we’re constructing {hardware} for varied automakers to judge, and up to date street assessments have been profitable. We plan to conduct extra elaborate assessments to reveal around-the-corner sensing in early 2022.
Every frequency band has its strengths and weaknesses. The band at 77 gigahertz and under can cross by means of 1,000 meters of dense fog with out dropping greater than a fraction of a decibel of sign power. Distinction that with lidars and cameras, which lose 10 to fifteen decibels in simply 50 meters of such fog.
Rain, nonetheless, is one other story. Even mild showers will attenuate 77-GHz radar as a lot as they’d lidar. No drawback, you would possibly assume—simply go to decrease frequencies. Rain is, in any case, clear to radar at, say, 1 GHz or under.
This works, however you need the excessive bands as nicely, as a result of the low bands present poorer vary and angular decision. Though you possibly can’t essentially equate excessive frequency with a slender beam, you should utilize an antenna array, or extremely directive antenna, to venture the millimeter-long waves within the increased bands in a slender beam, like a laser. Which means that this radar can compete with lidar programs, though it could nonetheless endure from the identical lack of ability to see exterior a line of sight.
For an antenna of given measurement—that’s, of a given array aperture—the angular decision of the beam is inversely proportional to the frequency of operation. Equally, to attain a given angular decision, the required frequency is inversely proportional to the antenna measurement. So to attain some desired angular decision from a radar system at comparatively low UHF frequencies (0.3 to 1 GHz), for instance, you’d want an antenna array tens of instances as giant because the one you’d want for a radar working within the Okay (18- to 27-GHz) or W (75- to 110-GHz) bands.
Regardless that decrease frequencies don’t assist a lot with decision, they create different benefits. Electromagnetic waves are likely to diffract at sharp edges; after they encounter curved surfaces, they will diffract proper round them as “creeping” waves. These results are too weak to be efficient on the increased frequencies of the Okay band and, particularly, the W band, however they are often substantial within the UHF and C (4- to 8-GHz) bands. This diffraction conduct, along with decrease penetration loss, permits such radars to detect objects
round a nook.
One weak spot of radar is that it follows many paths, bouncing off innumerable objects, on its method to and from the item being tracked. These radar returns are additional sophisticated by the presence of many different automotive radars on the street. However the tangle additionally brings a power: The broadly ranging ricochets can present a pc with details about what’s happening in locations {that a} beam projected alongside the road of sight can’t attain—for example, revealing cross site visitors that’s obscured from direct detection.
To see far and intimately—to see sideways and even straight by means of obstacles—is a promise that radar has not but absolutely realized. Nobody radar band can do all of it, however a system that may function concurrently at a number of frequency bands can come very shut. As an illustration, high-frequency bands, comparable to Okay and W, can present excessive decision and might precisely estimate the situation and velocity of targets. However they will’t penetrate the partitions of buildings or see round corners; what’s extra, they’re weak to heavy rain, fog, and mud.
Decrease frequency bands, comparable to UHF and C, are a lot much less weak to those issues, however they require bigger antenna components and have much less out there bandwidth, which reduces vary decision—the flexibility to tell apart two objects of comparable bearing however totally different ranges. These decrease bands additionally require a big aperture for a given angular decision. By placing collectively these disparate bands, we are able to stability the vulnerabilities of 1 band with the strengths of the others.
Completely different targets pose totally different challenges for our multiband answer. The entrance of a automobile presents a smaller radar cross part—or efficient reflectivity—to the UHF band than to the C and Okay bands. Which means that an approaching automobile can be simpler to detect utilizing the C and Okay bands. Additional, a pedestrian’s cross part reveals a lot much less variation with respect to modifications in his or her orientation and gait within the UHF band than it does within the C and Okay bands. Which means that individuals can be simpler to detect with UHF radar.
Moreover, the radar cross part of an object decreases when there’s water on the scatterer’s floor. This diminishes the radar reflections measured within the C and Okay bands, though this phenomenon doesn’t notably have an effect on UHF radars.
The tangled return paths of radar are additionally a power as a result of they will present a pc with details about what’s happening sideways—for example, in cross site visitors that’s obscured from direct inspection.
One other necessary distinction arises from the truth that a sign of a decrease frequency can penetrate partitions and cross by means of buildings, whereas increased frequencies can’t. Take into account, for instance, a 30-centimeter-thick concrete wall. The power of a radar wave to cross by means of the wall, slightly than mirror off of it, is a operate of the wavelength, the polarization of the incident subject, and the angle of incidence. For the UHF band, the transmission coefficient is round –6.5 dB over a wide range of incident angles. For the C and Okay bands, that worth falls to –35 dB and –150 dB, respectively, which means that little or no power could make it by means of.
A radar’s angular decision, as we famous earlier, is proportional to the wavelength used; however it’s also inversely proportional to the width of the aperture—or, for a linear array of antennas, to the bodily size of the array. That is one motive why millimeter waves, such because the W and Okay bands, may fit nicely for autonomous driving. A business radar unit primarily based on two 77-GHz transceivers, with an aperture of 6 cm, offers you about 2.5 levels of angular decision, greater than an order of magnitude worse than a typical lidar system, and too little for autonomous driving. Attaining lidar-standard decision at 77 GHz requires a a lot wider aperture—1.2 meters, say, in regards to the width of a automobile.
In addition to vary and angular decision, a automobile’s radar system should additionally hold observe of a number of targets, generally a whole bunch of them without delay. It may be troublesome to tell apart targets by vary if their vary to the automobile varies by just some meters. And for any given vary, a uniform linear array—one whose transmitting and receiving components are spaced equidistantly—can distinguish solely as many targets because the variety of antennas it has. In cluttered environments the place there could also be a mess of targets, this may appear to point the necessity for a whole bunch of such transmitters and receivers, an issue made worse by the necessity for a really giant aperture. That a lot {hardware} could be pricey.
One method to circumvent the issue is to make use of an array during which the weather are positioned at only some of the positions they usually occupy. If we design such a “sparse” array rigorously, so that every mutual geometrical distance is exclusive, we are able to make it behave in addition to the nonsparse, full-size array. As an illustration, if we start with a 1.2-meter-aperture radar working on the Okay band and put in an appropriately designed sparse array having simply 12 transmitting and 16 receiving components, it could behave like an ordinary array having 192 components. The reason being {that a} rigorously designed sparse array can have as much as 12 × 16, or 192, pairwise distances between every transmitter and receiver. Utilizing 12 totally different sign transmissions, the 16 obtain antennas will obtain 192 indicators. Due to the distinctive pairwise distance between every transmit/obtain pair, the ensuing 192 acquired indicators may be made to behave as in the event that they had been acquired by a 192-element, nonsparse array. Thus, a sparse array permits one to commerce off time for house—that’s, sign transmissions with antenna components.
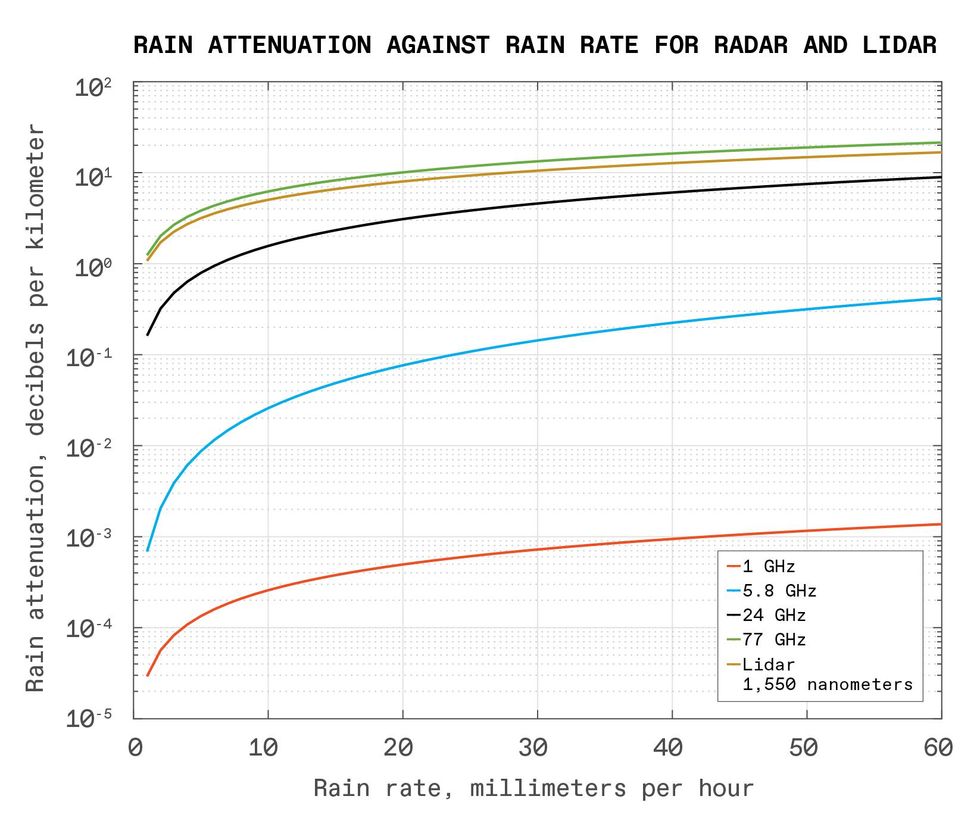
Seeing within the rain is usually a lot simpler for radar than for light-based sensors, notably lidar. At comparatively low frequencies, a radar sign’s lack of power is orders of magnitude decrease.Neural Propulsion Techniques
In precept, separate radar items positioned alongside an imaginary array on a automobile ought to function as a single phased-array unit of bigger aperture. Nevertheless, this scheme would require the joint transmission of each transmit antenna of the separate subarrays, in addition to the joint processing of the info collected by each antenna component of the mixed subarrays, which in flip would require that the phases of all subarray items be completely synchronized.
None of that is straightforward. However even when it might be applied, the efficiency of such a superbly synchronized distributed radar would nonetheless fall nicely wanting that of a rigorously designed, absolutely built-in, wide-aperture sparse array.
Take into account two radar programs at 77 GHz, every with an aperture size of 1.2 meters and with 12 transmit and 16 obtain components. The primary is a rigorously designed sparse array; the second locations two 14-element normal arrays on the acute sides of the aperture. Each programs have the identical aperture and the identical variety of antenna components. However whereas the built-in sparse design performs equally nicely irrespective of the place it scans, the divided model has bother wanting straight forward, from the entrance of the array. That’s as a result of the 2 clumps of antennas are broadly separated, producing a blind spot within the heart.
Within the broadly separated state of affairs, we assume two instances. Within the first, the 2 normal radar arrays at both finish of a divided system are one way or the other completely synchronized. This association fails to detect objects 45 % of the time. Within the second case, we assume that every array operates independently and that the objects they’ve every independently detected are then fused. This association fails virtually 60 % of the time. In distinction, the rigorously designed sparse array has solely a negligible likelihood of failure.
Seeing across the nook may be depicted simply in simulations. We thought-about an autonomous automobile, geared up with our system, approaching an city intersection with 4 high-rise concrete buildings, one at every nook. At the start of the simulation the automobile is 35 meters from the middle of the intersection and a second automobile is approaching the middle by way of a crossing street. The approaching automobile just isn’t inside the autonomous automobile’s line of sight and so can’t be detected with no technique of seeing across the nook.
At every of the three frequency bands, the radar system can estimate the vary and bearing of the targets which might be inside the line of sight. In that case, the vary of the goal is the same as the velocity of sunshine multiplied by half the time it takes the transmitted electromagnetic wave to return to the radar. The bearing of a goal is set from the incident angle of the wavefronts acquired on the radar. However when the targets will not be inside the line of sight and the indicators return alongside a number of routes, these strategies can’t straight measure both the vary or the place of the goal.
We are able to, nonetheless,
infer the vary and place of targets. First we have to distinguish between line-of-sight, multipath, and through-the-building returns. For a given vary, multipath returns are sometimes weaker (as a result of a number of reflections) and have totally different polarization. Via-the-building returns are additionally weaker. If we all know the essential atmosphere—the place of buildings and different stationary objects—we are able to assemble a framework to search out the doable positions of the true goal. We then use that framework to estimate how seemingly it’s that the goal is at this or that place.
Because the autonomous automobile and the varied targets transfer and as extra information is collected by the radar, every new piece of proof is used to replace the chances. That is Bayesian logic, acquainted from its use in medical analysis. Does the affected person have a fever? If that’s the case, is there a rash? Right here, every time the automobile’s system updates the estimate, it narrows the vary of potentialities till ultimately the true goal positions are revealed and the “ghost targets” vanish. The efficiency of the system may be considerably enhanced by fusing info obtained from a number of bands.
We have now used experiments and numerical simulations to judge the theoretical efficiency limits of our radar system beneath varied working circumstances. Highway assessments verify that the radar can detect indicators coming by means of occlusions. Within the coming months we plan to reveal round-the-corner sensing.
The efficiency of our system by way of vary, angular decision, and talent to see round a nook needs to be unprecedented. We count on it should allow a type of driving safer than we’ve got ever identified.
From Your Web site Articles
Associated Articles Across the Internet
[ad_2]

