


[ad_1]
|
Take heed to this text  |
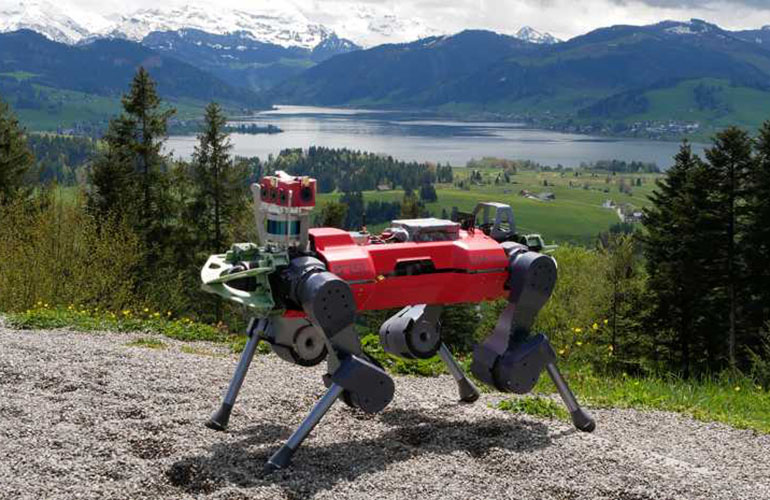
ANYmal, ETH Zurich’s quadruped robotic, on Mount Etzel. | Supply: ETH Zurich
Mount Etzel, in Switzerland, is ripe with challenges for a legged robotic. Between slippery floor, excessive steps and trails stuffed with roots, the three,602 ft mountain is the proper testing floor for ANYmal. ANYmal is a quadraped created by the Robotic Programs Lab at ETH Zurich.
Troublesome terrains are significantly difficult for robots. They battle to mix the visible notion of their setting with the proprioception of their legs. For people, it is a activity that we don’t even have to consider, however robots can solely do that in restricted methods.
The data that robots collect about their setting with sensors can usually be incomplete or ambiguous. The robotic would possibly see tall grass, a shallow puddle or snow and decide that it’s an insurmountable impediment. Alternatively, the robotic may not decide up on these obstacles in any respect if the sensors are obscured by climate situations or poor lighting.
“That’s why robots like ANYmal have to have the ability to determine for themselves when to belief the visible notion of their setting and transfer ahead briskly, and when it’s higher to proceed cautiously and with small steps,” Takahiro Miki, a doctoral scholar and lead creator on the examine, mentioned. “And that’s the massive problem.”
New management know-how
To assist ANYmal navigate environments shortly, the crew used a brand new management know-how, developed by ETH spin-off ANYbotics, based mostly on a neural community. Because of this controller, ANYmal discovered tips on how to mix its visible notion with its proprioception. The crew examined ANYmal’s means in a digital coaching camp earlier than bringing it out into the world.
On Mount Etzel, ANYmal scaled nearly 400 ft (120 m) in simply 31 minutes. “With this coaching, the robotic is ready to grasp essentially the most troublesome pure terrain with out having seen it earlier than,” ETH Zurich Professor Marco Hutter mentioned.
ANYmal discovered tips on how to overcome quite a few obstacles, in addition to when to rely extra on its proprioception as a substitute of visible notion. This manner ANYmal can inform when poor lighting or climate is distorting its notion, and navigate with its sense of contact as a substitute.
[ad_2]

