



[ad_1]
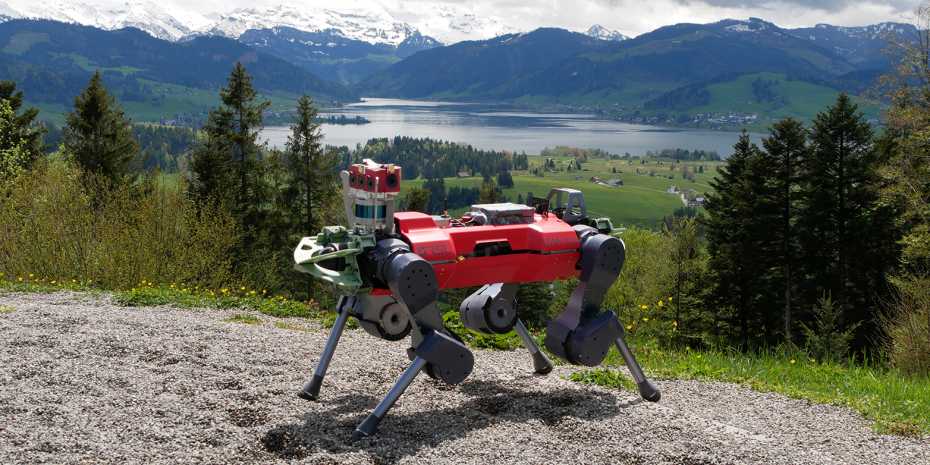
The legged robotic ANYmal on the rocky path to the summit of Mount Etzel, which stands 1,098 metres above sea stage. (Picture: Takahiro Miki)
By Christoph Elhardt
Steep sections on slippery floor, excessive steps, scree and forest trails stuffed with roots: the trail up the 1,098-metre-high Mount Etzel on the southern finish of Lake Zurich is peppered with quite a few obstacles. However ANYmal, the quadrupedal robotic from the Robotic Programs Lab at ETH Zurich, overcomes the 120 vertical metres effortlessly in a 31-minute hike. That’s 4 minutes quicker than the estimated period for human hikers – and with no falls or missteps.
That is made doable by a brand new management know-how, which researchers at ETH Zurich led by robotics professor Marco Hutter not too long ago introduced within the journal Science Robotics. “The robotic has discovered to mix visible notion of its setting with proprioception – its sense of contact – based mostly on direct leg contact. This enables it to deal with tough terrain quicker, extra effectively and, above all, extra robustly,” Hutter says. Sooner or later, ANYmal can be utilized anyplace that’s too harmful for people or too impassable for different robots.
Video: Nicole Davidson / ETH Zurich
Perceiving the setting precisely
To navigate troublesome terrain, people and animals fairly routinely mix the visible notion of their setting with the proprioception of their legs and fingers. This enables them to simply deal with slippery or delicate floor and transfer round with confidence, even when visibility is low. Till now, legged robots have been ready to do that solely to a restricted extent.
“The reason being that the details about the fast setting recorded by laser sensors and cameras is usually incomplete and ambiguous,” explains Takahiro Miki, a doctoral pupil in Hutter’s group and lead writer of the examine. For instance, tall grass, shallow puddles or snow seem as insurmountable obstacles or are partially invisible, though the robotic may truly traverse them. As well as, the robotic’s view may be obscured within the subject by troublesome lighting circumstances, mud or fog.
“That’s why robots like ANYmal have to have the ability to determine for themselves when to belief the visible notion of their setting and transfer ahead briskly, and when it’s higher to proceed cautiously and with small steps,” Miki says. “And that’s the massive problem.”
A digital coaching camp
Due to a brand new controller based mostly on a neural community, the legged robotic ANYmal, which was developed by ETH Zurich researchers and commercialized by the ETH spin-off ANYbotics, is now in a position to mix exterior and proprioceptive notion for the primary time. Earlier than the robotic may put its capabilities to the take a look at in the actual world, the scientists uncovered the system to quite a few obstacles and sources of error in a digital coaching camp. This let the community study the perfect method for the robotic to beat obstacles, in addition to when it could possibly depend on environmental information – and when it could do higher to disregard that information.
“With this coaching, the robotic is ready to grasp probably the most troublesome pure terrain with out having seen it earlier than,” says ETH Zurich Professor Hutter. This works even when the sensor information on the fast setting is ambiguous or obscure. ANYmal then performs it secure and depends on its proprioception. Based on Hutter, this enables the robotic to mix the most effective of each worlds: the velocity and effectivity of exterior sensing and the protection of proprioceptive sensing.
Use underneath excessive circumstances
Whether or not after an earthquake, after a nuclear catastrophe, or throughout a forest hearth, robots like ANYmal can be utilized primarily wherever it’s too harmful for people and the place different robots can not address the troublesome terrain.
In September of final yr, ANYmal was in a position to display simply how properly the brand new management know-how works on the DARPA Subterranean Problem, the world’s best-recognized robotics competitors. The ETH Zurich robotic routinely and rapidly overcame quite a few obstacles and troublesome terrain whereas autonomously exploring an underground system of slim tunnels, caves, and concrete infrastructure. This was a significant a part of why the ETH Zurich researchers, as a part of the CERBERUS group, took first place with a prize of two million {dollars}.
tags: c-Analysis-Innovation
ETH Zurich
is among the main worldwide universities for know-how and the pure sciences.
ETH Zurich
is among the main worldwide universities for know-how and the pure sciences.
[ad_2]

