


[ad_1]
|
Hearken to this text  |
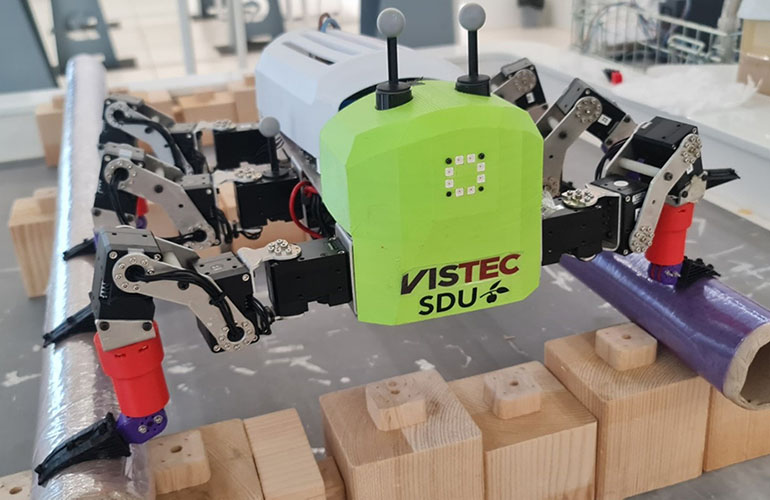
A hexapod robotic with fin-ray impressed grippers which have altered crossbeams.
Many tender robotic grippers are impressed by the way in which a fish’s fin bends. They contain triangular parts that bend inward, round an object to grip it. These parts have transverse beams that sit at a 90° angle, which assist the gripper to bend round an object.
These conventional grippers require quite a lot of power to select up an object, and aren’t at all times able to dealing with delicate objects with out crushing them. Researchers from 5 completely different universities, led by Poramante Manoonpong from Syddansk College in Odense, are taking their inspiration from the way in which bugs stroll and grip issues to develop a unique solution to make robotic grippers.
As an alternative of transverse beams sitting at a 90° angle, the worldwide analysis workforce in Odense put the beams at 10° or 30° angles, just like insect attachment pads. By altering the angle of those beams, researchers discovered that their grippers had been capable of bend extra round objects and choose them up utilizing 20% much less power.
“We all know that many animals are capable of [grip or attach themselves] to surfaces utilizing compliant pads or ft,” stated Manoonpong. “We might see that the angle of bugs’ attachment pads was completely different. Earlier work has already investigated altering the angle of the gripper, however none have performed detailed investigation on the impact of various crossbeam angles inside its body.”
Utilizing much less power to select up an object permits the gripper to deal with extra delicate gadgets, like meals gadgets, with out crushing them. When the researchers examined grippers with beams at 90° or 120°, it took far more power for the gripper to select up an merchandise.
The brand new grippers additionally improved the way in which that robots stroll. When confronted with uneven surfaces, like rocks, or spherical ones, like tubes to stroll throughout, the robots had been capable of navigate the state of affairs with out advanced management. The grippers resemble flippers, which might bend simply across the floor the robotic walks throughout.
Impressed by nature
Manoonpong’s workforce of researchers had been impressed by insect attachment pads, however they’re not the one researchers seeking to nature to make developments in robotics.
In December 2020, researchers on the College of Georgia School of Engineering developed a robotic gripper impressed by beanpoles. These tender grippers require just one pneumatic management, which simplified the operation. The gripper additionally had a fiber optic sensor within the robotic’s elastic backbone that may sense the merchandise it’s selecting up and any exterior disturbances.
In November 2020, researchers at UNSW Sydney created a gripper impressed by an elephant’s trunk. This tender material gripper was designed to deal with heavy objects in addition to fragile ones.
The Odense workforce examined their gripper mannequin utilizing solely tender grippers. Their subsequent problem is to make one sturdy sufficient to deal with harsher environments.
The Odense workforce’s whole analysis might be discovered right here.
[ad_2]

