


[ad_1]
|
Hearken to this text  |
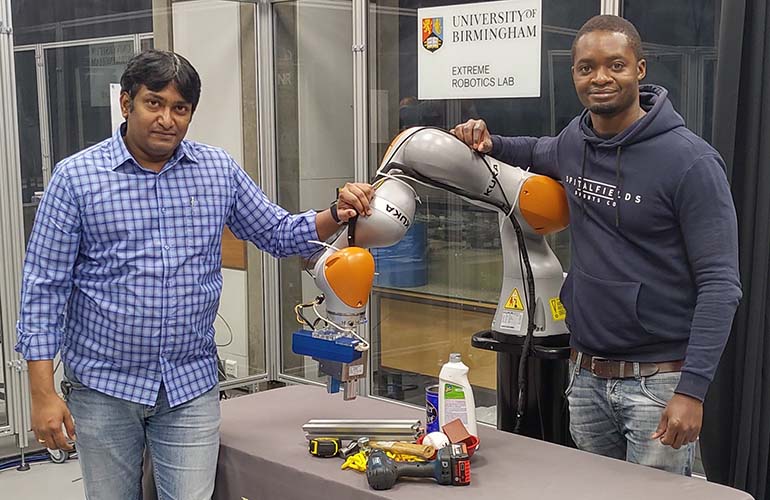
Dr Naresh Marturi, senior analysis scientist in robotics (left) and Maxime Adjigble, robotics analysis engineer (proper) had been a part of a workforce that developed a system to raised deal with nuclear waste.
There’s over 85,000 metric tons of spent nuclear gasoline from business nuclear energy crops, and 90 million gallons of waste from authorities weapons applications within the U.S. at the moment, in response to the Authorities Accountability Workplace.
That quantity is quickly rising. Yearly, we add 2,000 metric tons of spent nuclear gasoline. Disposing and dealing with nuclear waste is a harmful process that requires precision and accuracy. Researchers from the Nationwide Centre for Nuclear Robotics led by the Excessive Robotics Lab on the College of Birmingham within the UK are discovering methods to assist people and robots work collectively to get the job accomplished.
The researchers have developed a system utilizing a typical industrial robotic that makes use of a parallel jaw gripper to deal with objects and an Ensenso N35 3D cameras to see the world round it. The workforce’s system entails permitting people to make extra advanced choices that AI isn’t geared up to do, whereas the robotic determines learn how to greatest carry out the duties. The workforce makes use of three sorts of shared management.
The primary is semi-autonomy, the place a human makes excessive stage choices, whereas the robotic plans and executes them. The second is variable autonomy, the place a human can determine to modify between autonomous actions and direct joystick managed actions. The third is shared management, the place the human tele-operates some elements of a process, like shifting the robotic arm in the direction of an object, whereas the AI decides learn how to orient the gripper to greatest choose up that object.
The robotic is supplied with Ensenso’s 3D digital camera, which provides it spacial imaginative and prescient, just like human imaginative and prescient. Ensenso’s cameras work by having two cameras view objects from barely totally different positions. They seize photographs which are related in content material however present variations within the place of objects.
Ensenso’s software program combines these two photographs to create a degree cloud mannequin of the article. This technique of viewing the world helps the robotic to be extra exact in its actions.
“The scene cloud is utilized by our system to robotically generate a number of steady gripping positions. For the reason that level clouds captured by the 3D digital camera are high-resolution and dense, it’s potential to generate very exact gripping positions for every object within the scene,” stated Dr. Naresh Marturi, senior analysis scientist on the Nationwide Centre for Nuclear Robotics. “Based mostly on this, our ‘speculation rating algorithm’ determines the following object to select up, based mostly on the robotic’s present place.”
Researchers on the lab are presently growing an extension of the system that might be appropriate with a multi-fingered hand as an alternative of a jaw gripper. They’re additionally engaged on full autonomous gripping strategies, the place the robotic is managed by an AI.
[ad_2]

