


[ad_1]
|
Take heed to this text  |
By Pradeep Deshmane (principal engineer) and Manoj Pujari (lead engineer) at Portescap
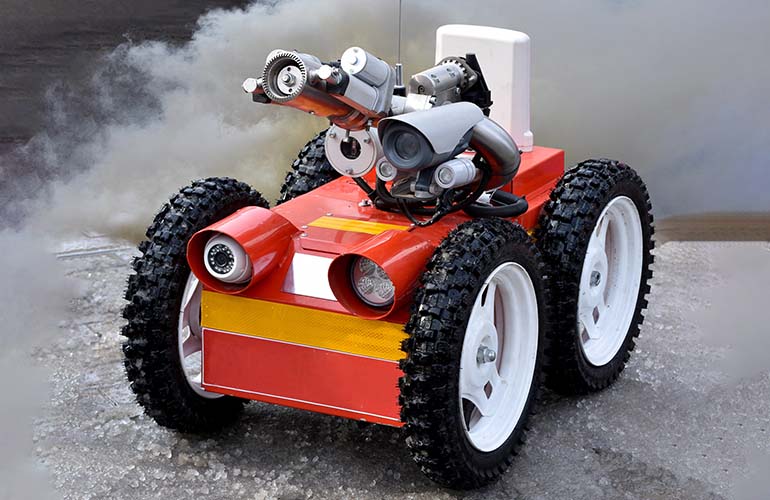
Whether or not transferring or positioning objects, accessing harmful environments, dealing with hazardous supplies like medical waste or just serving to out round the home, there’s a super demand for autonomous cell robots. Not solely do they carry out duties which are tough, repetitive or inconvenient for human labor, they carry them out appropriately and are particularly efficient the place precision is required. This text supplies an summary of autonomous cell robots, describing their operation, market want and demand, utility necessities, choice standards, design optimization and future developments.
Autonomous Cellular Robotic Operation and Common Purposes
Autonomous cell robots navigate on the bottom utilizing motorized wheels to propel themselves. Not like robots that use treads or legs, autonomous cell robots are simpler to design, construct and program for motion in flat, not-so-rugged terrain. They’re notably standard within the shopper market as a result of their differential steering is cheap and easy to implement. Robots can have any variety of wheels, however three wheels are adequate for static and dynamic steadiness. Further wheels can add steadiness; nevertheless, extra mechanisms might be required to maintain all of the wheels on the bottom — particularly when the terrain shouldn’t be flat. The movement system consists of motors coupled with gearboxes driving the wheels, which will increase the torque capability for higher drivability.
Along with their widespread use within the shopper market, autonomous cell robots will be present in hospitals performing an infection management, medical companies, medical waste supply, biochemical specimen supply and normal medical duties. They’re additionally being deployed within the worldwide struggle towards the COVID-19 pandemic. One other rising market is within the aerospace and protection (A&D) business the place robots play a vital position in surveillance and army operations. Within the oil and fuel (O&G) business, they’re anticipated to be invaluable instruments in pipeline inspections due to their means to {photograph} the inside of the buildings to assist determine cracks or faults.
Software Necessities
In most functions, the movement programs usually should fulfill the next necessities:
- Compact measurement and light-weight
- Excessive torque
- Sturdiness and lengthy life
- Low noise, particularly when utilized in medical and A&D gear
- Excessive effectivity and low present.
Movement programs in autonomous cell robots normally encompass brushed or brushless DC motors coupled with compact planetary gearboxes. This requirement could differ barely from utility to utility, however the movement programs usually have the next specs:
- Motor: coreless brushed DC or brushless DC motor
- Gearbox configuration: planetary; ⅔ stage, 30:1 to 120:1 ratio
- Packaging measurement: <40 mm2
- Gearbox output torque: 4 to eight Nm
- Gearbox output velocity: 50 to 150 rpm

Determine 1. Two widespread axis configurations for autonomous cell robots.
Choice Standards
Step one in choosing a motor and gearbox is to find out each the product’s working and most situations. Subsequently, you will want to verify the required velocity and torque skilled on the wheel output.
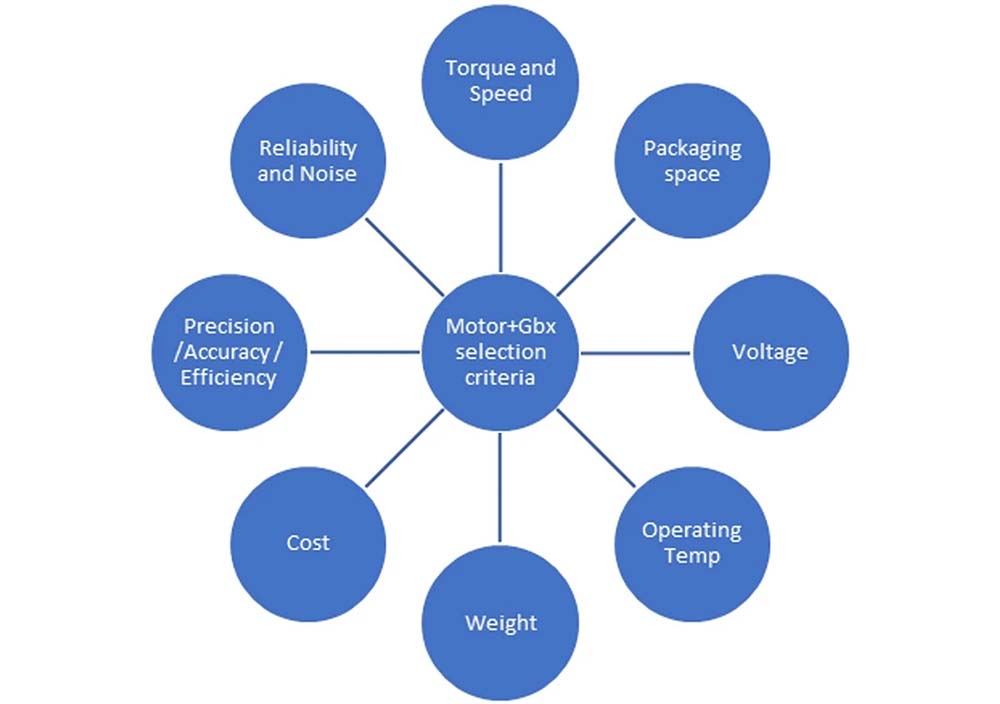
Determine 2. Necessary elements to think about when choosing a motor and gearbox for an autonomous cell robotic design.
Torque. First, decide the output torque required after which work backwards to search out your motor and gearing. The torque on the wheel must be based mostly on robotic acceleration, wheel diameter and carrying capability. Be certain the carrying capability accounts for pulling all the robotic in case some actuators fail or wheels slip, in addition to the minimal slope and potential obstacles to beat. Friction and effectivity additionally ought to issue into the ultimate torque calculation.
Pace. So as to calculate the velocity at which the wheel must rotate, you have to outline your required velocity — or remaining output — for the wheel. Primarily based on that data, you may select the motors and gearing. The robotic producer usually finalizes the robotic’s drive velocity, and the wheel diameter determines the required velocity on the wheel output.
Packaging area. Be certain that the motor stack, which consists of the encoder, brake, motor and gearing, suits into the robotic and will be packaged cleanly. The encoder means that you can measure how a lot the motor shaft turns, and the brake system helps to carry the torque and supply dynamic stopping in case of an emergency.
Voltage. The working voltage is used to energy the motor. Usually, the upper the voltage, the upper the velocity functionality of the motor. The motor’s datasheet will present the voltage fixed — also referred to as again EMF fixed — so you may calculate how briskly the motor will rotate per volt.
Working temperature. Though temperature usually shouldn’t be a problem, it’s nonetheless essential to verify your motor stack doesn’t overheat — notably whether it is enclosed. The gearbox is one other space of concern since temperature can have an effect on its lubrication life and efficiency over time.
Weight. The mass of the load additionally determines the torque for motor choice. Subsequently, you will want to estimate the mass, or know the precise mass, to decide on a motor. If you happen to base your design on a mass estimate, we suggest making use of a 25 % security margin. Discuss with the torque fixed offered on the motor datasheet to calculate how a lot torque output you’ll obtain per amp.
Price. Whereas constructing a gearbox from scratch could also be inexpensive, the effort and time required to design, assemble and check the brand new gear could make an ordinary gearbox the extra economical choice.
Precision, accuracy and effectivity. How a lot lag are you able to afford in your gearing? Usually, wheel motor robotic functions can enable rather less precision and accuracy relying on the terrains and torque profiles concerned. And, since not all functions demand excessive efficiency traits like low noise or vibration, decrease precision will be tolerated. Nonetheless, robotic arms or devices usually want low backlash programs which are extra exact and correct.
Reliability and noise. Most functions require increased reliability, so the motor stack should survive the required working factors. Some vital functions like surveillance robots demand each low noise and better reliability, and the motor and gearbox need to fulfill each standards.
Select an Optimum Design
Right here’s an instance of an autonomous cell robotic utility utilizing a movement system designed by Portescap:
- Motor: brushed DC 35 GLT
- Principal gearbox: planetary gearbox, 3 stage, spur, 99.8 complete gearbox ratio
Many autonomous cell robots make use of differential steering, which depends on individually pushed wheels for motion. One other design, a four-wheel drive robotic with two pairs of powered wheels, provides extra steadiness since every pair can flip in the identical path. Nonetheless, if the pairs don’t run on the similar velocity, the robotic will transfer slowly and can’t drive in a straight line. An optimum design has a differential steering mechanism just like these utilized in a automobile, which permits the robotic to show left or proper, requiring just one motor. One other widespread configuration of robots makes use of motors that drive wheels independently as an alternative of differential steering. On this case, separate motors are required to drive every wheel. The general system specs are:
- Packaging: 32 -mm2 x 115 mm size
- Gearbox output torque capability: 8 Nm
- Gearbox output velocity: 80 rpm
- Life expectancy: 1,000 hours
- Most temperature: 125°C
The Portescap product, proven in Determine 3, provides a smaller bundle, increased torque carrying capability and better sturdiness, making them well-suited for a variety of autonomous robotic functions.

Determine 3. Portescap brushed DC 35 GLT motor with gearbox.
Future Developments in Autonomous Cellular Robots
Autonomous cell robots usually are not with out drawbacks. For instance, they don’t navigate effectively over rocky terrain, sharp declines or areas with low friction. To ensure that robots to beat these limitations, driving architectures have to be modified to incorporate mechanisms like a differential drive system with tracks, a skid steer four-wheel drive system or two wheels plus passive casters differential drive system. Nonetheless, these architectures add extra complexity and require detailed research about their price impacts.
And not using a main change within the total structure, robotic designers should focus their efforts on optimizing the movement system. The next developments might help enhance autonomous cell robotic efficiency with respect to sturdiness, effectivity and noise discount:

Determine 4. Needle curler bearing.
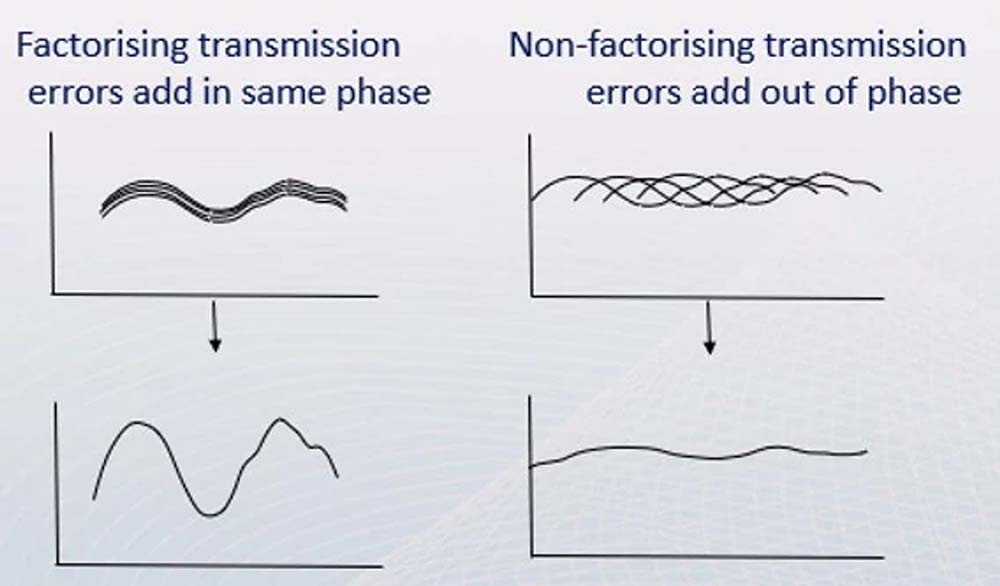
Determine 5. Transition error evaluation for low-noise gearbox.
Superior elements. Needle curler bearings, such because the bearing proven in Determine 4, keep away from scuffing failures and guarantee easy rotation of planet gears on planet pins. As well as, sure gearboxes function gear tooth organized to decrease torsional forces for diminished noise.
Superior FEA-based analyses. A structural evaluation helps to determine potential failures and get rid of them early within the design course of. An instance is proven in Determine 6.

Determine 6. Superior FEA evaluation.
Superior acoustic simulation. Utilizing software program to foretell noise, such because the simulation in Determine 7, helps optimize the design for vital functions requiring low noise.

Determine 7. Superior acoustic simulation.
Get Rolling With the Proper Motor Provider
As robots change into an integral a part of our lives in each business and in our properties, autonomous cell robots might be on the forefront of the development. So as to obtain precision and optimum efficiency on your autonomous cell robotic utility, you’ll want the fitting movement elements. Portescap provides a broad vary of ordinary and customized miniature motors with excessive torque density, reliability and effectivity together with engineering assist to make sure your autonomous cell robotic programs can go the place they’re wanted and get the job completed.
For extra data, go to our web site.
[ad_2]

