



[ad_1]
Credit: Marco Pavone
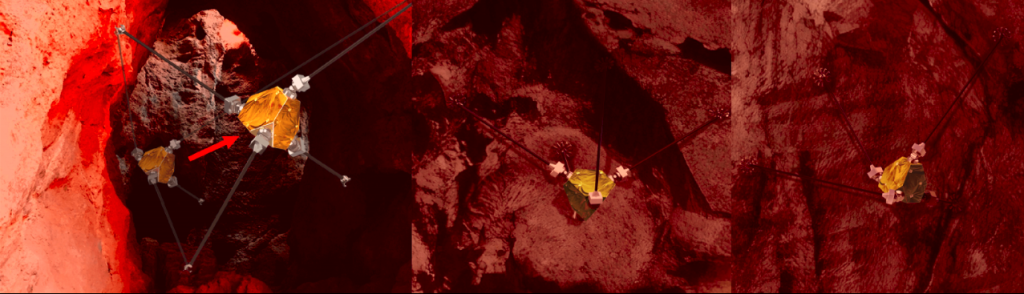
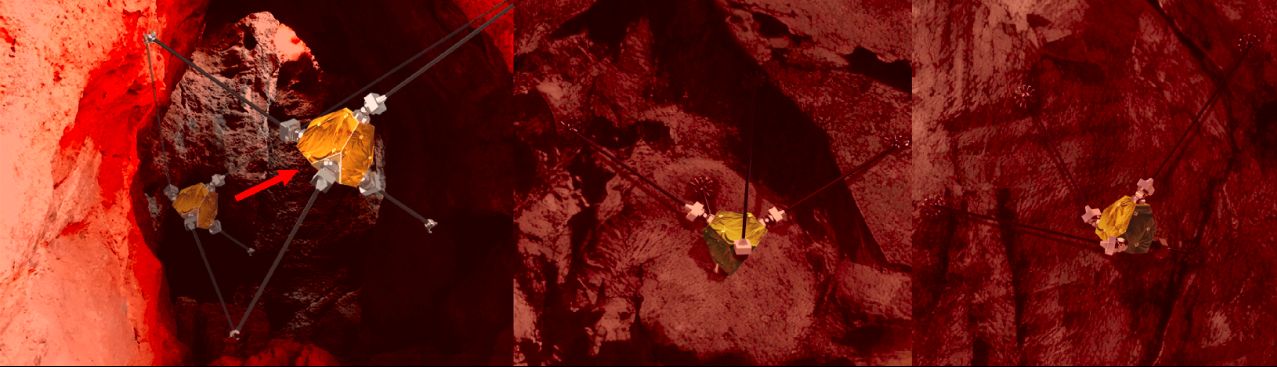
Lilly interviews Stephanie Schneider, a PhD candidate at Stanford engaged on unconventional house robotics. Schneider explains her work on Reachbot, a long-reach crawling and anchoring robotic, which repurposes extendable booms for cellular manipulation. They focus on the challenges and thrilling parts of robotic prototyping for low-gravity or in any other case distinctive environments.
https://youtu.be/0RqFgOHqz7E
Stephanie Schneider
Stephanie Schneider is a Ph.D. candidate in Aeronautics and Astronautics within the Autonomous Programs Laboratory at Stanford, working with Professor Marco Pavone. She acquired her BS in Mechanical Engineering from Cornell College in 2014. Stephanie’s analysis pursuits embody real-time spacecraft motion-planning, greedy and manipulation in house, and adaptive management for autonomous robotics.
Hyperlinks
tags: Actuation, c-House, cx-House, Manipulation, NIAC, podcast, Prototype, Analysis, robotic, house, Stanford
Lilly Clark
[ad_2]

